Robotics Center Blog
Deep dives on physical AI, imitation learning, and robot hardware from the team building the RL² pipeline.
Best Data Gloves for Robot Teleoperation in 2026
Data and teleoperation gloves for robot learning in 2026: Wuji Glove, MANUS Metagloves Pro, UDEXREAL UDCAP, LinkerBot gloves and our RC G1 Tactile Glove, compared on sensing, rate and integration.
Best Dexterous Robot Hands in 2026: Buyer's Guide by Use Case and Budget
Which dexterous robot hand to buy in 2026, sorted by use case and budget: Wuji Hand 2, LinkerBot, AGIBOT OmniHand, BrainCo Revo 2, Inspire, Unitree, Allegro, PaXini, Sharpa and LEAP Hand, with live prices and stock.
The FCC Covered List and Buying Unitree or AGIBOT Robots in the US (2026)
What the FCC's July 28, 2026 Covered List action on foreign-produced robots actually says, with links to the FCC's own notices, and what it means for buying, owning and updating humanoids and quadrupeds in the US. Not legal advice.
Unitree Price List 2026 (US): G1, R1, H2, Go2 and B2 With Live Prices
How much does a Unitree robot cost in the US? Live store prices for every G1, R1, H2, Go2, As2, A2 and B2 configuration we sell, what base vs EDU means, and which models are in stock.
2026 Pricing Realignment: What Changed and Why
RCSV just realigned ~95 SKUs to current 2026 market conditions. Prices dropped on Booster K1, Unitree A2 Pro, G1 EDU, and AgileX grippers. Consumer compute moved up. Quotes-in-flight honored 14 days.
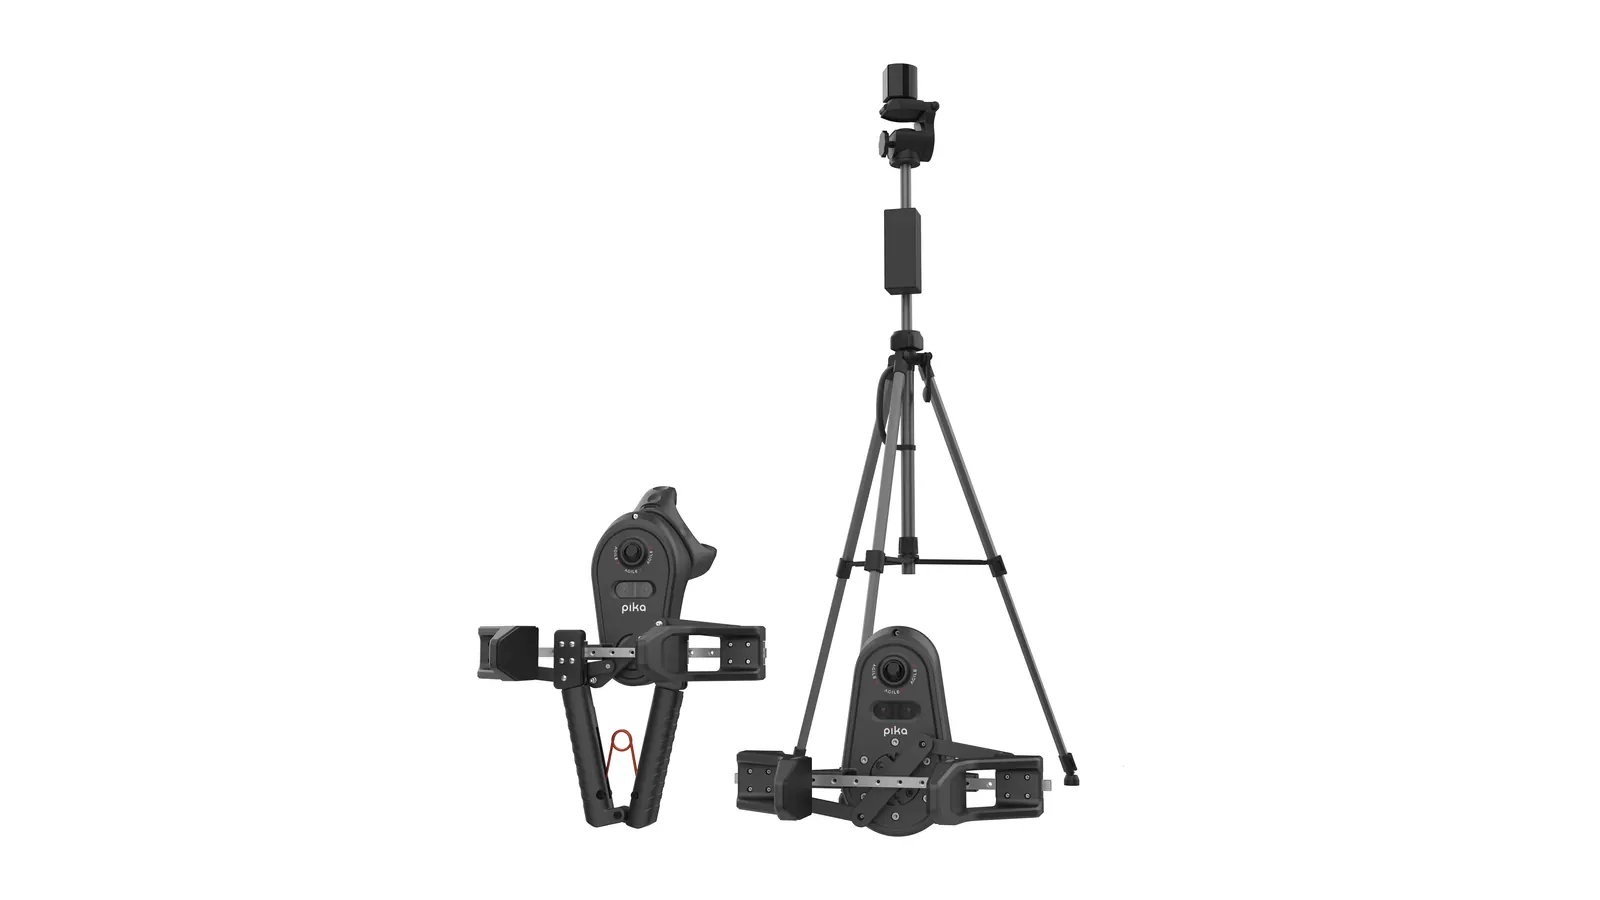
AgileX PiKA System: The Complete Data Collection Setup for Embodied AI (2026)
AgileX PiKA guide: full system breakdown of PiKA Sense-H, Gripper-H, Station-H, Ego-H, and OS-H for embodied AI data collection. Specs, pricing, and comparison vs UMI and DexCap.
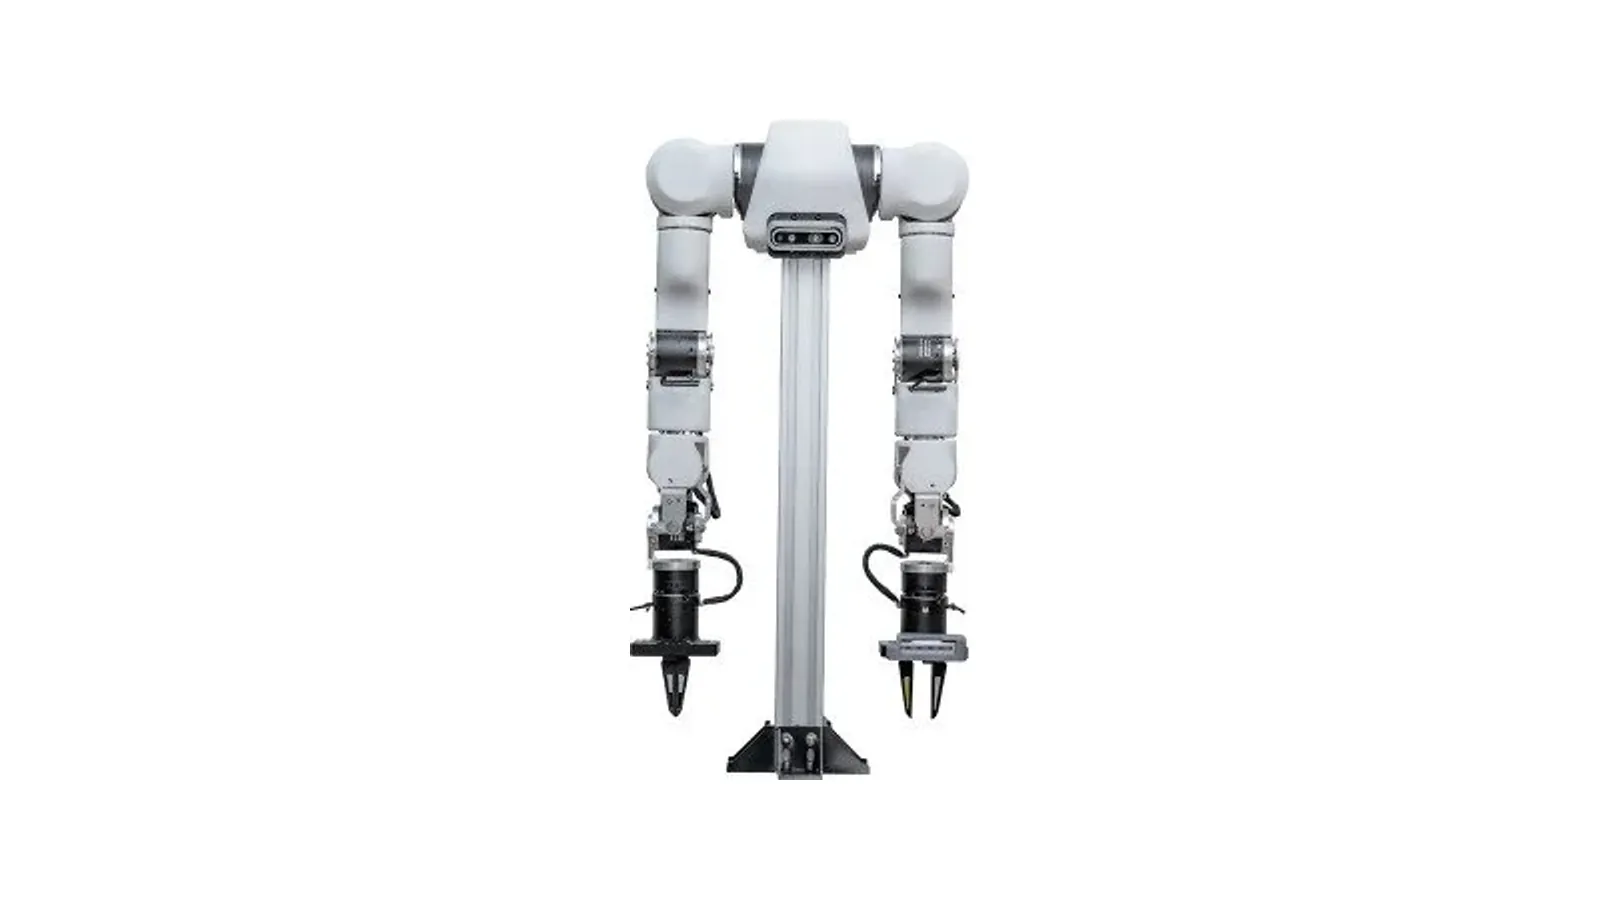
OpenArm 1: The Open-Source Robot Arm for Research (2026 Guide)
OpenArm 1 guide: the 6-DOF open-source robot arm designed for teleoperation and data collection. Specs, pricing at RCSV, ROS2 setup, and comparison vs SO-ARM100 and ViperX 300.
Robot End Effectors: Types, Specs & Where to Buy (2026 Guide)
Complete guide to robot end effectors: parallel grippers, dexterous hands, vacuum cups, and tactile sensors. Compare Robotiq 2F-85, Wuji Hand, and Allegro Hand. Specs, pricing, and how to choose for your application.
Robotiq 2F-85 Gripper: Specs, Price & Alternatives (2026)
Robotiq 2F-85 gripper guide: 85mm stroke, 2.5kg payload, 20-235N programmable force, available at RCSV. Full specs, 2F-85 vs 2F-140 comparison, compatible robot arms, and alternatives.
Lab Automation with Robots: Complete Guide for Research Labs (2026)
Lab automation robots for research labs: types (liquid handling, sample prep, inspection), cobot vs specialized systems, pricing, Universal Robots UR3e, AgileX PiPER, OpenArm, and RCSV's lab automation offering.
RoboMimic: Complete Guide to the Robot Imitation Learning Benchmark (2026)
RoboMimic explained: datasets, BC/offline-RL algorithms, and the standard eval protocol for robot manipulation — plus MimicGen for synthetic demos.
Wuji Hand & Wuji Glove: The Complete Teleoperation Guide (2026)
Complete guide to the Wuji Hand and Wuji Glove: specs, teleoperation setup, imitation learning data collection, current pricing, $500 glove shipping, and demos at RCSV.
Dreamer vs IRIS vs TD-MPC2: Choosing a World Model for Your Robot
Dreamer v3, IRIS, and TD-MPC2 compared head-to-head. Architecture differences, training costs, inference speed, integration with ROS2 and LeRobot, and decision framework for choosing the right world model for your robotics project.
Getting Started with World Models for Robot Learning: A Practical Guide
Step-by-step guide to training world models for robotics. Covers prerequisites, data preparation, Dreamer v3 training, evaluation, and deployment. Includes code examples, common mistakes, and FAQ.
World Models for Robotics: Why They Matter and How They Work
What are world models for robotics? Learn how learned dynamics models like Dreamer, IRIS, and TD-MPC2 enable sample-efficient robot learning through imagination-based planning, sim-to-real transfer, and safety validation.
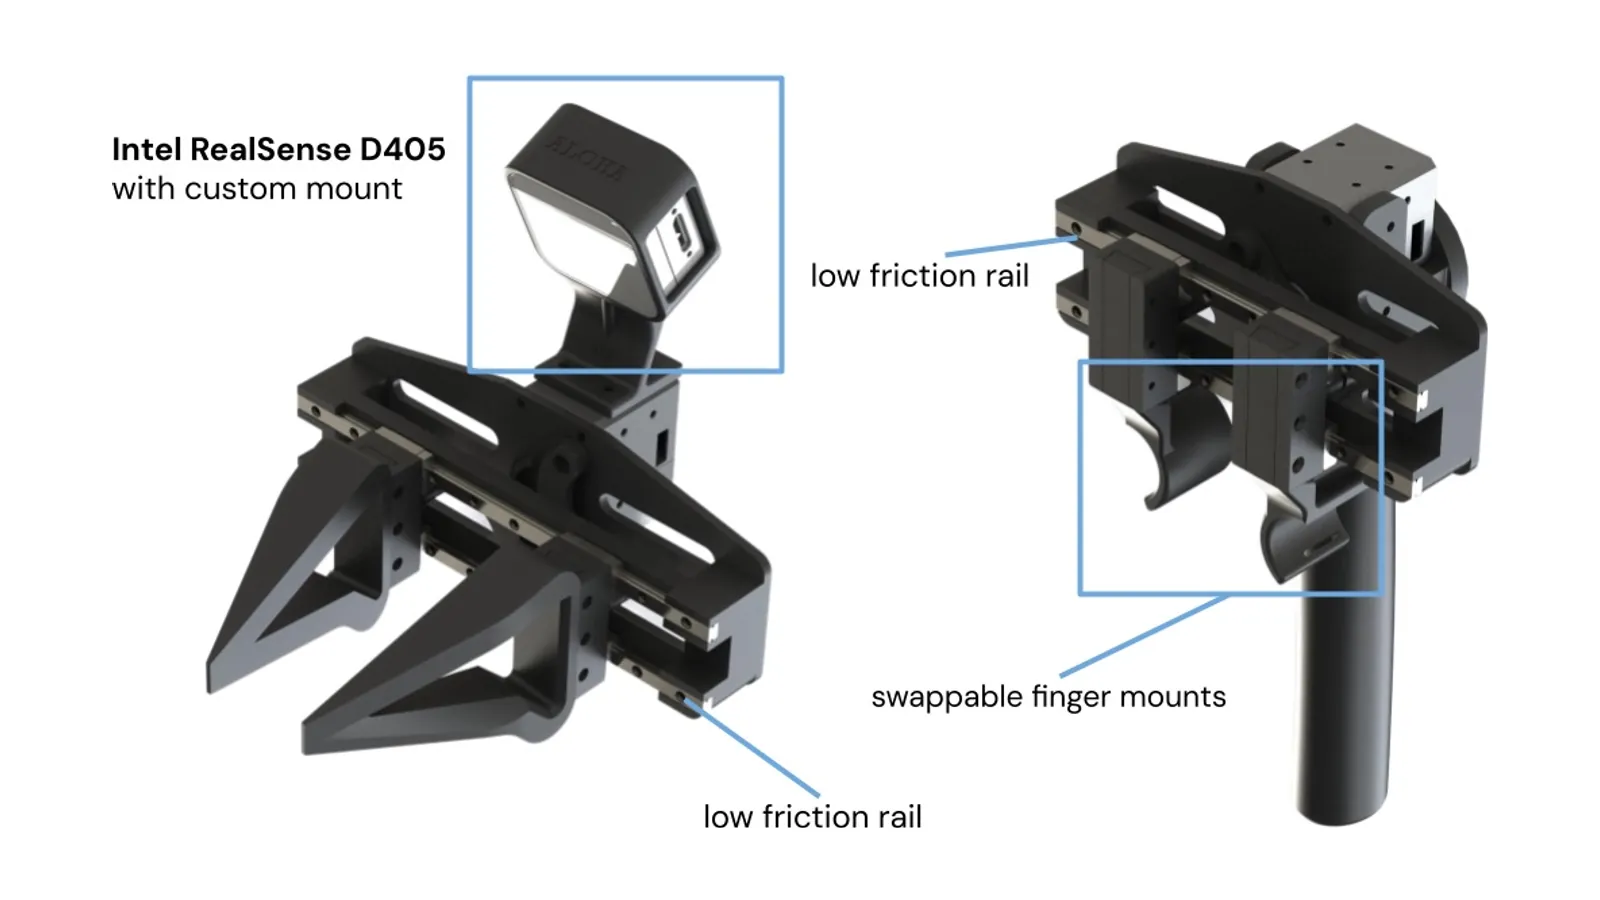
ALOHA vs UMI: Which Data Collection System Is Right for You?
In-depth comparison of ALOHA and UMI data collection systems for robot imitation learning. Covers cost, setup, data quality, portability, task types, and when to use each system.
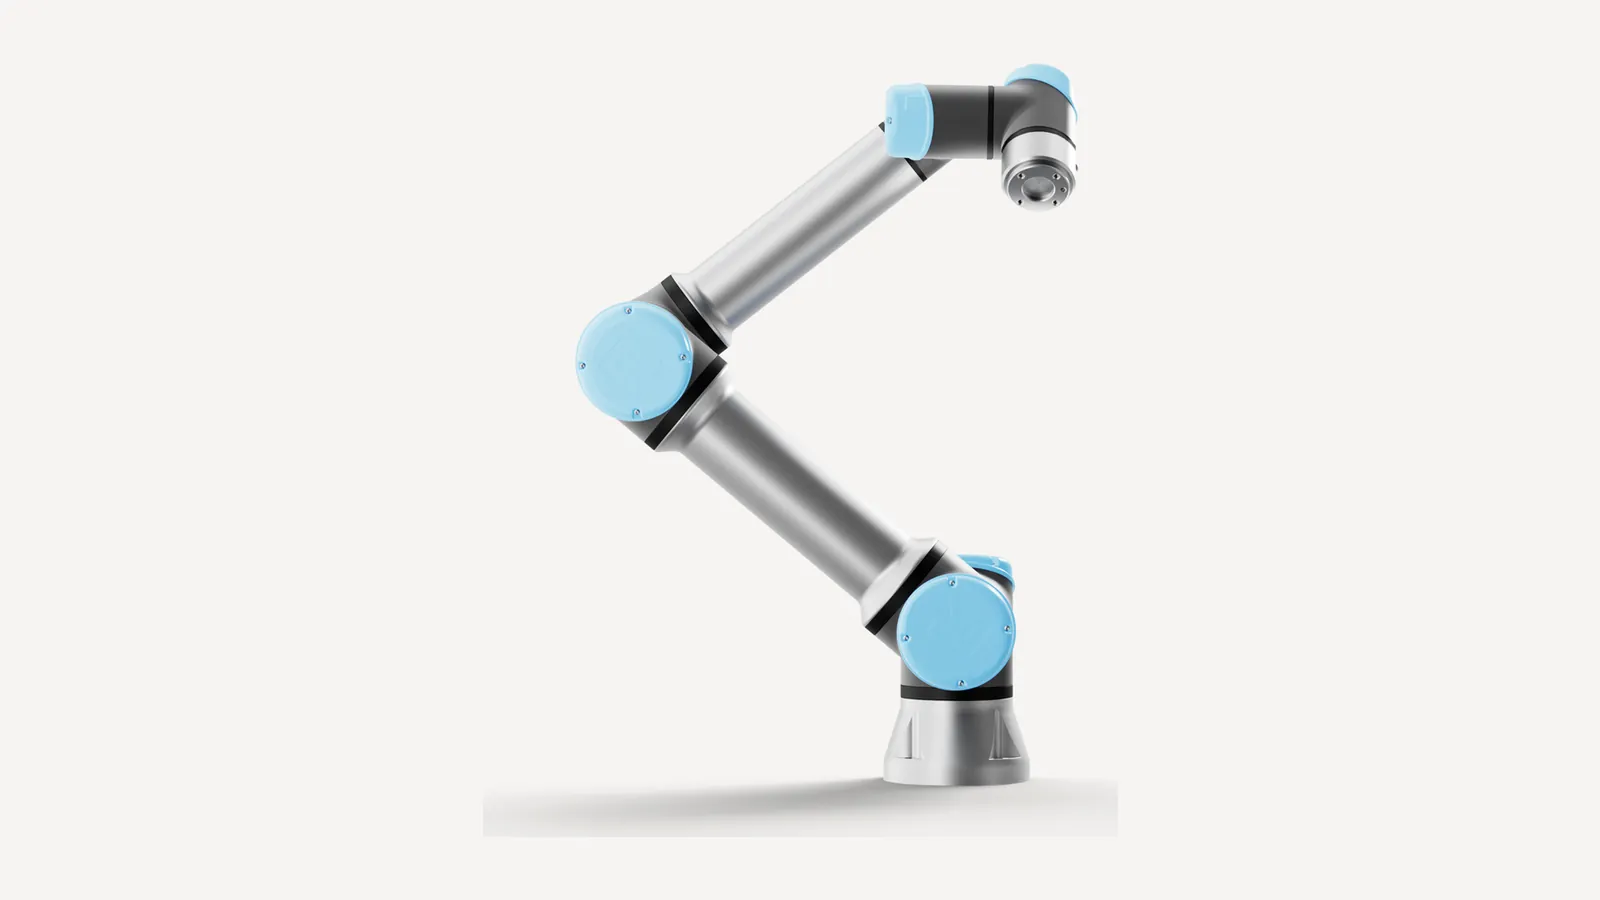
Best Collaborative Robots (Cobots) for Small Business 2026
Cobot buyers guide 2026: compare Universal Robots UR3e/UR5e/UR10e, Dobot CR5, UFACTORY xArm, AgileX Piper, and JAKA Zu cobots by payload, reach, price, and programming software. Current prices at RCSV.
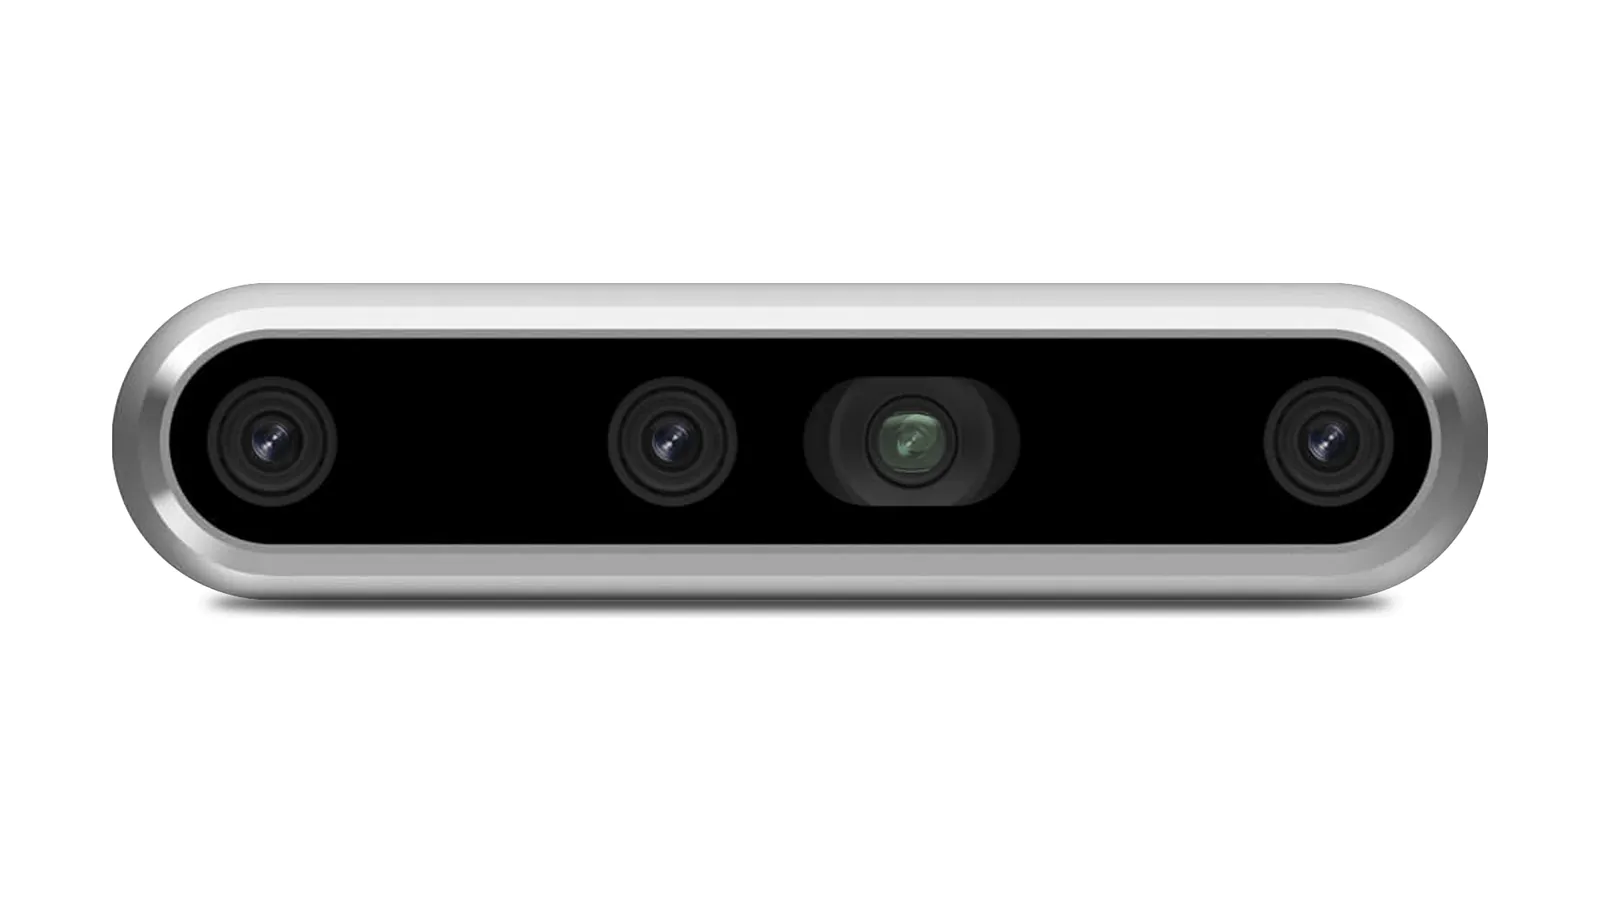
Best Depth Cameras for Robotics 2026: RealSense vs ZED vs Orbbec
RealSense, ZED and Orbbec depth cameras compared for robotics: range, accuracy, price and ROS 2 support.
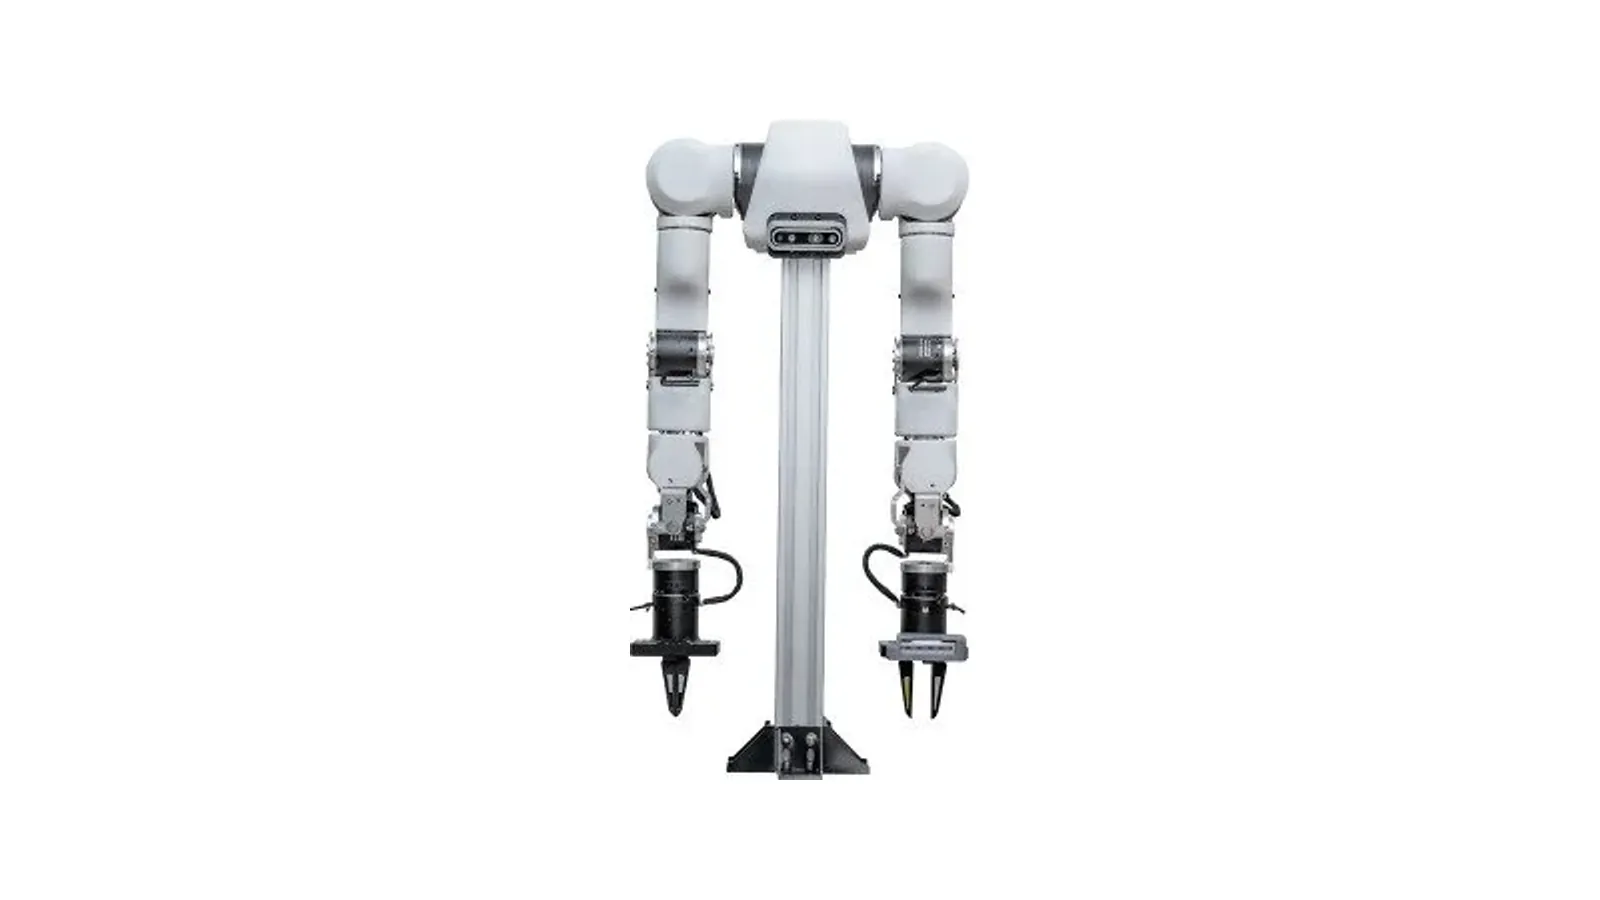
Best Robots for Imitation Learning & AI Training 2026
Guide to robots for imitation learning and AI training in 2026: OpenArm, Mobile ALOHA, UR5e, AgileX Piper, and SO-101 compared for data collection, ACT training, and policy deployment.
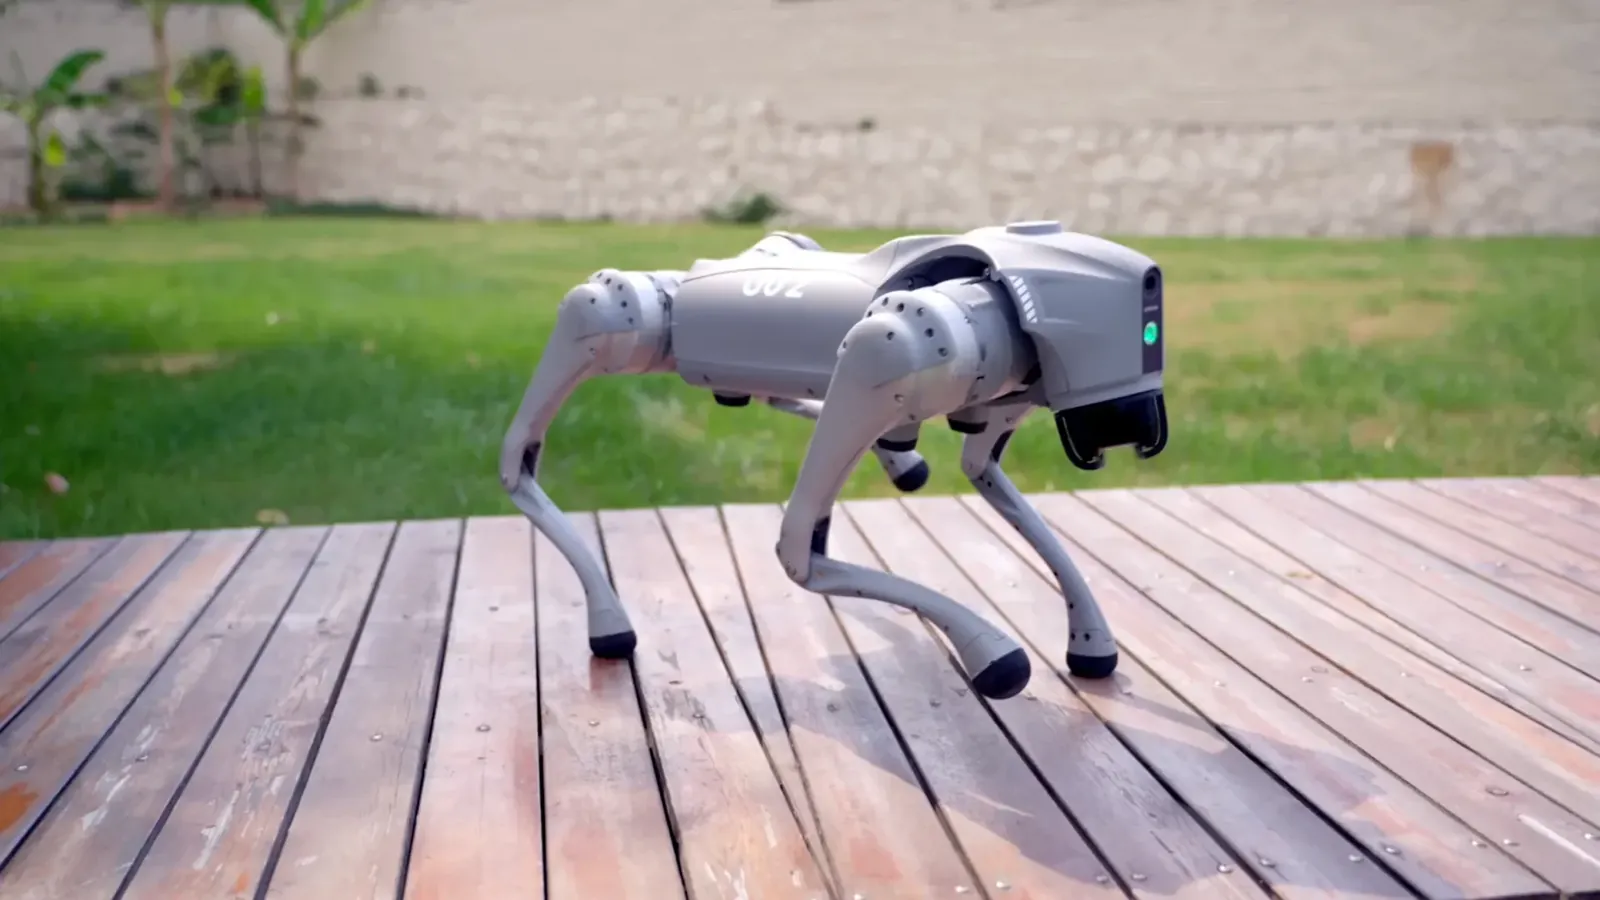
Robot Dog Price Guide 2026: How Much Every Model Costs
How much is a robot dog? Live US prices for every quadruped we sell, from education kits to industrial Unitree, AGIBOT and Deep Robotics models, plus Spot, and how to pick by budget and job.
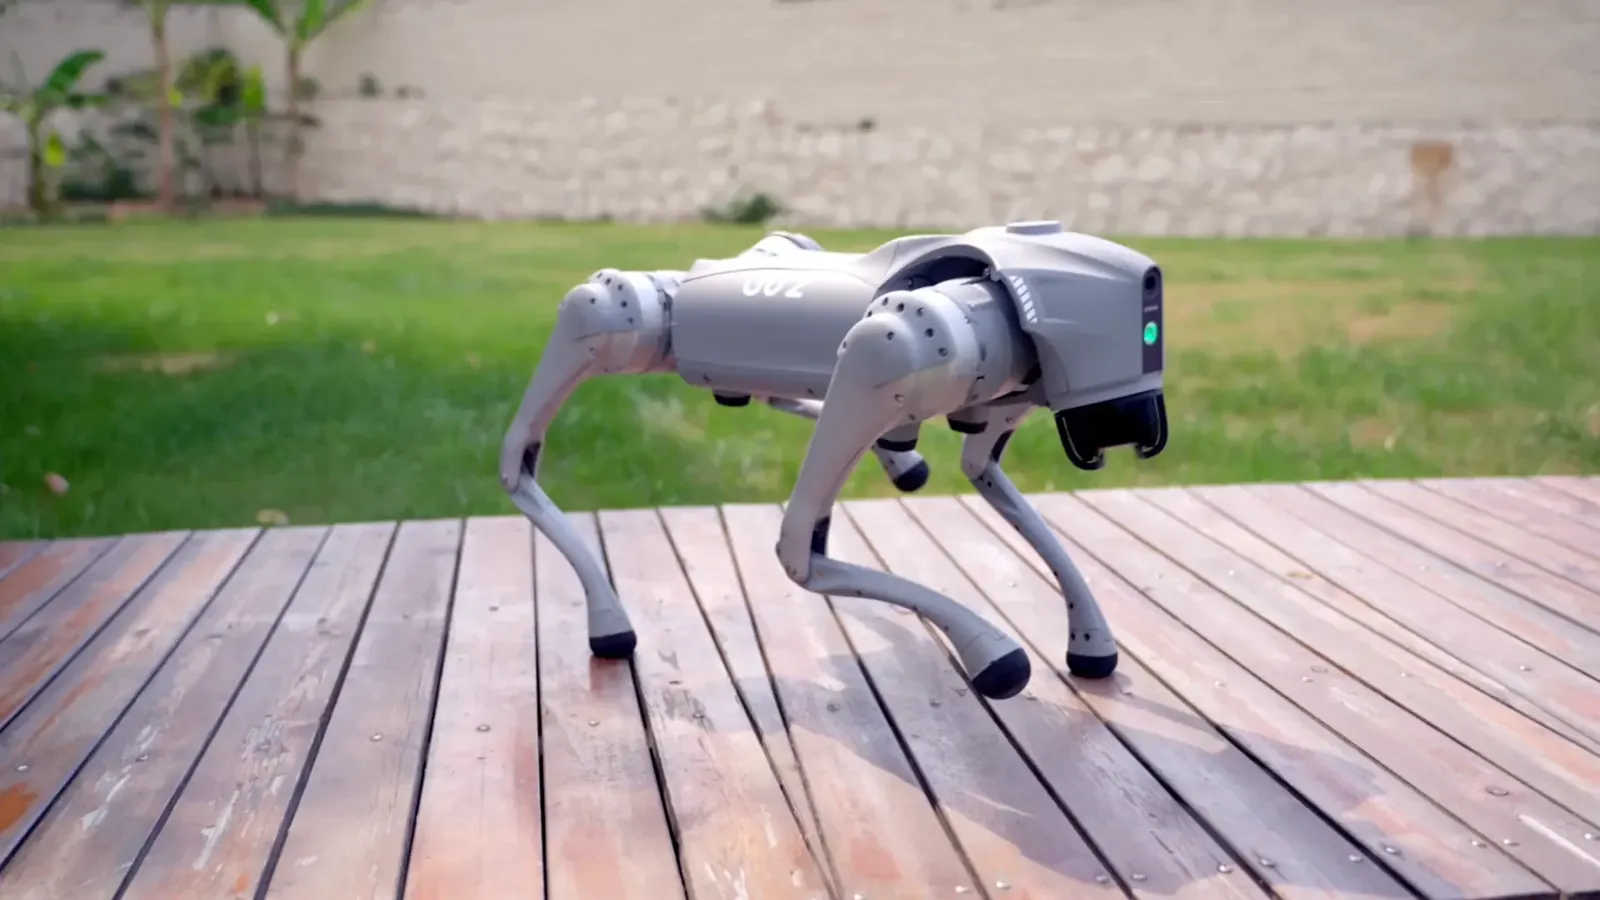
Boston Dynamics Spot vs Unitree Go2: Price & Feature Comparison
Boston Dynamics Spot vs Unitree Go2: detailed price, specs, and feature comparison. Current RCSV store prices for both. Which robot dog is right for you?
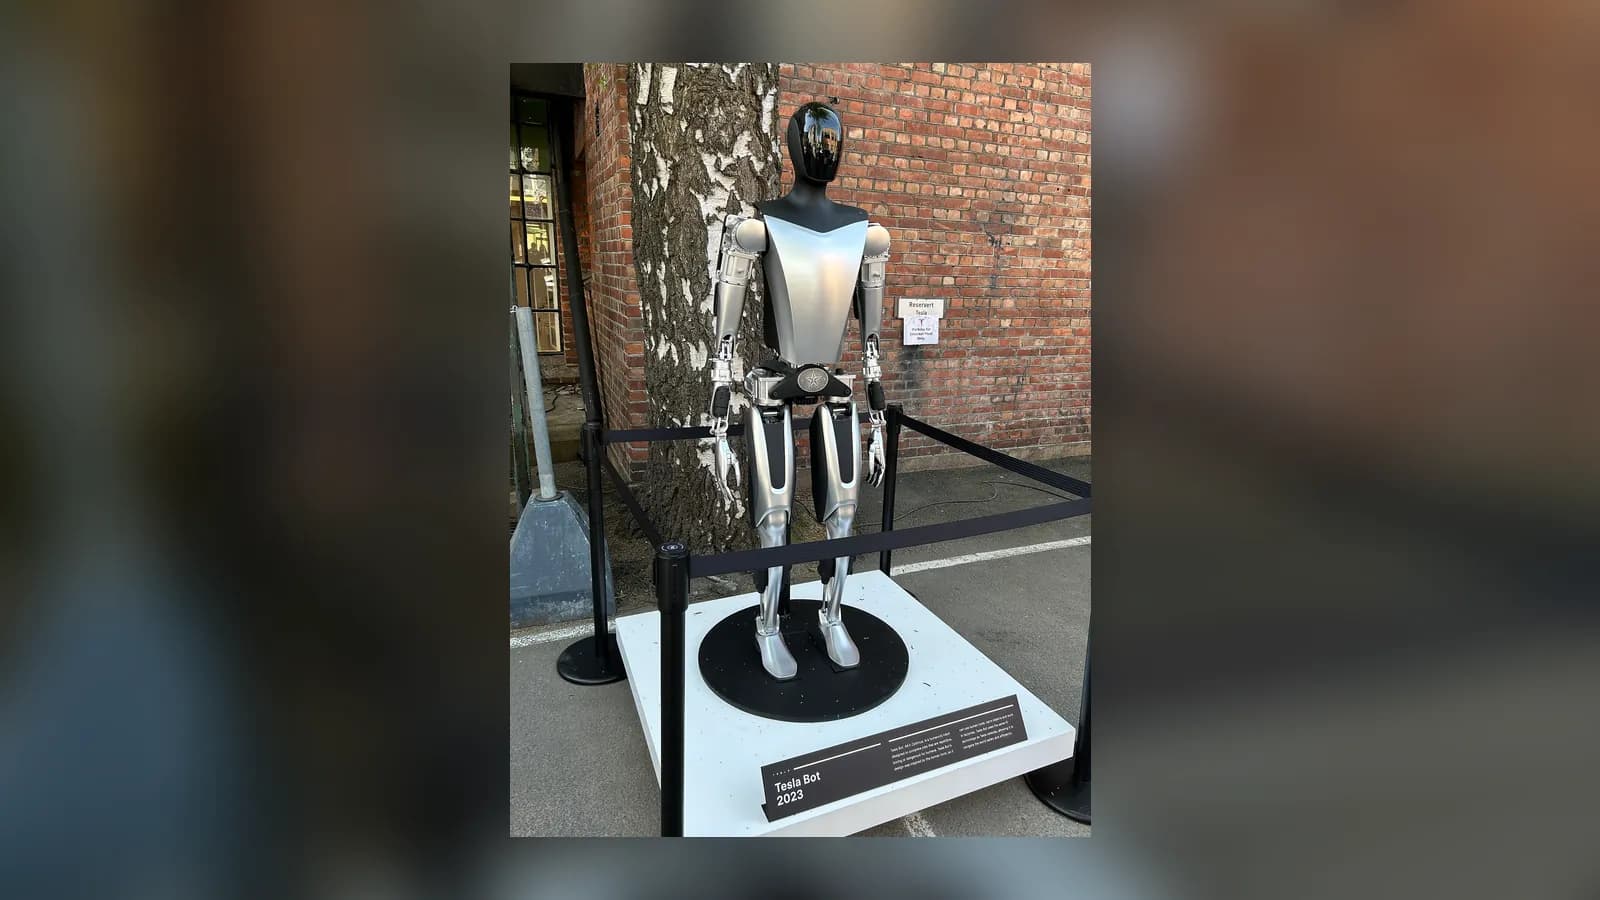
Tesla Optimus Price and Release Date (2026): What Tesla Has Said, With Sources
Tesla has not published an Optimus price or order page. Here is what Tesla and Elon Musk have said about cost and timing, each with a source, plus humanoid robots you can order today.
State of Robot Learning, Q1 2026: What Shipped, What Stalled
A practitioner review of Q1 2026 robot learning: LeRobot, OpenVLA, Octo, RT-X, Diffusion Policy, humanoid hardware launches, funding, and open-vs-closed dynamics.
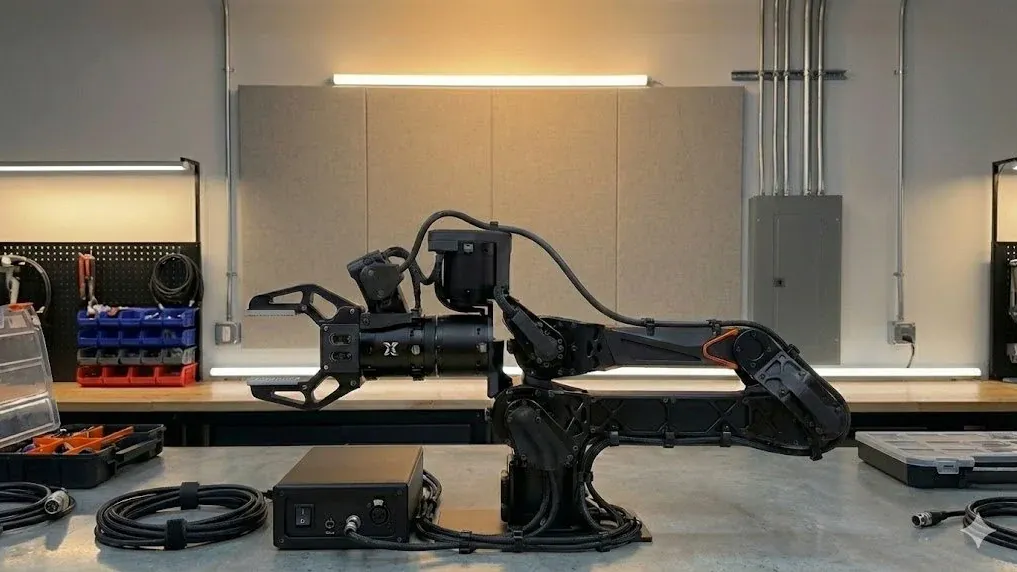
Mobile ALOHA Cost Breakdown 2026: Full BOM, Hidden Costs, and Cheaper Alternatives
Complete Mobile ALOHA cost breakdown: AgileX Tracer ($8,500) + dual ViperX 300 arms ($7,000 each) + compute + misc = ~$32,000 total. Plus 3 lower-cost alternatives from RCSV.
Physical AI in 2026: Definition, VLA Models, Data & Build Workflow
What physical AI is, the VLA models behind it, why robot data matters, and how to start learning with a first project in 2026.
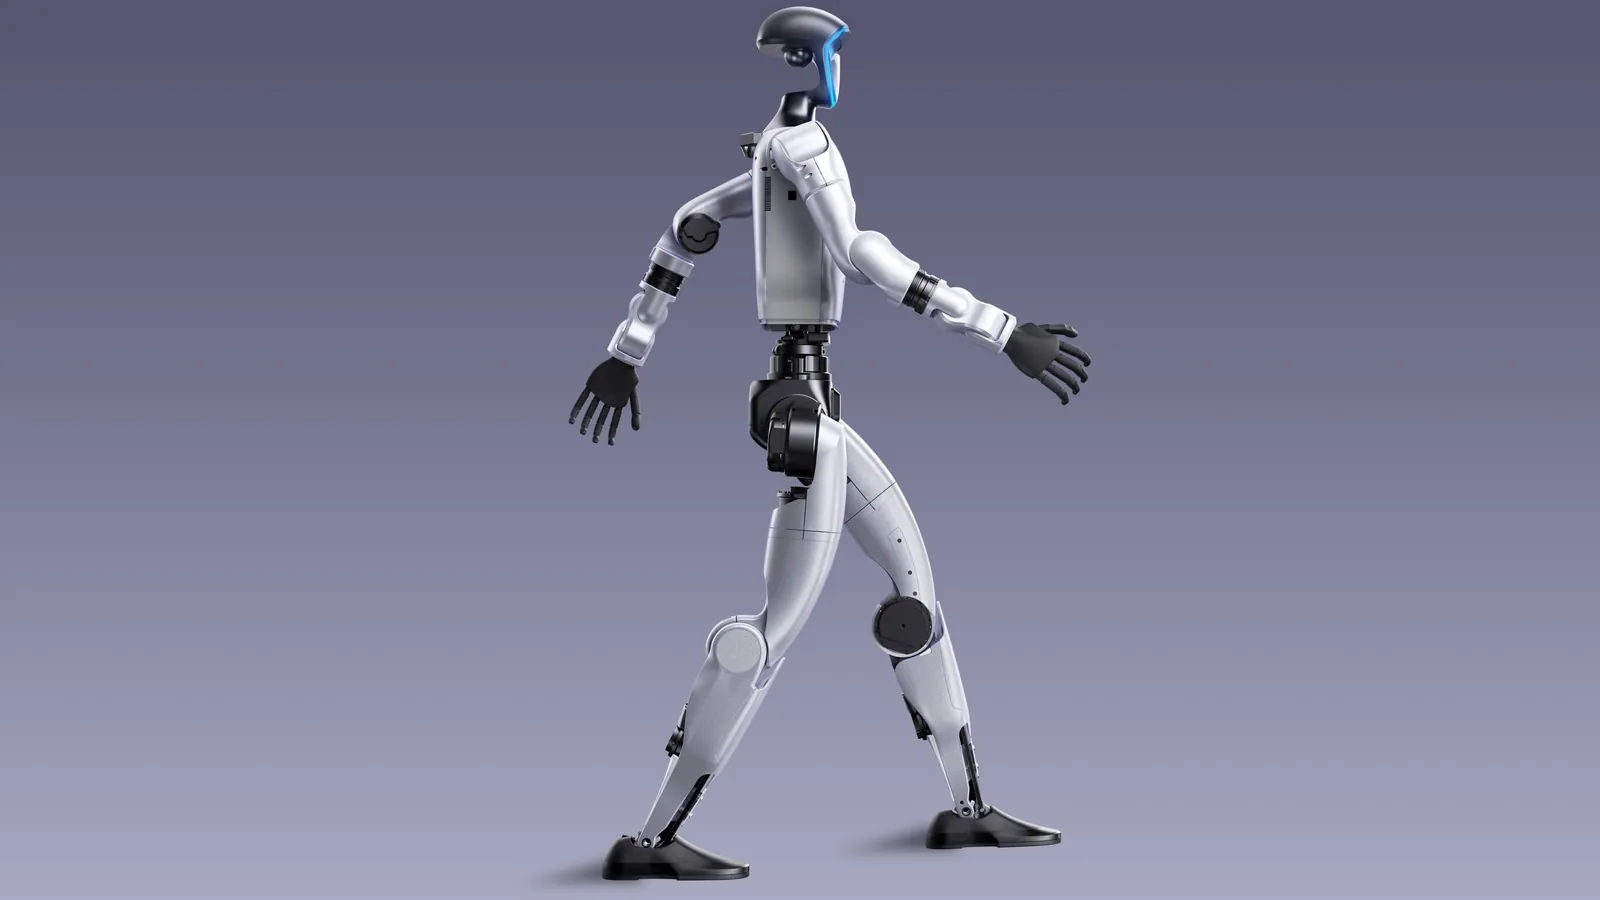
Unitree G1 vs Tesla Optimus Gen 2: Full Comparison (2026)
Unitree G1 vs Tesla Optimus Gen 2 — specs, price, availability, use cases. Which humanoid robot should you choose in 2026?
VR Teleoperation Companies Compared: Who's Leading in 2026?
Compare the leading VR teleoperation platforms for robot data collection — RCSV, Embodied Intelligence, Physical Intelligence, Dexterous, and open-source options.
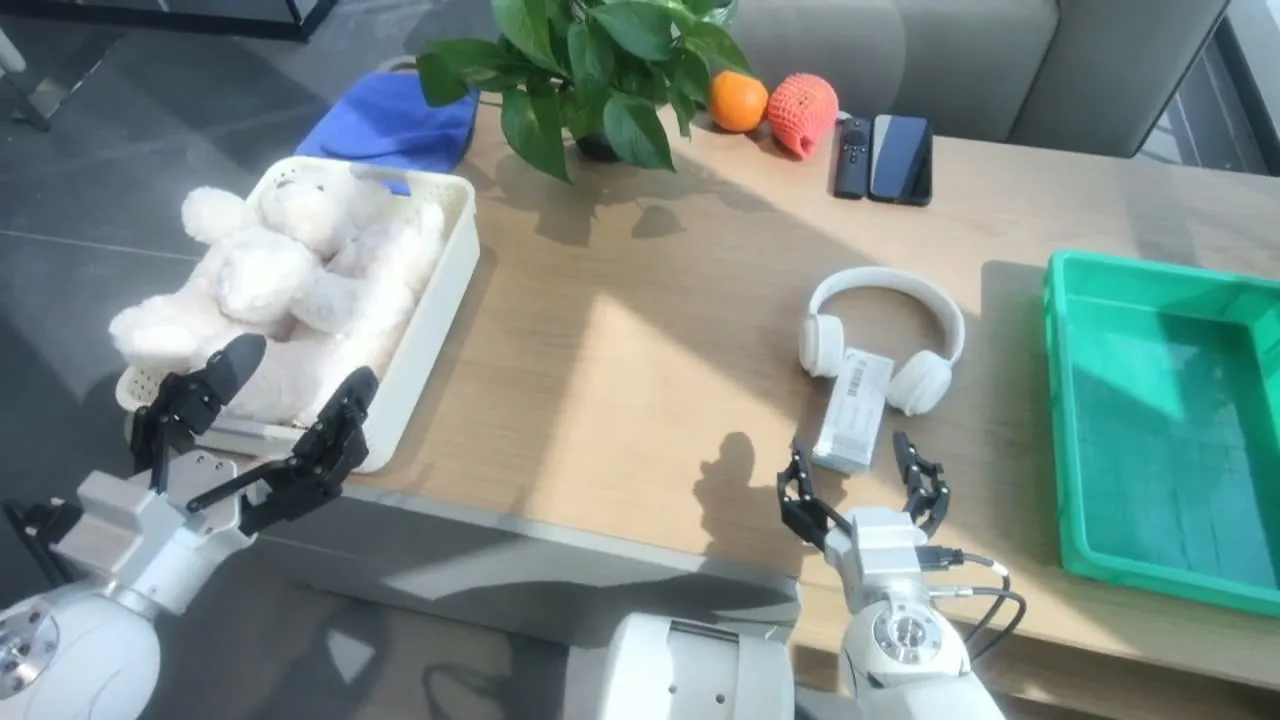
Why Bimanual Manipulation Is the Next Frontier in Robot Learning
Two hands unlock tasks one cannot: laundry, cable routing, cooking, assembly. A practitioner analysis of ALOHA, Mobile ALOHA, data scarcity, and hardware bottlenecks.
ACT vs. Diffusion Policy: A Practical Guide to Choosing the Right Algorithm
When to use Action Chunking with Transformers (ACT) vs. Diffusion Policy for robot manipulation — latency, task complexity, and training data tradeoffs.
Best Dexterous Robot Hands for Research and Manipulation in 2025
Comparison of dexterous robot hands — Shadow, Inspire, Unitree, Leap Hand, and others — for teleoperation and manipulation learning.
Building a Robot Kitchen Assistant: Technical Challenges and Where We Are in 2025
What it takes to build a robot that can cook — manipulation challenges, current deployments, and the engineering required for reliable kitchen automation.
10 Common Mistakes in Robot Imitation Learning (and How to Fix Them)
The most common errors teams make when training robot policies with imitation learning — data quality, algorithm choice, evaluation, and deployment mistakes with specific fixes for each.
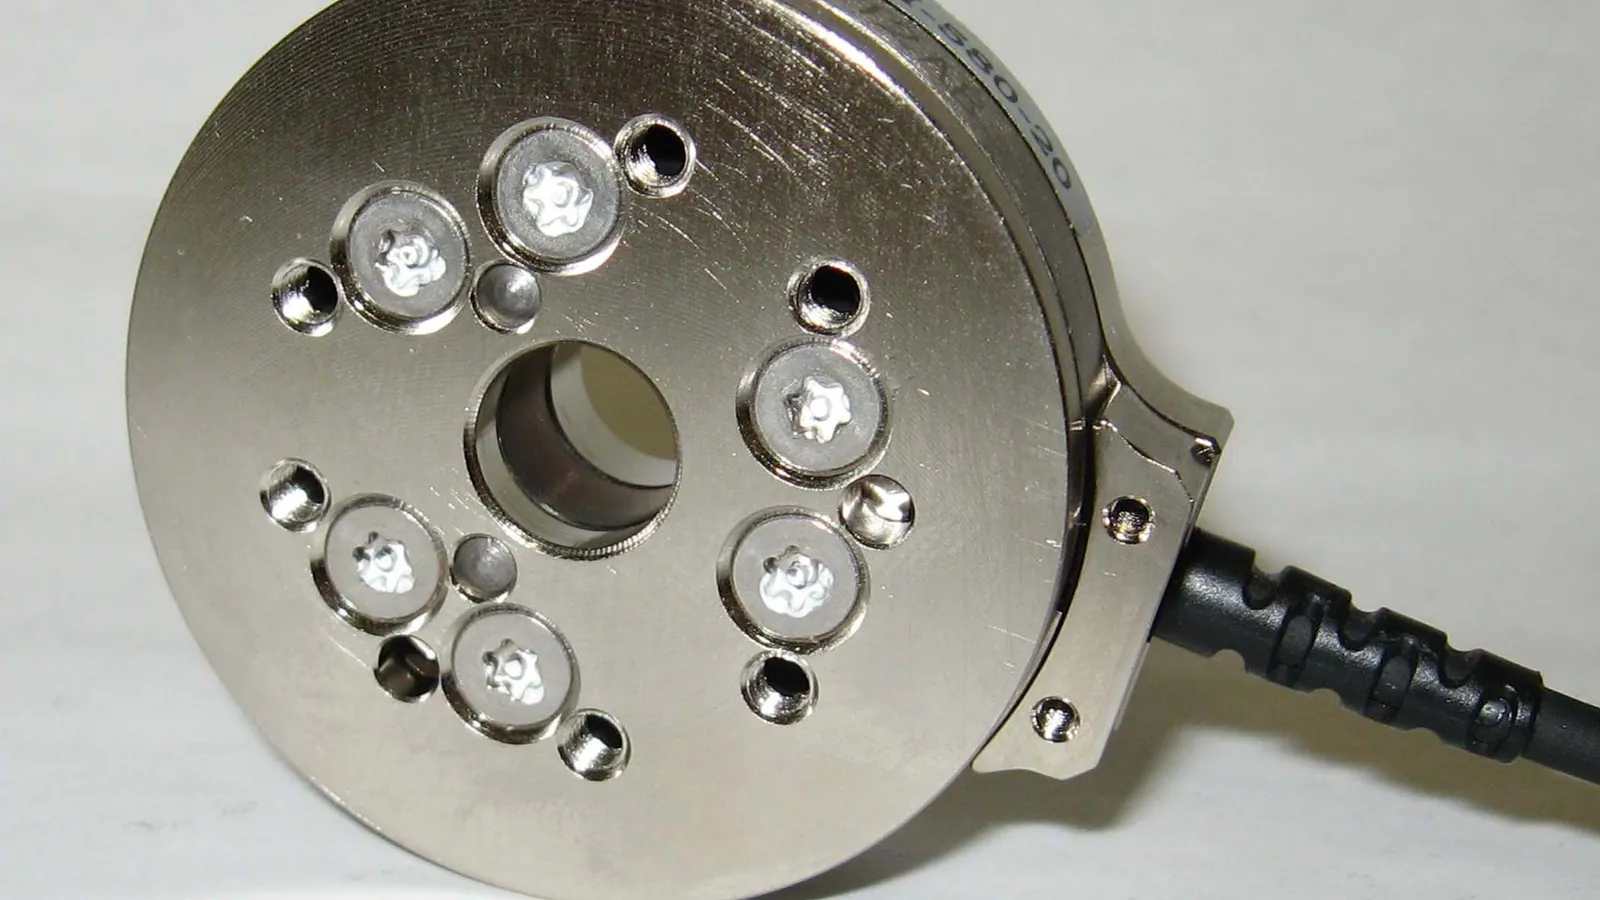
Why Contact Forces Are the Key to Dexterous Robot Manipulation
How force sensing transforms manipulation — the physics of contact, why vision alone fails, and practical strategies for contact-rich tasks.
Embodied AI Explained: What It Is, Why It Matters, and Where It's Headed
A clear explanation of embodied AI — why physical interaction with the world is the next frontier for AI, and what it means for robotics teams building today.
The Robot Training Data Market: 2026 Outlook and What It Means for Your Team
Analysis of the robot training data market — size, pricing trends, data flywheel dynamics, and the infrastructure layer emerging for physical AI.
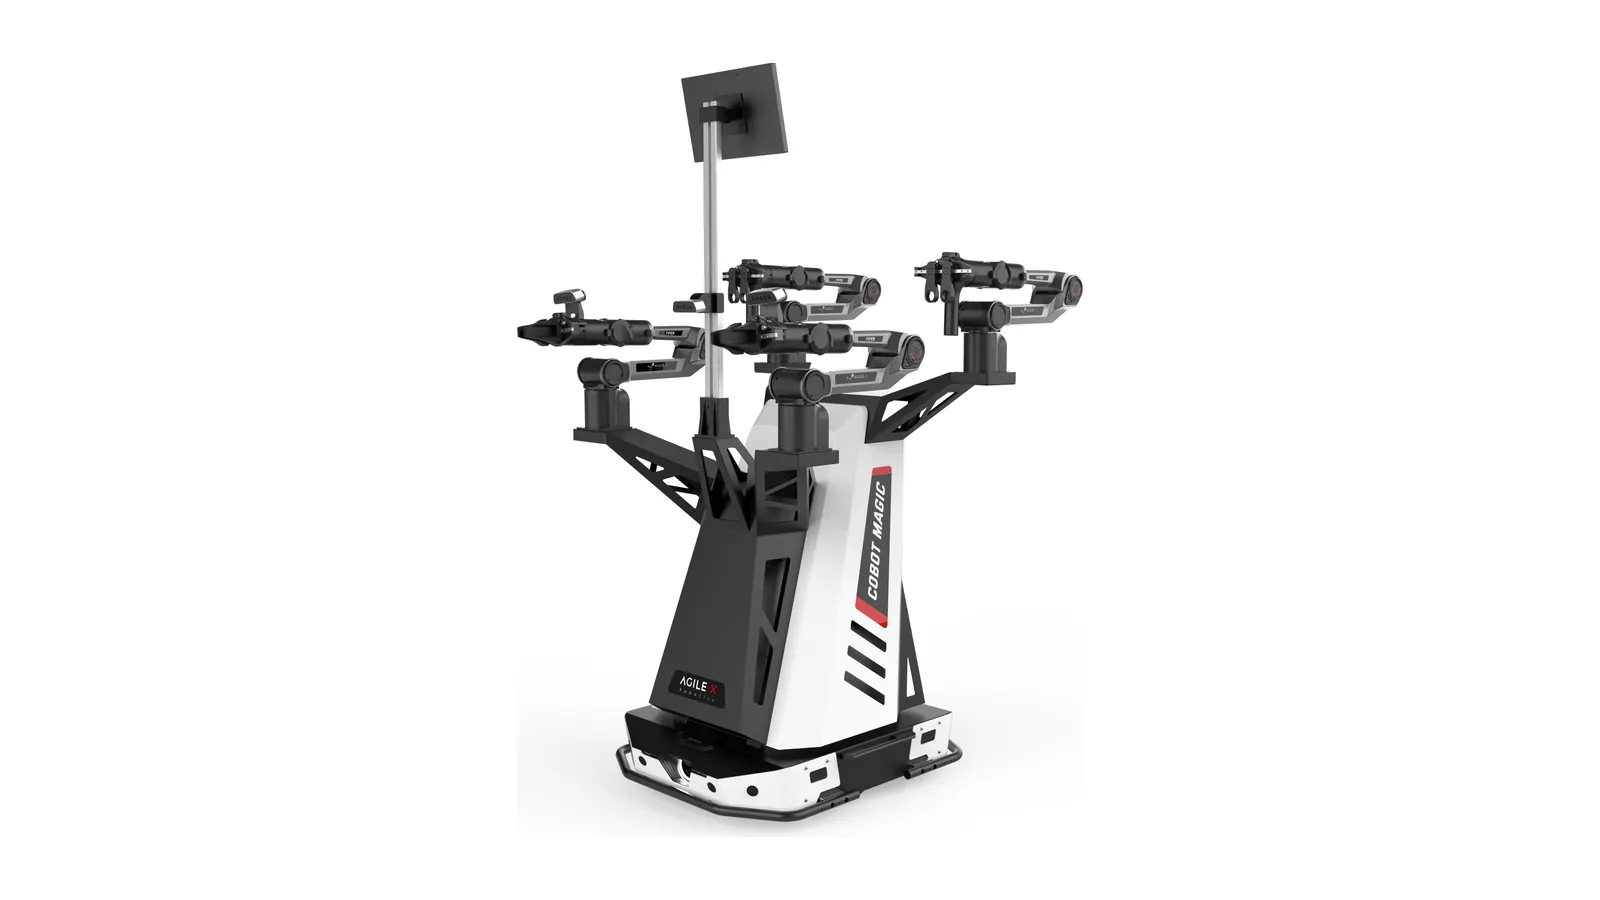
Mobile Manipulation in 2025: State of the Art and Practical Deployments
Survey of mobile manipulation robots — platforms, capabilities, algorithms, and real-world deployments combining locomotion and arm manipulation.
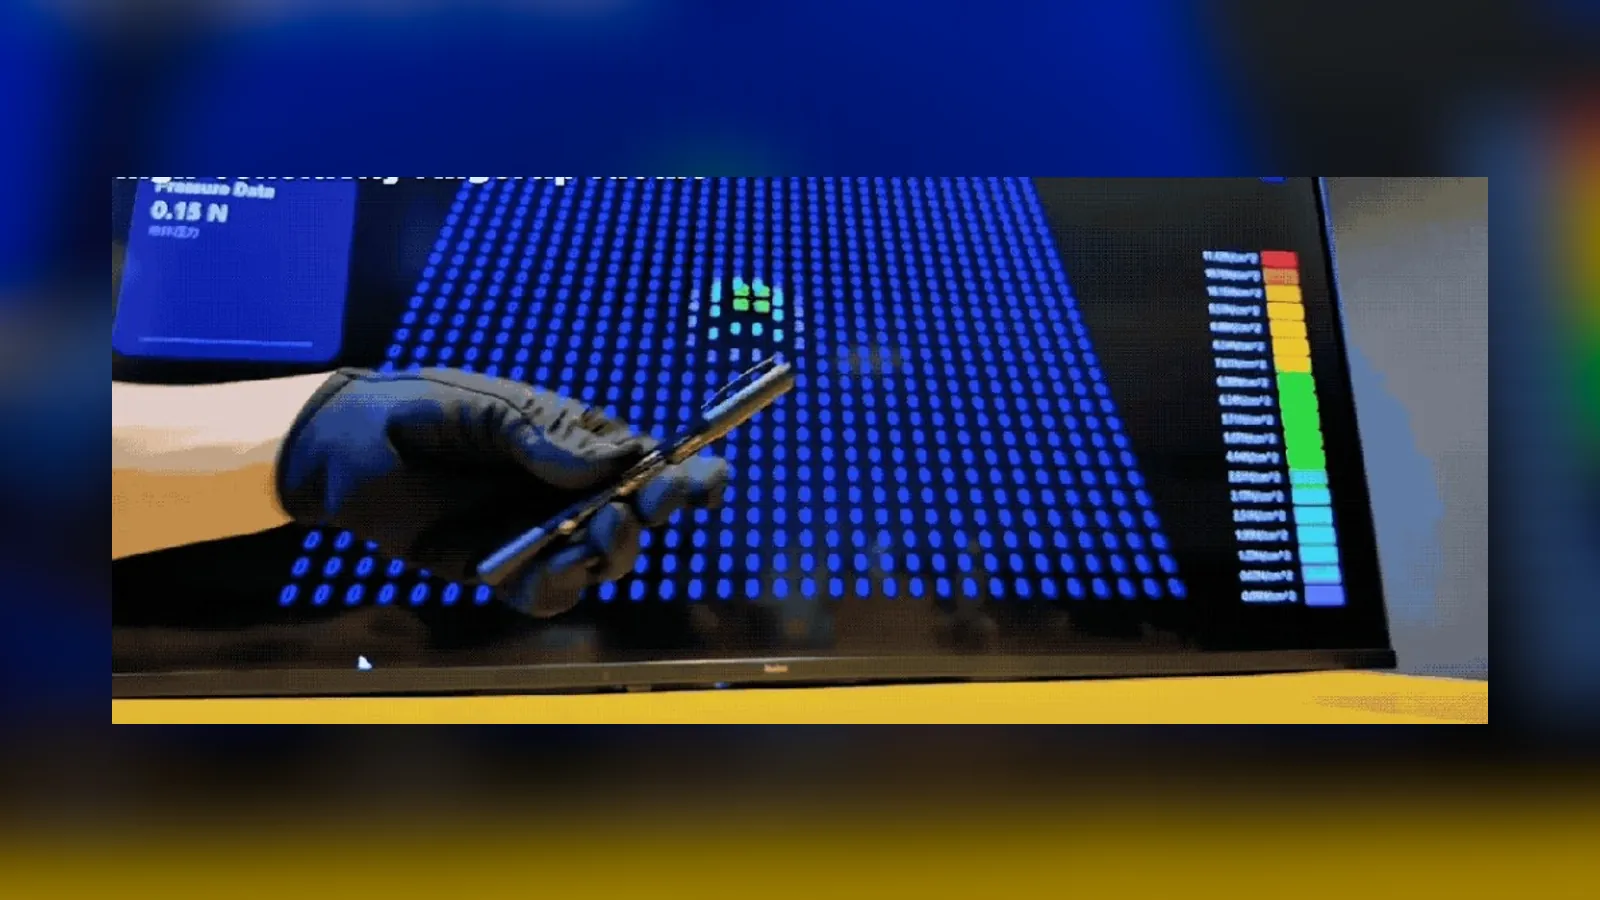
Multimodal Sensing for Robot Manipulation: Vision, Force, and Tactile Fusion
How to combine vision, force/torque, and tactile sensing for robust robot manipulation — sensor fusion architectures and practical implementation.
Getting Started With NVIDIA Isaac Lab for Robot Policy Training
Practical Isaac Lab setup guide — installation, built-in environments, RL training walkthrough, performance tips, and sim-to-real export.
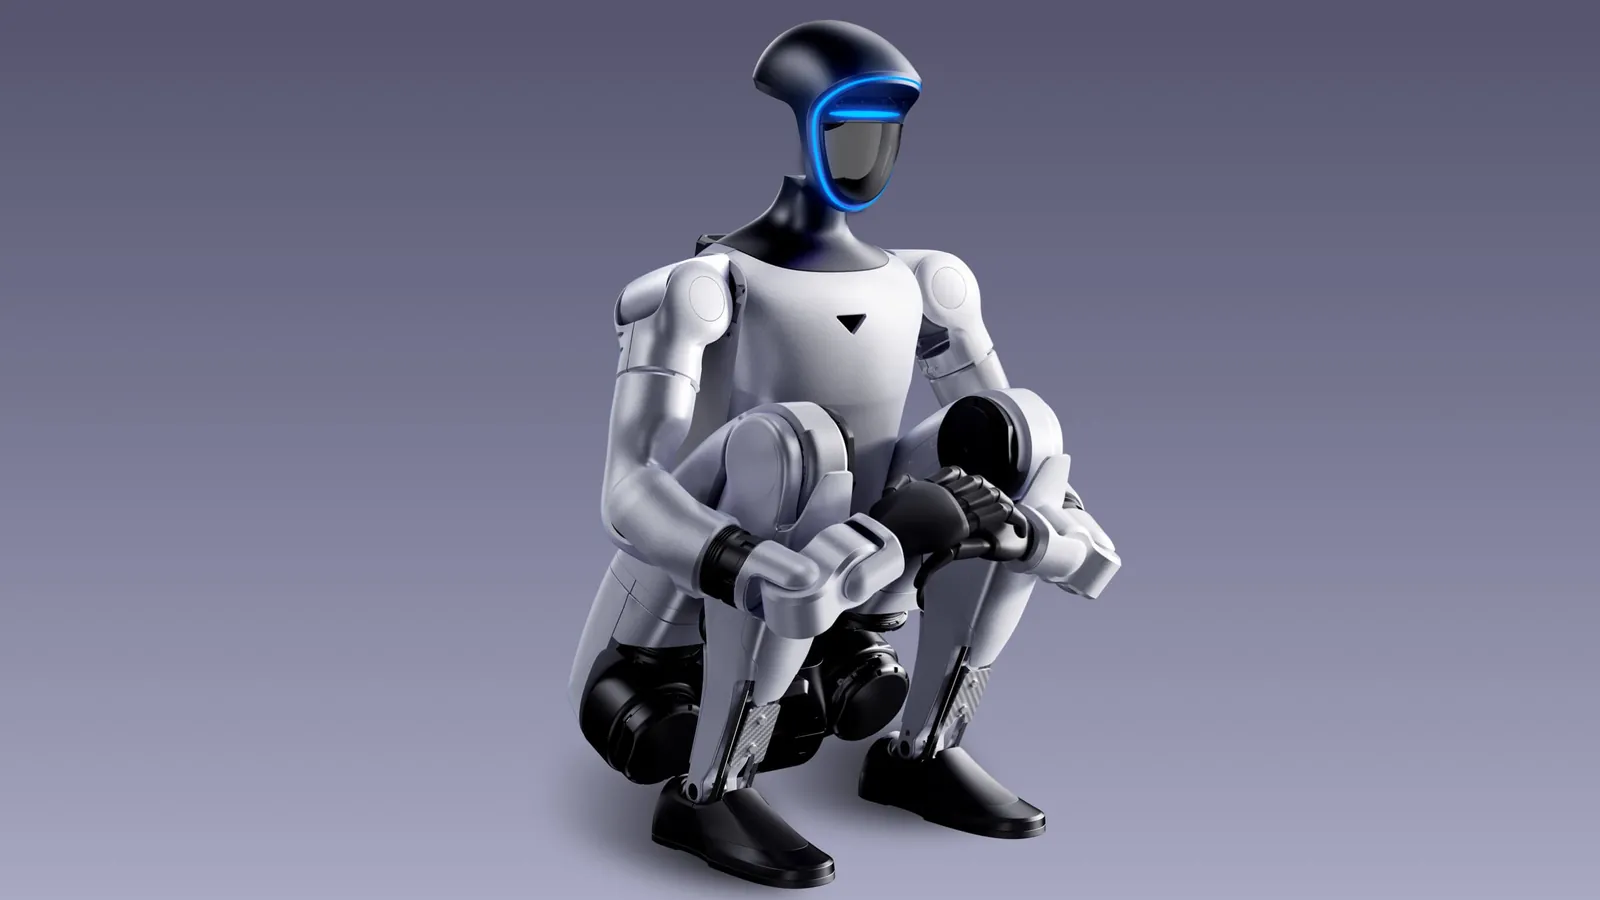
Open-Source Humanoid Robots in 2025: A Practical Guide
Overview of open-source humanoid robot platforms — Unitree G1, Open Humanoid, and community projects — with build costs and software ecosystems.
Reward Shaping for Robot Manipulation RL: What Works and What Doesn't
Practical guide to reward engineering for robot manipulation — dense vs sparse rewards, potential-based shaping, curriculum reward progression, sim-to-real gaps, and how to avoid reward hacking.
Cross-Embodiment Robot Training: Can You Transfer Across Different Robots?
What the research shows about training on multiple robot types to improve generalization — Open X-Embodiment, DROID, RT-2-X, Octo, and practical co-training setup with code examples.
Robot Data Privacy and Security for Enterprise Deployments
Security and privacy considerations for enterprise robot deployments — video data handling, network security, IP protection, and compliance.
Robot Grasp Planning in 2025: From Geometric Methods to Learned Policies
Survey of robot grasp planning — GQ-CNN, GraspNet, AnyGrasp, and when to use learned vs. geometric methods for your application.
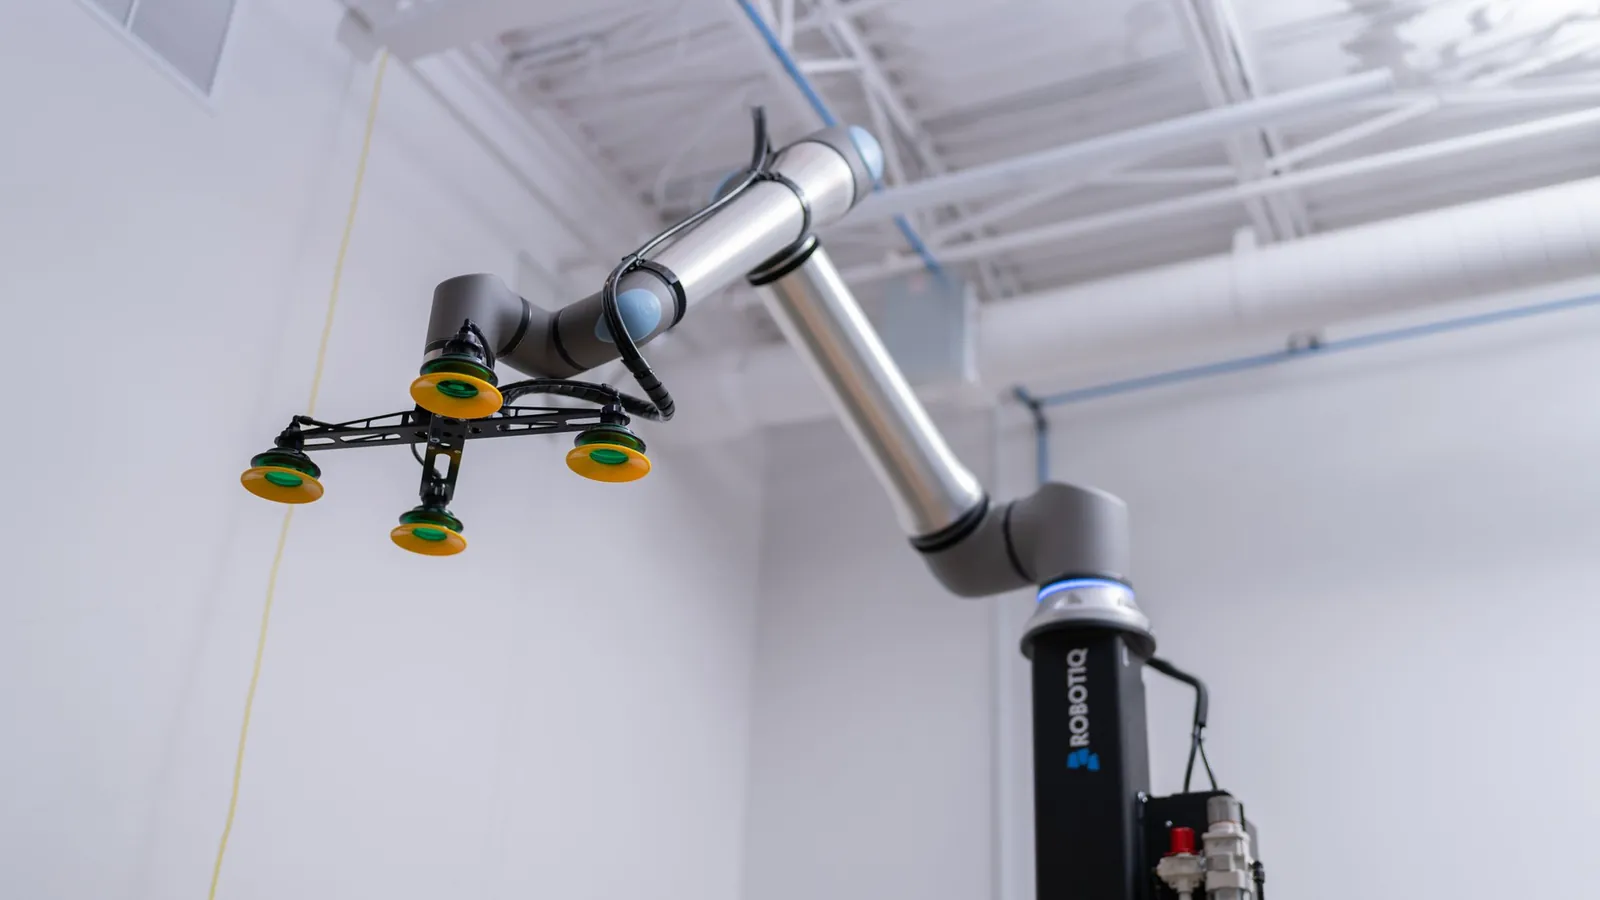
Suction Grippers vs. Parallel Jaw Grippers: When to Use Each
Practical comparison of suction cup and parallel jaw grippers for robot manipulation — picking speed, object compatibility, and application fit.
The True Cost Per Robot Demonstration: A 2025 Analysis
Breaking down the real cost of a single robot training demonstration — operator time, hardware amortization, annotation, and QA overhead.
Robot Learning from Video: State of the Art in 2026
Comprehensive survey of robot learning from video in 2026: visual pre-training (R3M, MVP), Video-Language-Action models, what works, what doesn't, and practical implications for data collection.
Robot Learning vs Classical Robotics: When to Use Each (2026)
Robot learning vs classical robotics: a practical decision framework covering perception-planning-control pipelines, end-to-end learned policies, hybrid architectures, and when each approach wins in 2026.
Robot Learning Startup Tech Stack: Key Decisions in 2025
Technology decisions for robotics startups — ROS2 vs custom middleware, simulation choice, cloud vs edge inference, and data platform strategy.
Scaling Laws for Robot Learning: What We Know in 2026
Do scaling laws apply to robot learning? Evidence from Open X-Embodiment, RT-X, DROID, and practical implications for data collection, model size, and compute budgets in 2026.
Scaling Robot Data Collection Teams: From 1K to 100K Demonstrations
Operational lessons from scaling teleoperation teams — operator tiers, quality control at scale, infrastructure choices, and per-demo cost curves.
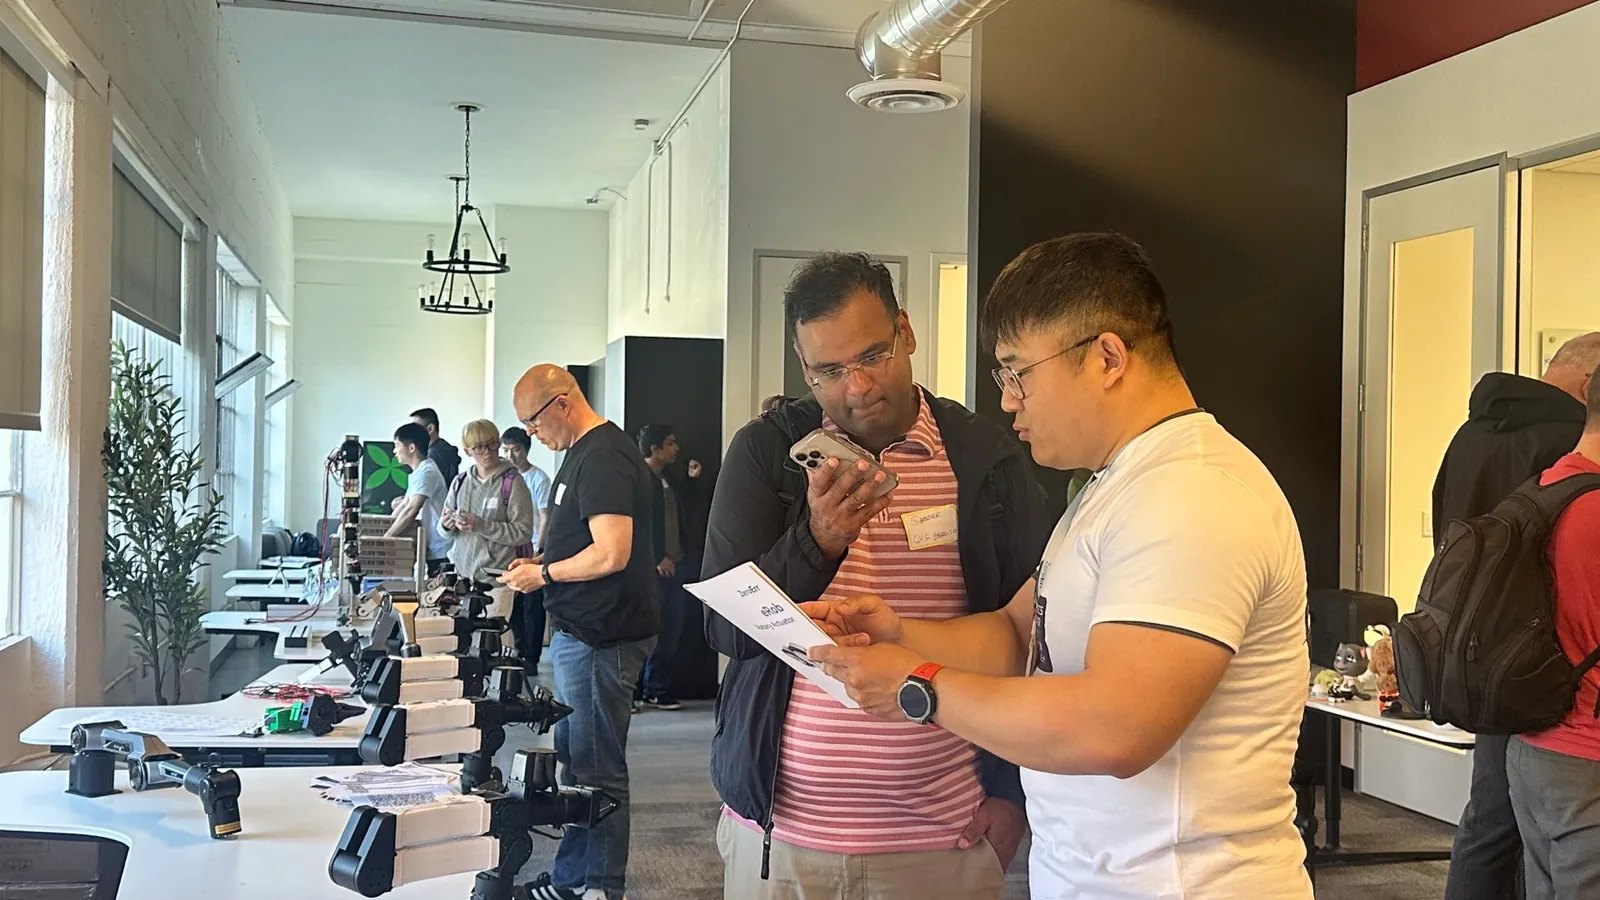
Inside the RCSV San Francisco Robotics Lab: Infrastructure, Fleet, and Research
An inside look at the RCSV San Francisco lab — our robot fleet for data collection, research infrastructure, GPU cluster, and how we support customers building embodied AI.
Teleoperation Fatigue and Ergonomics: What the Research Says
Research summary on operator fatigue in robot teleoperation — ergonomic risk factors, fatigue indicators, scheduling recommendations, and workstation design.
Robot Teleoperation Over the Internet: Handling Latency and Packet Loss
Engineering strategies for remote robot teleoperation over internet — latency compensation, video streaming, control law adaptation, and connection requirements.
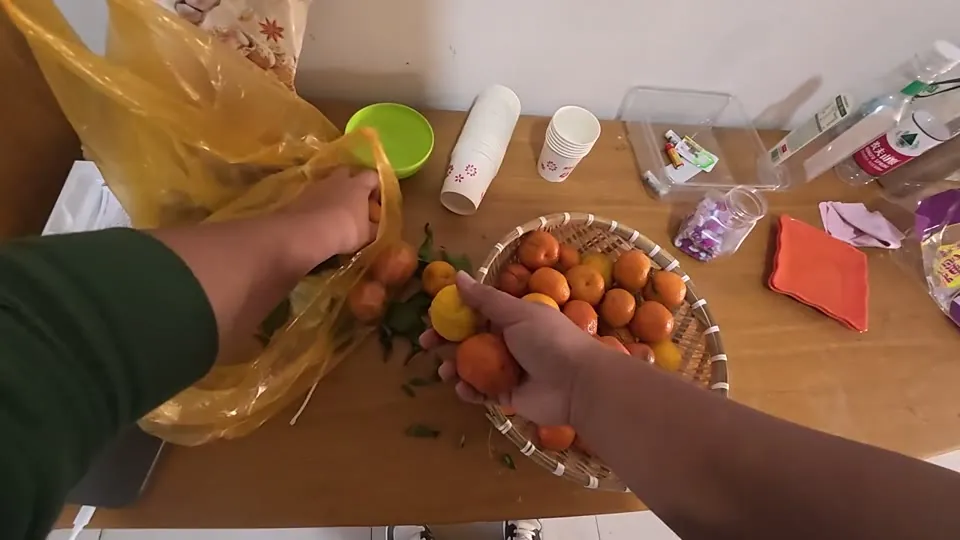
What Makes Good Robot Training Data? A Practical Framework
A practical framework for robot training data quality: the 6 dimensions of diversity, consistency, completeness, accuracy, balance, and format -- plus a 10-point checklist.
RL vs. Imitation Learning for Robot Manipulation: A Decision Guide
When to use reinforcement learning vs. imitation learning for training robot manipulation policies — task type, data availability, and compute budget.
Why Teleoperation Data Still Beats Simulation for Training Robot Policies
Despite advances in simulation, real teleoperation demonstrations remain the gold standard for training manipulation policies. Here's why — and when sim data helps.
Zero-Shot vs. Few-Shot Robot Policies: Setting Realistic Expectations
Honest assessment of zero-shot and few-shot robot policy performance in 2025 — what's achievable, on which tasks, and what's still hype.
Scaling VLA Model Training on a Budget: Lessons From 100+ Fine-Tunes
LoRA/QLoRA, gradient checkpointing, FlashAttention, A100/H100 vs consumer GPUs, and the dataset-vs-model tradeoff — the VLA fine-tune playbook at real-world budgets.
ACT Policy Explained: Action Chunking with Transformers for Robot Learning
How ACT (Action Chunking with Transformers) works, why it's popular for robot learning, and how to train it.
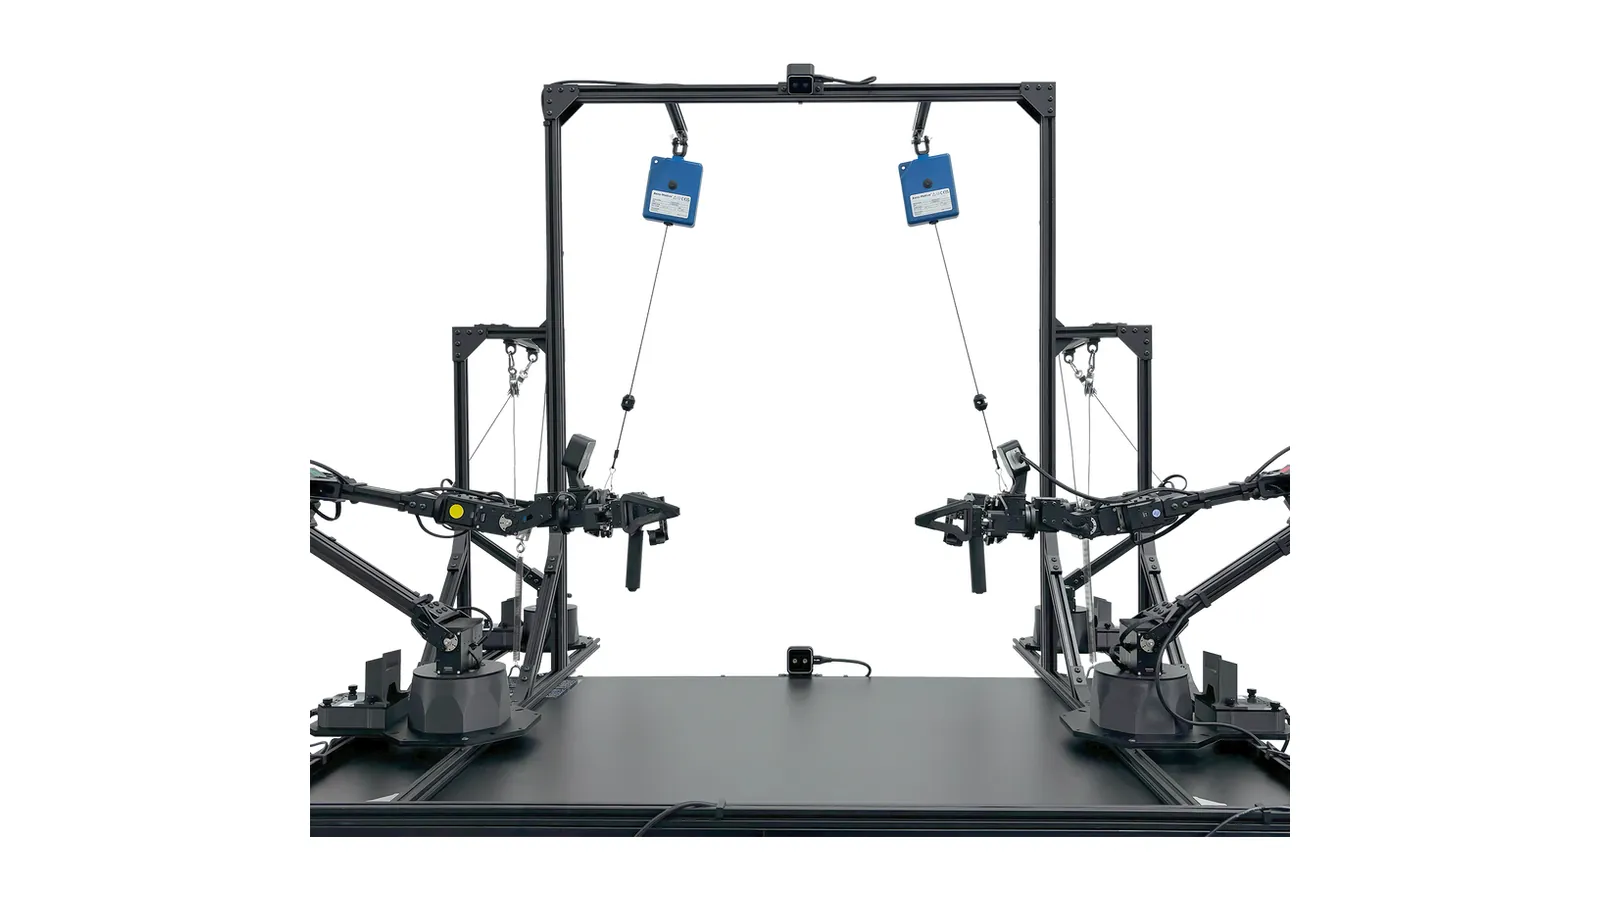
ALOHA Robot: What It Is, How It Works, and How to Get Started
ALOHA robot guide: Stanford's bimanual teleoperation platform with dual ViperX arms. Full BOM, ACT training setup, and cost-effective bimanual alternatives from RCSV.
Diffusion Policy for Robot Learning: What It Is and How to Use It
Diffusion Policy explained: U-Net vs transformer backbones, DDPM vs DDIM inference, Robomimic results against BC and ACT, and the 100-200 demos it needs.
Force-Torque Sensing in Robotics: Applications, Sensors, and Getting Started
Practical guide to force-torque sensing for robots: 5 key applications, sensor selection guide, ROS2 integration tutorial, admittance control basics, and how F/T sensing enables contact-rich manipulation.
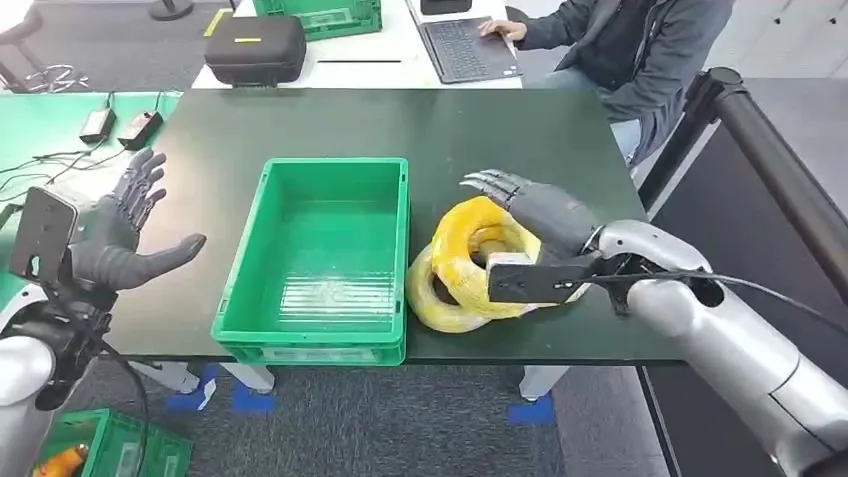
Getting Started with Robot Teleoperation in 2026
A practical guide to getting started with robot teleoperation in 2026: hardware setup, control interfaces, latency, data collection, and RCSV's teleop platform.
Humanoid Robots in 2026: The Complete Market Overview
Humanoid robots in 2026: who makes them, what each platform is built for, published specs, live prices for the models you can buy today, and how to decide between buying, leasing and waiting.
Imitation Learning for Robots: A Practical Guide
How robot imitation learning works: BC, DAgger, ACT, Diffusion Policy and VLAs compared, with demos needed per method (50 for ACT), data and hardware.
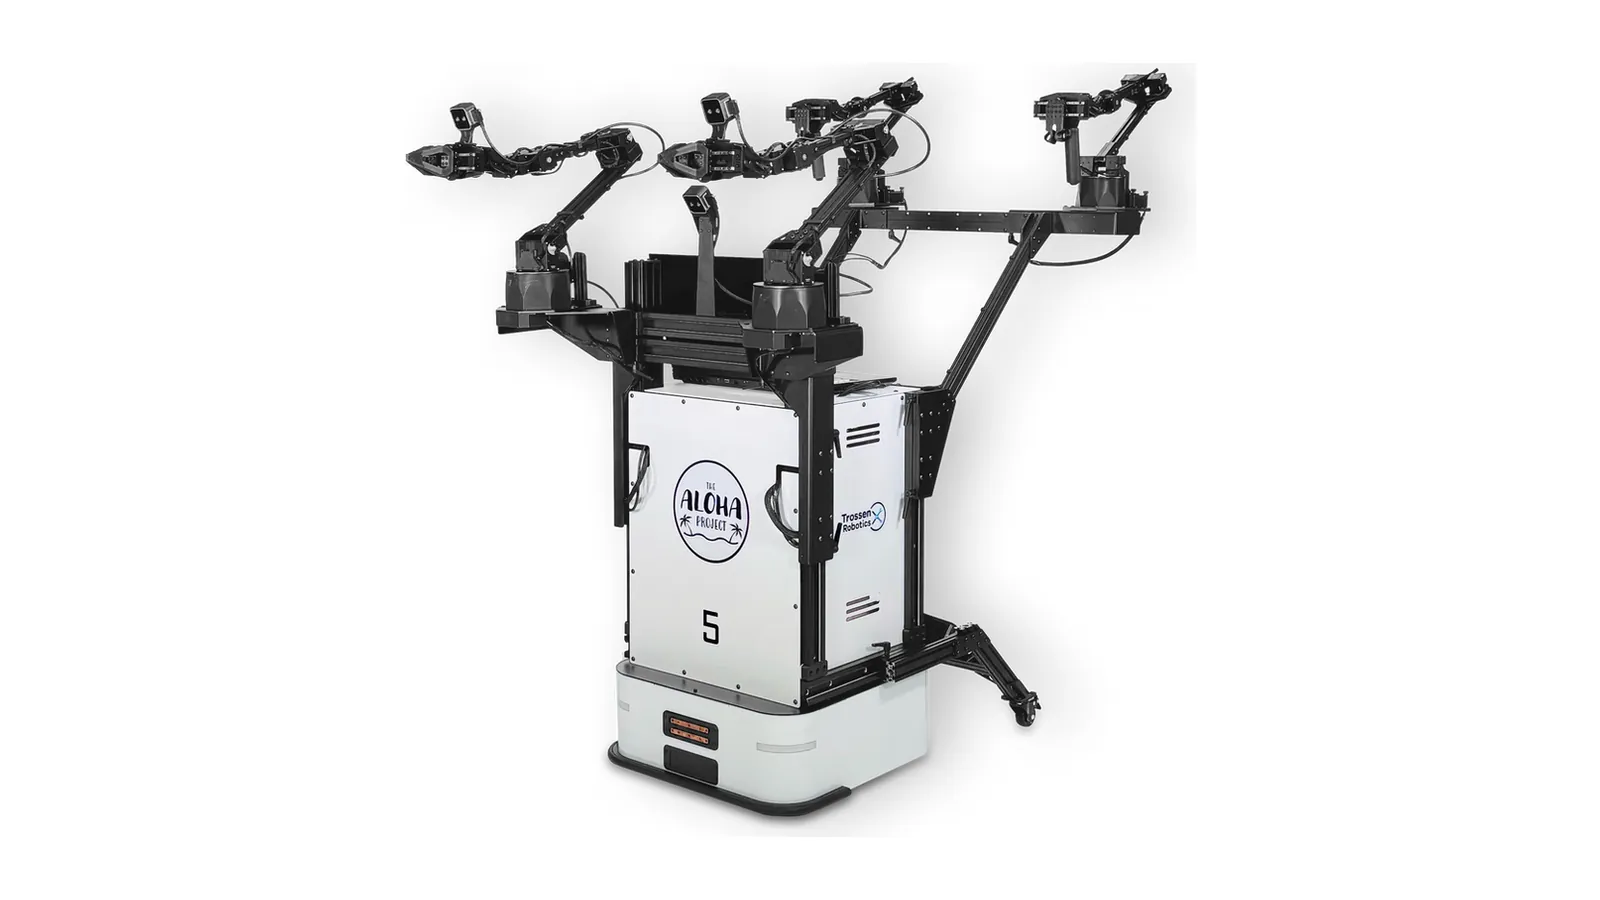
Mobile ALOHA Setup Guide: Hardware, Software, and First Tasks
Mobile ALOHA costs: AgileX Tracer base, ViperX 300 arms, compute — total BOM ~$32K. Plus 3 cheaper alternatives. Complete ROS2 setup and ACT training walkthrough.
Open X-Embodiment: The Robot Dataset That Changed Everything
Open X-Embodiment explained: 22 robot embodiments, 1M+ trajectories, cross-embodiment transfer evidence from RT-X, how to access and use the dataset, limitations, and what comes next.
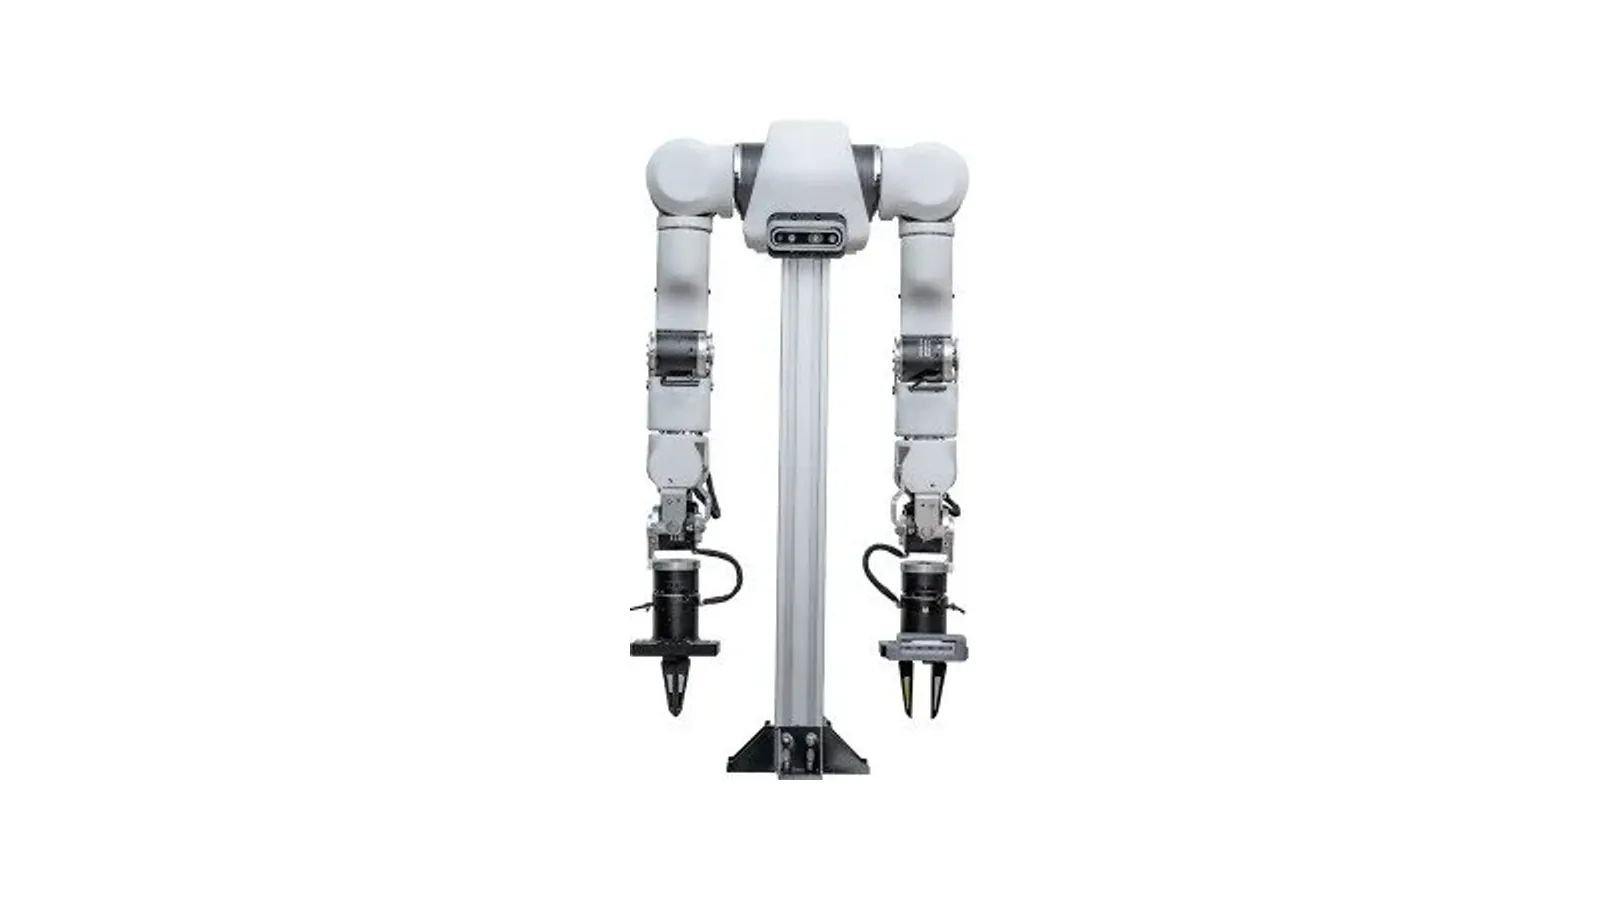
OpenArm Setup Guide: From Unboxing to First Teleoperation
Complete OpenArm setup guide: unboxing checklist, assembly steps, calibration, connecting to the RCSV platform, running your first teleoperation session, and tips for data collection.
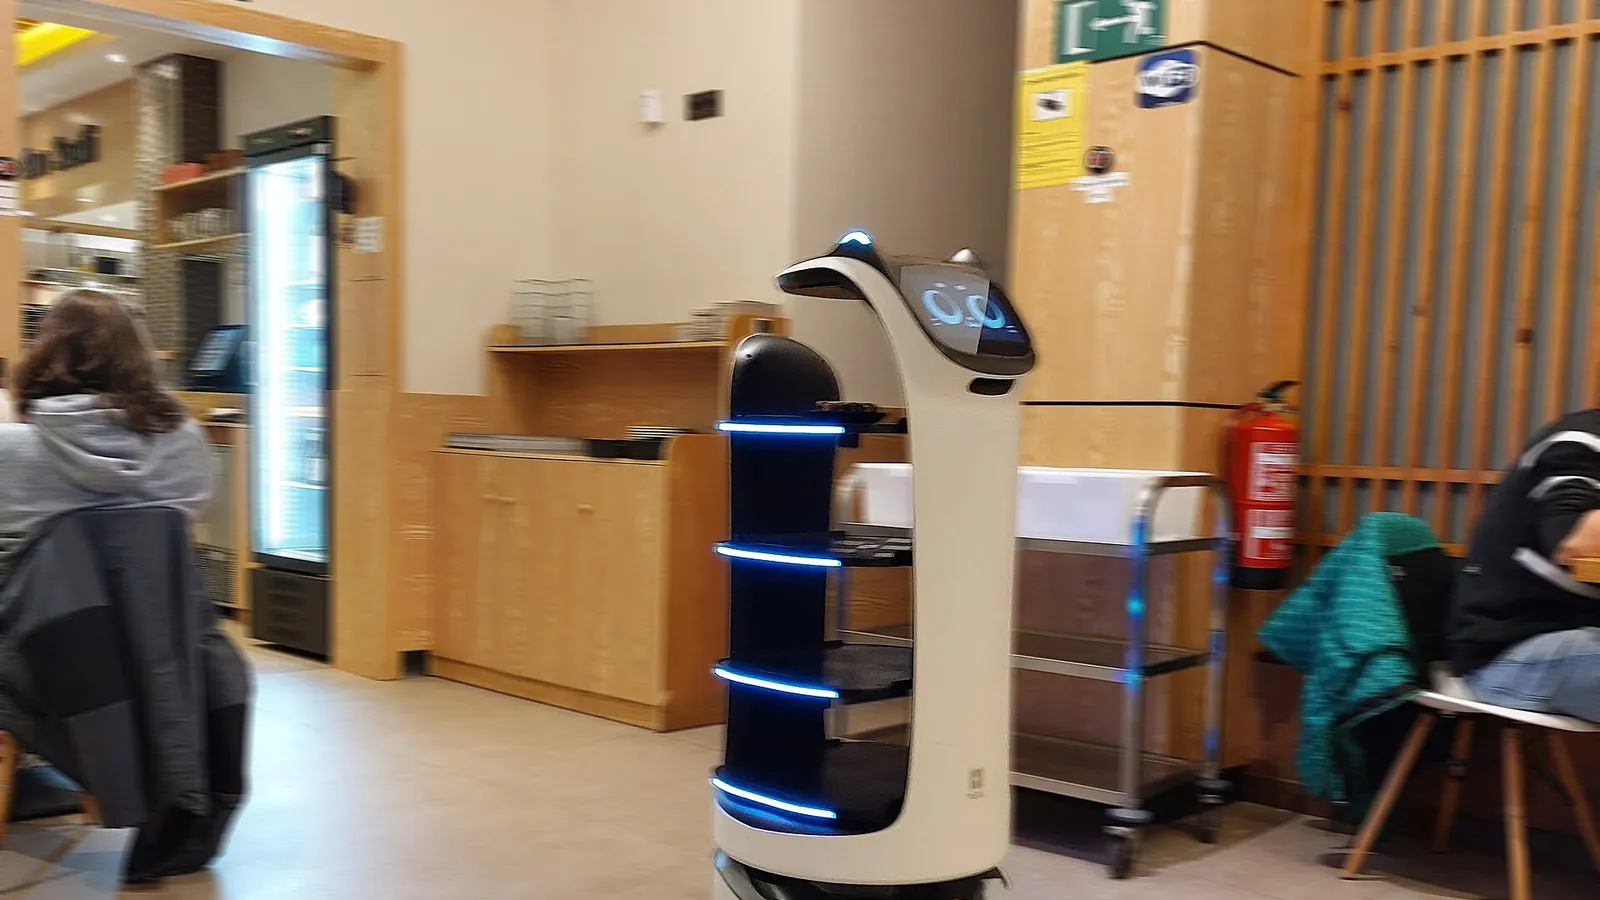
Restaurant Robots in 2026: What's Actually Deployed and What's Hype
Restaurant robots in 2026: what's actually working (serving, bussing), what's still hype (full kitchen automation), ROI analysis, key vendors, and how to evaluate a deployment for your venue.
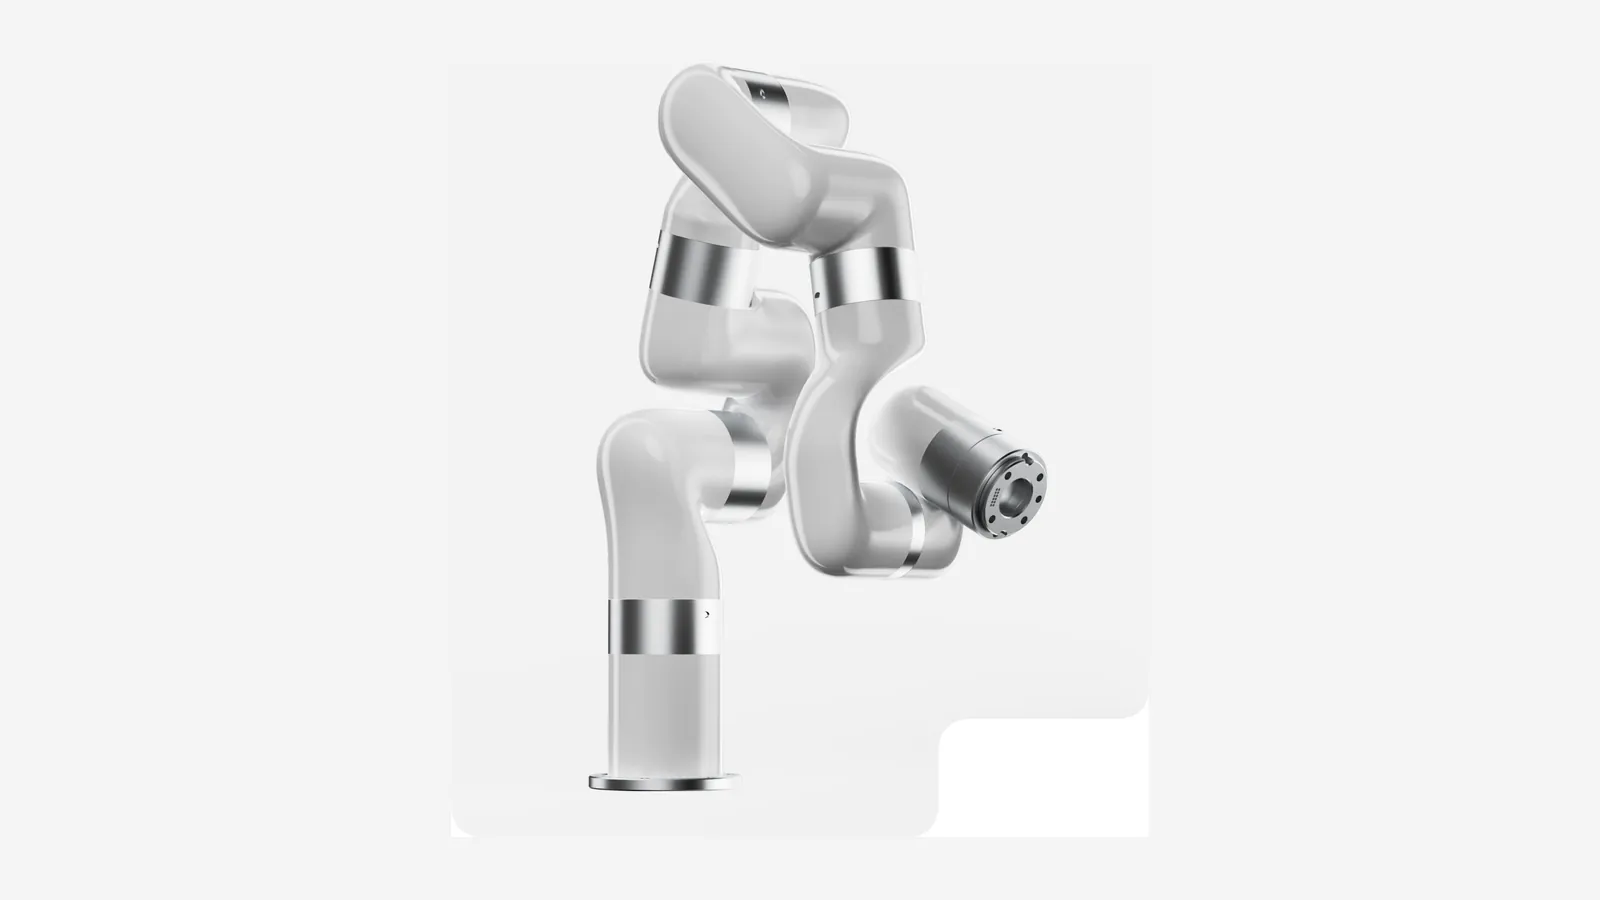
Robot Arm Buying Guide 2026: How to Choose the Right Manipulator
A complete robot arm buying guide for 2026. Compare DOF, payload, reach, open-source vs commercial options, price ranges, and get RCSV's recommendations for research and production.
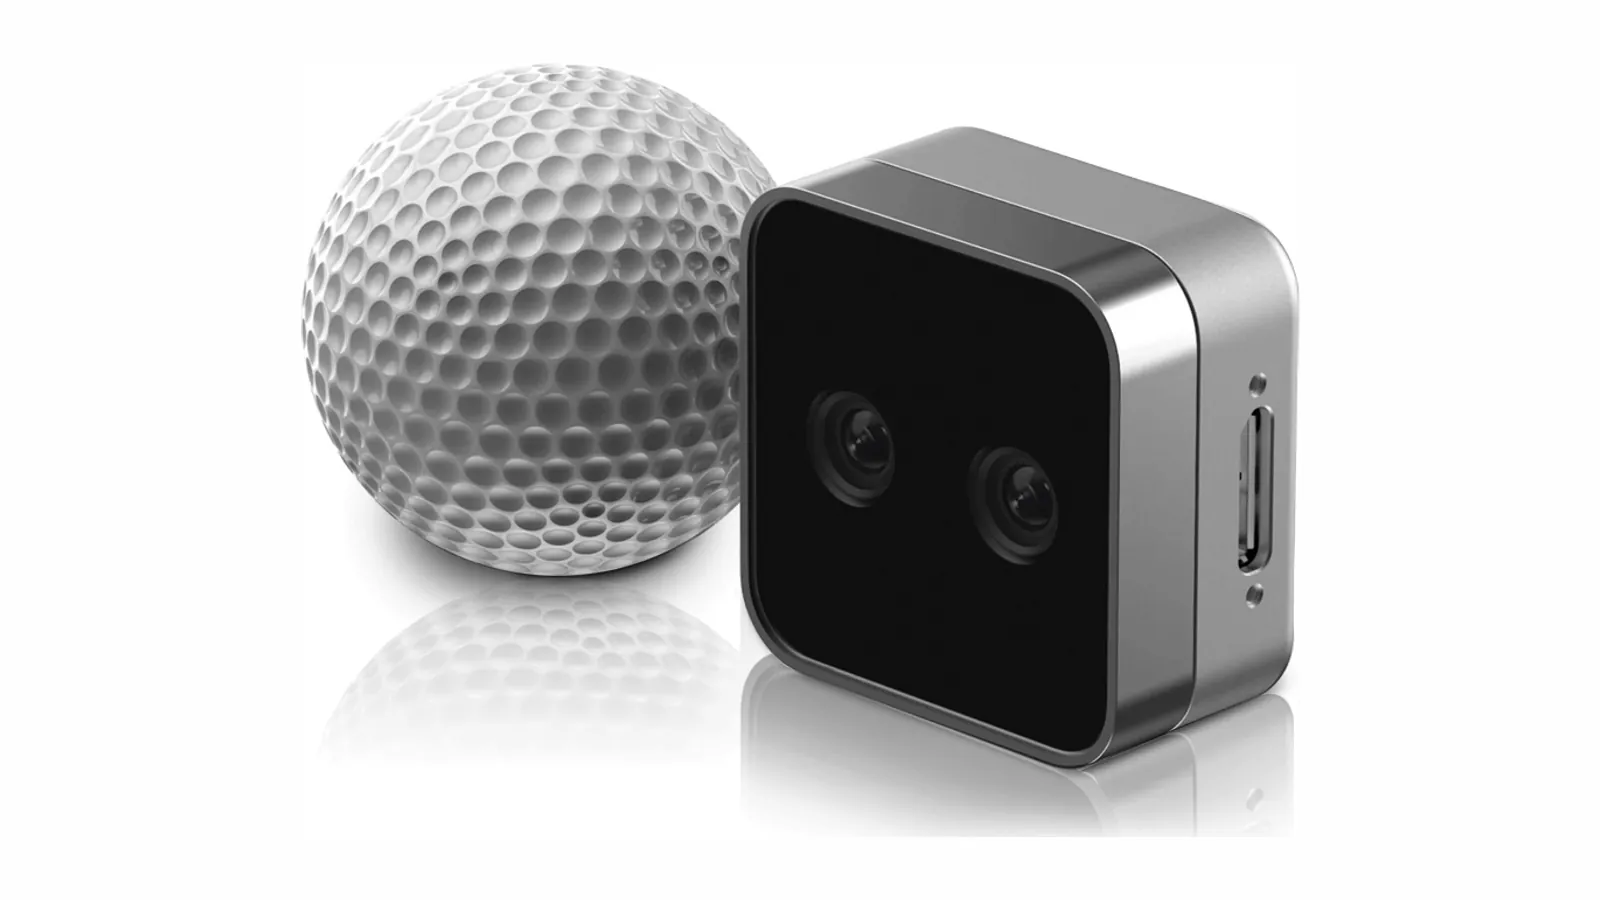
Robot Camera Setup for Data Collection: Wrist, Overhead, and Stereo
Complete robot camera setup guide for data collection: wrist vs overhead vs side placement, resolution, frame rate, synchronization, depth cameras, calibration, and RCSV's multi-camera standard.
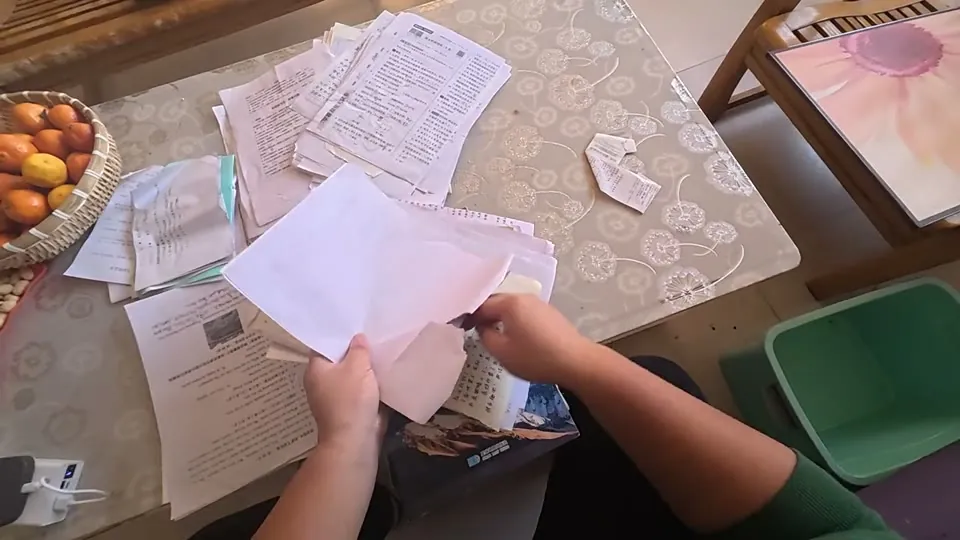
Robot Data Annotation: How to Label Robot Demonstrations for Training
How to annotate robot demonstration data for training: success flags, language labels, task segmentation, quality standards, tools, and RCSV's annotation pipeline.
How Much Does Robot Data Collection Cost in 2026?
A detailed breakdown of robot data collection costs in 2026 — hardware, operators, post-processing, DIY vs outsourced, RCSV pricing, and ROI framing for training data budgets.
Robot Deployment Checklist: 12 Steps Before Going Live
A 12-step robot deployment checklist covering safety, environment prep, policy validation, operator training, monitoring setup, and how RCSV supports production robot deployments.
Robot Policy Generalization: Why It's Hard and What Works in 2026
Why robot policies fail to generalize: types of distribution shift, solutions from data augmentation to foundation models, what actually generalizes in 2026, and how to measure it.
Building a Robotics Startup in 2026: What You Actually Need
How to build a robotics startup in 2026: hardware-first vs software-first, when to lease vs buy, data collection strategy, talent, funding landscape, common mistakes, and RCSV's startup program.
What Is Robot Training Data? Types, Collection Methods, and Quality Standards
Robot training data explained: demonstration, interaction, synthetic and video data, six quality checks, collection methods, and demos needed per task.
Sim-to-Real Transfer Explained: The Reality Gap, Domain Adaptation, and the Path Forward
A deep dive into sim-to-real transfer for robotics: the reality gap, simulation fidelity levels, domain adaptation methods, history of breakthroughs, and where the field is heading in 2026.
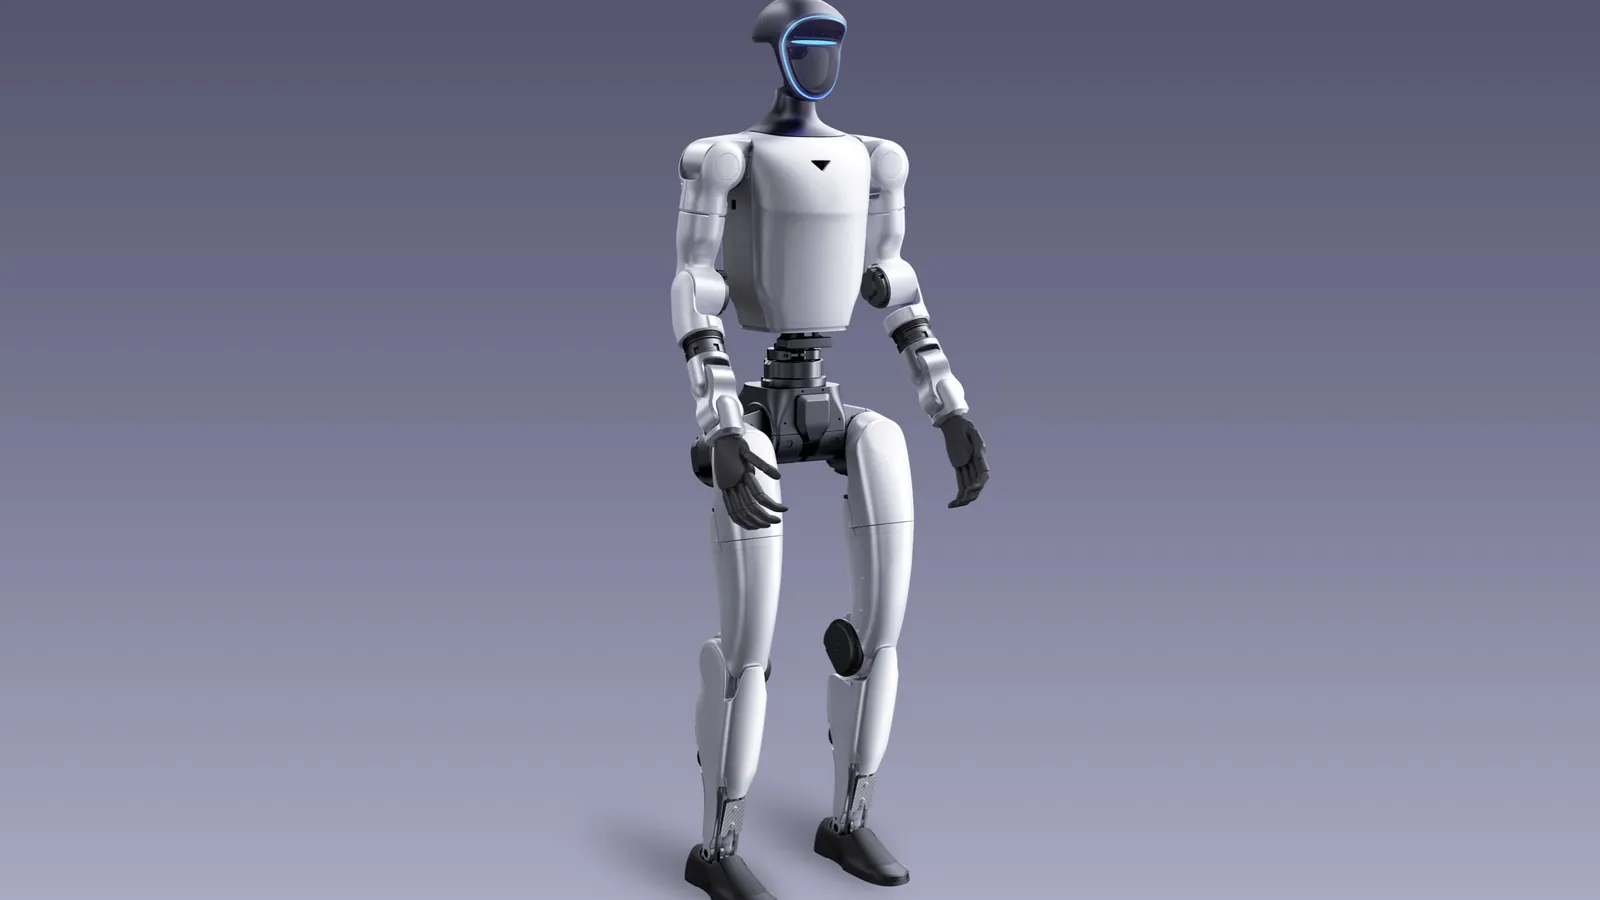
Unitree G1 Review 2026: Is It Worth It for Research?
Full Unitree G1 review for 2026: specs deep dive, locomotion performance, manipulation limitations, software ecosystem, and who it's for.
Vision-Language-Action Models Explained: How VLAs Power Modern Robots
What a vision-language-action (VLA) model is, how RT-2, OpenVLA, Octo and pi0 compare on size, latency and access, and how many demos fine-tuning needs.
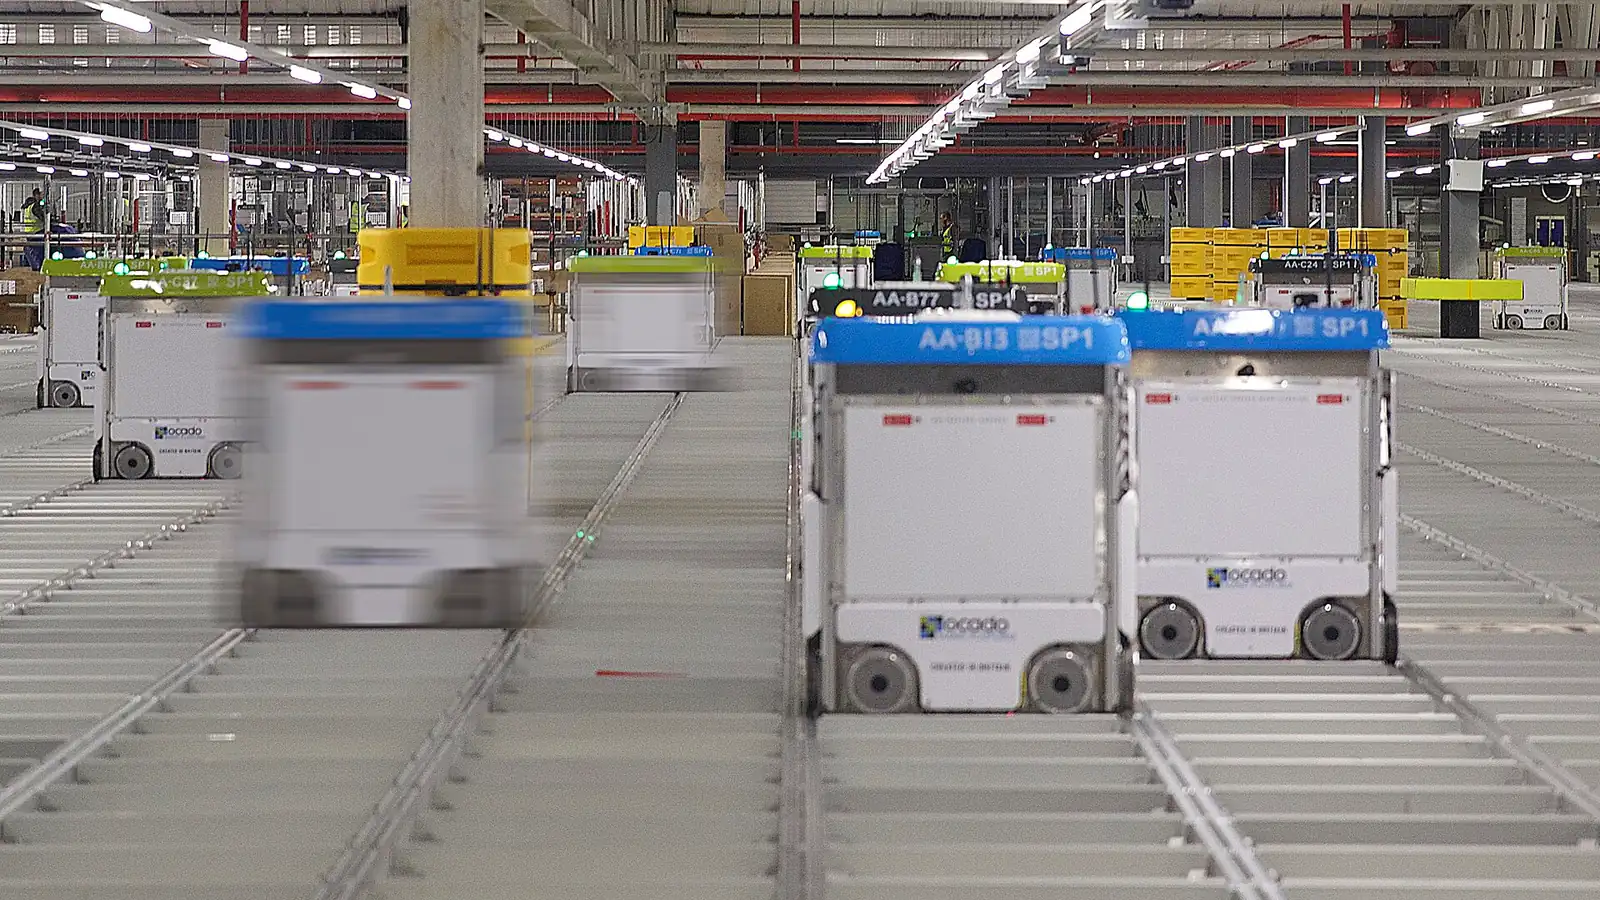
Warehouse Robot ROI: How to Calculate and What to Expect
Warehouse robot ROI framework: labor savings + throughput gain + error reduction - TCO, realistic payback periods by robot type, common calculation mistakes, real cost-per-pick numbers, and pilot structuring.
The Teleoperation Data Quality Checklist Every Lab Needs
Calibration, latency budget, action smoothing, failure recovery labeling, episode boundaries, interface choice — a practitioner checklist for high-quality teleop data.
Humanoid Robot Supply Chain in 2026: A Buyer's Reality Check
Lead times, sanctions and tariffs, repair networks, battery cycle reality, spare parts, and US vs China supply — what humanoid buyers actually face in 2026.
The Best Open-Source Robotics Stack for Research Labs (2026 Edition)
LeRobot, Robosuite, Isaac Lab, OpenVLA, Octo, ROS 2, DROID-style data, GelSight tactile — the 2026 open-source stack vs the closed NVIDIA Isaac alternative.