Best Dexterous Robot Hands in 2026: Buyer's Guide by Use Case and Budget
Which dexterous robot hand to buy in 2026, sorted by use case and budget: Wuji Hand 2, LinkerBot, AGIBOT OmniHand, BrainCo Revo 2, Inspire, Unitree, Allegro, PaXini, Sharpa and LEAP Hand, with live prices and stock.
Part of: Robot Arms Guide
This is a buying guide for dexterous robot hands that you can order right now. It is organized by what you want the hand to do and how much you want to spend, and every price you see comes from our live store, so it is current when you read it. For a broader look at the hand designs that shaped the field, see our earlier article, Best Dexterous Robot Hands for Research and Manipulation.
Disclosure: Robotics Center sells most of the hands in this guide, and one product mentioned near the end, the RC G1 Tactile Glove$3,625.00, is our own. Hands are listed in order of their current list price, from lowest to highest, not by how much we earn on them. Each product chip shows the live price, a stock indicator and a link to the product page. Hands we do not sell, such as the Shadow Dexterous Hand, link to the maker's own page.
Key takeaways
- For a first dexterous hand, or for fitting hands to many robots, the LinkerBot O6$2,000.00, the LEAP Hand v1 kit$2,066.00 and the AGIBOT OmniHand 2025From $4,999.00 keep the cost per hand low.
- For humanoids and mobile manipulators, where weight matters most, the BrainCo Revo 2From $5,900.00, the Inspire RH56DFX$10,500.00 and Unitree's Dex3-1$6,000.00 and Dex5-1$25,000.00 are designed to mount on a robot's wrist.
- For high-DoF teleoperation and in-hand manipulation research, look at the Wuji Hand 2From $14,600.00 (20 active DoF), the Linker Hand L20$9,999.00 and Linker Hand L30$19,999.00, and the Allegro Hand V5 Sense$13,000.00.
- For dense tactile sensing, the PaXini DexH13$14,377.00 and the Sharpa Wave$55,000.00 put tactile sensing at the center of the design.
2026 dexterous hands at a glance
Specs are the maker's published figures (see Sources). A dash means the maker's page we cite does not state that figure. The price column is read from our store every time the page renders.
| Hand | Fingers and active DoF | Weight | Interface | Our price |
|---|---|---|---|---|
| LinkerBot O6 | 5 fingers; 6 active + 5 passive1 | 360 g | CAN / CAN FD, RS485, EtherCAT | $2,000.00 |
| LEAP Hand v1 (kit) | 4 fingers, open-source design2 | — | — | $2,066.00 |
| AGIBOT OmniHand 2025 | 5 fingers; 10 active, 16 total3 | ≤500 g | CAN FD / RS485, 1 kHz | From $4,999.00 |
| BrainCo Revo 2 | 5 fingers4 | 383 g | — | From $5,900.00 |
| Unitree Dex3-1 | 3 fingers; 7 DoF5 | 710 g | USB 2.0 | $6,000.00 |
| Linker Hand L20 | 5 fingers; 16 active + 5 passive6 | ≈1,200 g | CAN / RS485 | $9,999.00 |
| Inspire RH56DFX | 5 fingers; 6 DoF, 12 joints7 | 540 g | RS485 | $10,500.00 |
| Allegro Hand V5 Sense | 16 pressure-sensing channels8 | — | CAN and UDP protocols | $13,000.00 |
| PaXini DexH13 | 4 fingers; 13 active, 16 total9 | — | — | $14,377.00 |
| Wuji Hand 2 | 5 fingers; 20 active10 | 800 g with soft tissue and cables | Ethernet 100BASE-TX, 1 kHz | From $14,600.00 |
| Linker Hand L30 | 5 fingers; 17 active + 4 passive, tendon-driven11 | ≈1,200 g | CAN FD, 900 Hz | $19,999.00 |
| Unitree Dex5-1 | 5 fingers; 16 active + 412 | 1,100 g | USB 2.0, 1 kHz | $25,000.00 |
| Sharpa Wave | 5 fingers; 22 active, human 1:1 scale13 | 1.3 kg | — | $55,000.00 |
| Shadow Dexterous Hand (not sold by us) | 5 fingers; 20 actuated + 4 under-actuated14 | 4.3 kg | EtherCAT, 1 kHz | Contact Shadow Robot |
Pick by use case
Starting out, or fitting hands to many robots
If you are buying your first dexterous hand, or need one for every station in a teaching lab, the cost per hand and how easy the hand is to repair matter more than peak dexterity.
- LinkerBot O6$2,000.00 is a compact five-finger hand. LinkerBot lists six active and five passive DoF, a weight of 360 g, a 70 N five-finger grip and a 50 kg maximum load, with CAN, CAN FD, RS485 and EtherCAT interface options.1 It suits grasping and pick-and-place research where a light, simple hand is enough.
- LEAP Hand v1$2,066.00 comes from Carnegie Mellon University. It is an anthropomorphic, open-source hand designed for robot learning, and its authors describe it as buildable from readily available parts in about four hours.2 It suits groups that want to modify the hardware and match a widely published research platform. The LEAP Hand v2$4,550.00 follow-up uses a hybrid rigid-soft finger design driven by eight motors.15
- AGIBOT OmniHand 2025From $4,999.00 has ten active and 16 total DoF in a hand of 500 g or less. It communicates at 1 kHz over CAN FD or RS485, and a tactile version adds more than 400 tactile points.3 It suits teams that want five fingers and a high joint count at an entry-level price.
Humanoids and mobile manipulators
On a humanoid's wrist, every gram costs payload and battery life, and the hand has to work with the robot's own SDK.
- BrainCo Revo 2From $5,900.00 weighs 383 g, measures 16 × 7.6 cm, and is rated by BrainCo for 50 N of grip force and a 20 kg payload.4 It suits humanoids where weight is the tightest constraint.
- Inspire RH56DFX$10,500.00 has six DoF across 12 joints and weighs 540 g. It has built-in position and force sensing with 0.50 N force resolution, ±0.20 mm repeatability, an RS485 interface and a DC 12–48 V supply.7 It suits teams that want simple, repeatable force-controlled grasping.
- Unitree Dex3-1$6,000.00 is a three-finger hand with seven DoF, 33 tactile sensors and a USB 2.0 interface. It weighs 710 g.5 The Unitree Dex5-1$25,000.00 has five fingers, 16 active DoF plus four more joints, 94 pressure sensors per hand and 1 kHz communication.12 Both suit Unitree humanoids, where they plug into the same software stack as the robot.
High-DoF teleoperation and in-hand manipulation
When you are recording human demonstrations through a glove, or studying in-hand re-orientation, the robot hand should have about as many controllable joints as the motion you capture.
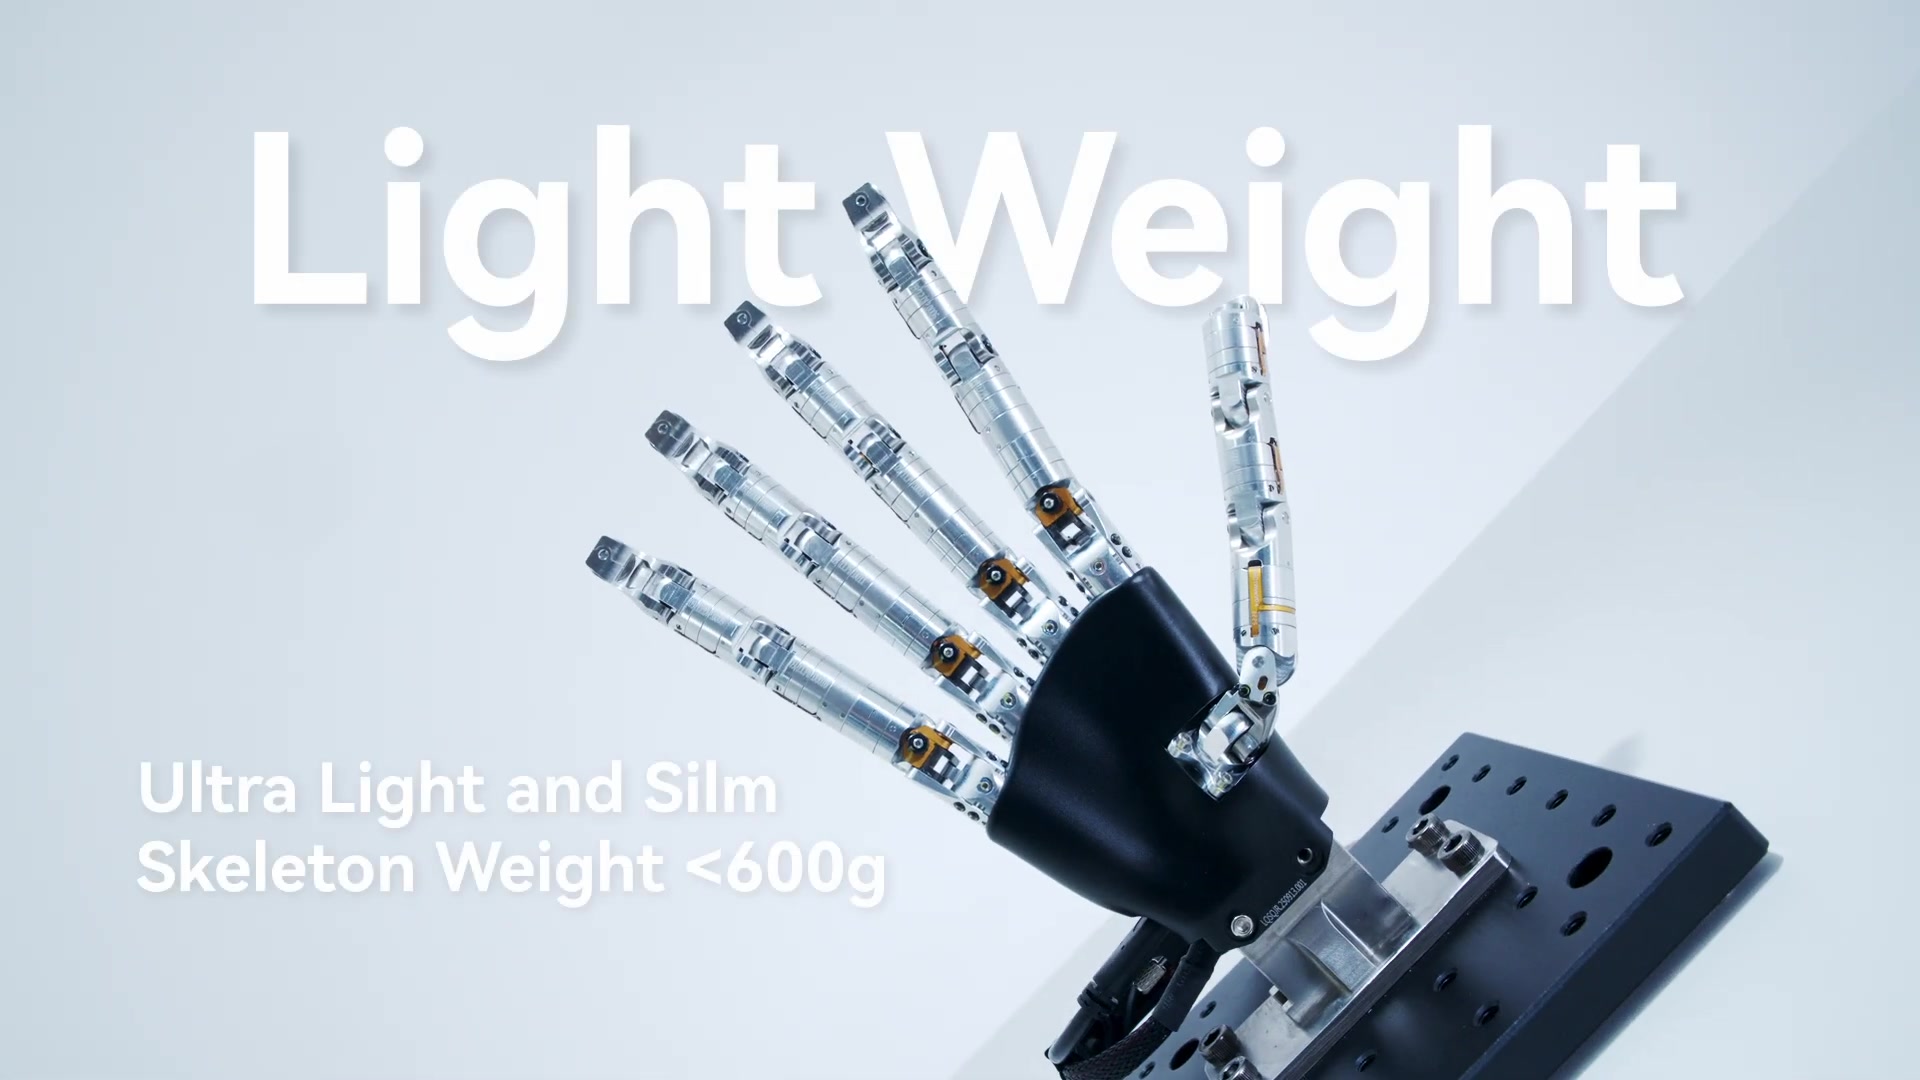
- Wuji Hand 2From $14,600.00 has 20 active DoF, four per finger. Each joint uses a backdrivable rotary direct drive with FOC control. All 20 axes are controlled at 1000 Hz over 100BASE-TX Ethernet, and the hand weighs 800 g including soft tissue and cables.10 It suits teleoperation and learning research that needs one-to-one finger mapping. Our Wuji Hand teleoperation guide covers setup.
- Linker Hand L20$9,999.00 uses a linkage drive with 16 active and five passive DoF. LinkerBot lists a 100 N five-finger grip and a 20 kg maximum load.6 Linker Hand L30$19,999.00 is tendon-driven, with 17 active and four passive DoF and 900 Hz CAN FD communication.11 The L20 suits strong, repeatable grasps. The L30 suits work where fast, human-like finger motion matters.
- Allegro Hand V5 Sense$13,000.00 is part of Wonik Robotics' Allegro family, the hand that the LEAP Hand authors use as their main point of comparison.2 The V5 Sense adds 16 pressure-sensing channels, and Wonik publishes CAN and UDP protocol documents for it.8 It suits labs that want to build on the large body of published Allegro work.
Tactile-rich manipulation
- PaXini DexH13$14,377.00 is a four-finger hand with 13 active DoF (16 total), 1,140 multi-dimensional tactile sensing units and an 8-megapixel hand-eye camera. PaXini rates it for a 5 kg load.9 It suits research that combines vision and touch in one end effector.
- Sharpa Wave$55,000.00 is a human-scale (1:1) hand with 22 active DoF and fingertip tactile sensing. Sharpa lists its weight as 1.3 kg.13 It suits teams that want human-scale proportions and high joint count together.
A reference we do not sell: the Shadow Dexterous Hand
The Shadow Dexterous Hand has 20 actuated DoF plus four under-actuated movements (24 joints in total) and is tendon-driven by 20 DC motors. It carries more than 100 sensors, runs a 1 kHz control loop over EtherCAT with ROS integration, and weighs 4.3 kg.14 Shadow Robot sells it directly and provides pricing on request.
Capturing demonstrations for your hand
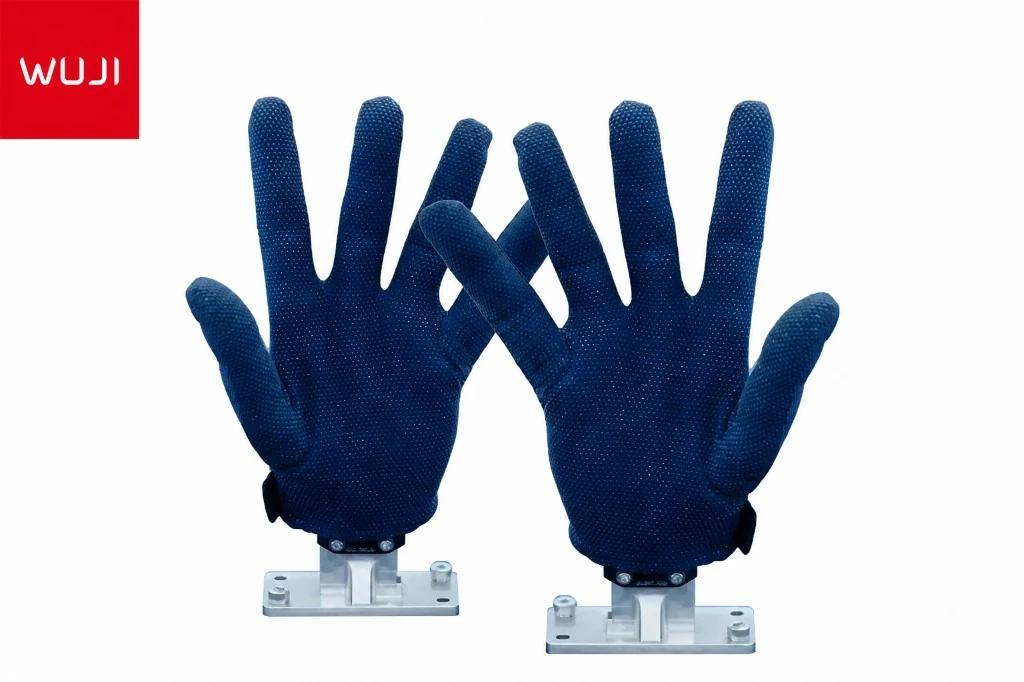
A dexterous hand is only as useful as the demonstrations you can record for it. One option is the RC G1 Tactile Glove. This is our own product, sold by Robotics Center. The glove records finger flexion and pressure across the fingers and palm. It works alongside any of the hands above, and the full specifications are on its product page. Pair it with whichever hand fits your task, not the other way around.
How to choose
- If cost per hand matters most, start with the LinkerBot O6, the LEAP Hand v1 kit or the AGIBOT OmniHand 2025.
- If low weight on a humanoid matters most, choose the BrainCo Revo 2 or the Inspire RH56DFX. On a Unitree robot, choose the Dex3-1 or Dex5-1.
- If you need one-to-one teleoperation of all finger joints, choose the Wuji Hand 2, or the Linker Hand L20 or L30.
- If you want continuity with published research, choose the Allegro Hand or the LEAP Hand.
- If touch sensing is the research question, choose the PaXini DexH13 or the Sharpa Wave.
Stock changes week to week. The stock indicator on each product chip reads our live inventory. If a hand shows a lead time, contact us and we will confirm the current date.
Sources
- LinkerBot, "Linker Hand O6" product page. https://www.linkerbot.cn/details/LinkerHandO6 (accessed November 2026) ↩
- Shaw, Agarwal and Pathak, "LEAP Hand: Low-Cost, Efficient, and Anthropomorphic Hand for Robot Learning", arXiv:2309.06440 (2023). https://arxiv.org/abs/2309.06440 (accessed November 2026) ↩
- AGIBOT, "OmniHand 2025" product page. https://www.agibot.com/products/OmniHand_O10 (accessed November 2026) ↩
- TechNode Global, "BrainCo Launches Revo2 Hand for Humanoid Robotics" (September 16, 2025). https://technode.global/?p=107988 (accessed November 2026) ↩
- Unitree, "Dex3-1" product page. https://www.unitree.com/Dex3-1 (accessed November 2026) ↩
- LinkerBot, "Linker Hand L20" product page. https://www.linkerbot.cn/details/LinkerHandL20 (accessed November 2026) ↩
- Inspire Robots, "RH56DFX" product page. https://en.inspire-robots.com/product/rh56dfx (accessed November 2026) ↩
- Wonik Robotics, "Allegro Hand V5 Sense" tech info. https://www.allegrohand.com/sub/tech/t.php?idx=23 (accessed November 2026) ↩
- PaXini, "DexH13" product page. https://paxini.com/cn/dex/gen2 (accessed November 2026) ↩
- Wuji Technology, "Wuji Hand 2 overview" (documentation). https://docs.wuji.tech/docs/zh/wuji-hand/latest/overview (accessed November 2026) ↩
- LinkerBot, "Linker Hand L30 Pro" product page. https://www.linkerbot.cn/details/LinkerHandL30 (accessed November 2026) ↩
- Unitree, "Dex5-1" product page. https://www.unitree.com/Dex5-1 (accessed November 2026) ↩
- Sharpa, "SharpaWave" product page. https://www.sharpa.com/pages/wave (accessed November 2026) ↩
- Shadow Robot, "Dexterous Hand Series". https://www.shadowrobot.com/dexterous-hand-series/ (accessed November 2026) ↩
- LEAP Hand v2 project page (Carnegie Mellon University). https://v2.leaphand.com/ (accessed November 2026) ↩