Wuji Hand & Wuji Glove: The Complete Teleoperation Guide (2026)
Everything you need to know about the Wuji dexterous hand and Wuji teleoperation glove — specs, pricing, how teleoperation works, imitation learning workflows, and where to demo the system in person.
What is the Wuji Hand?
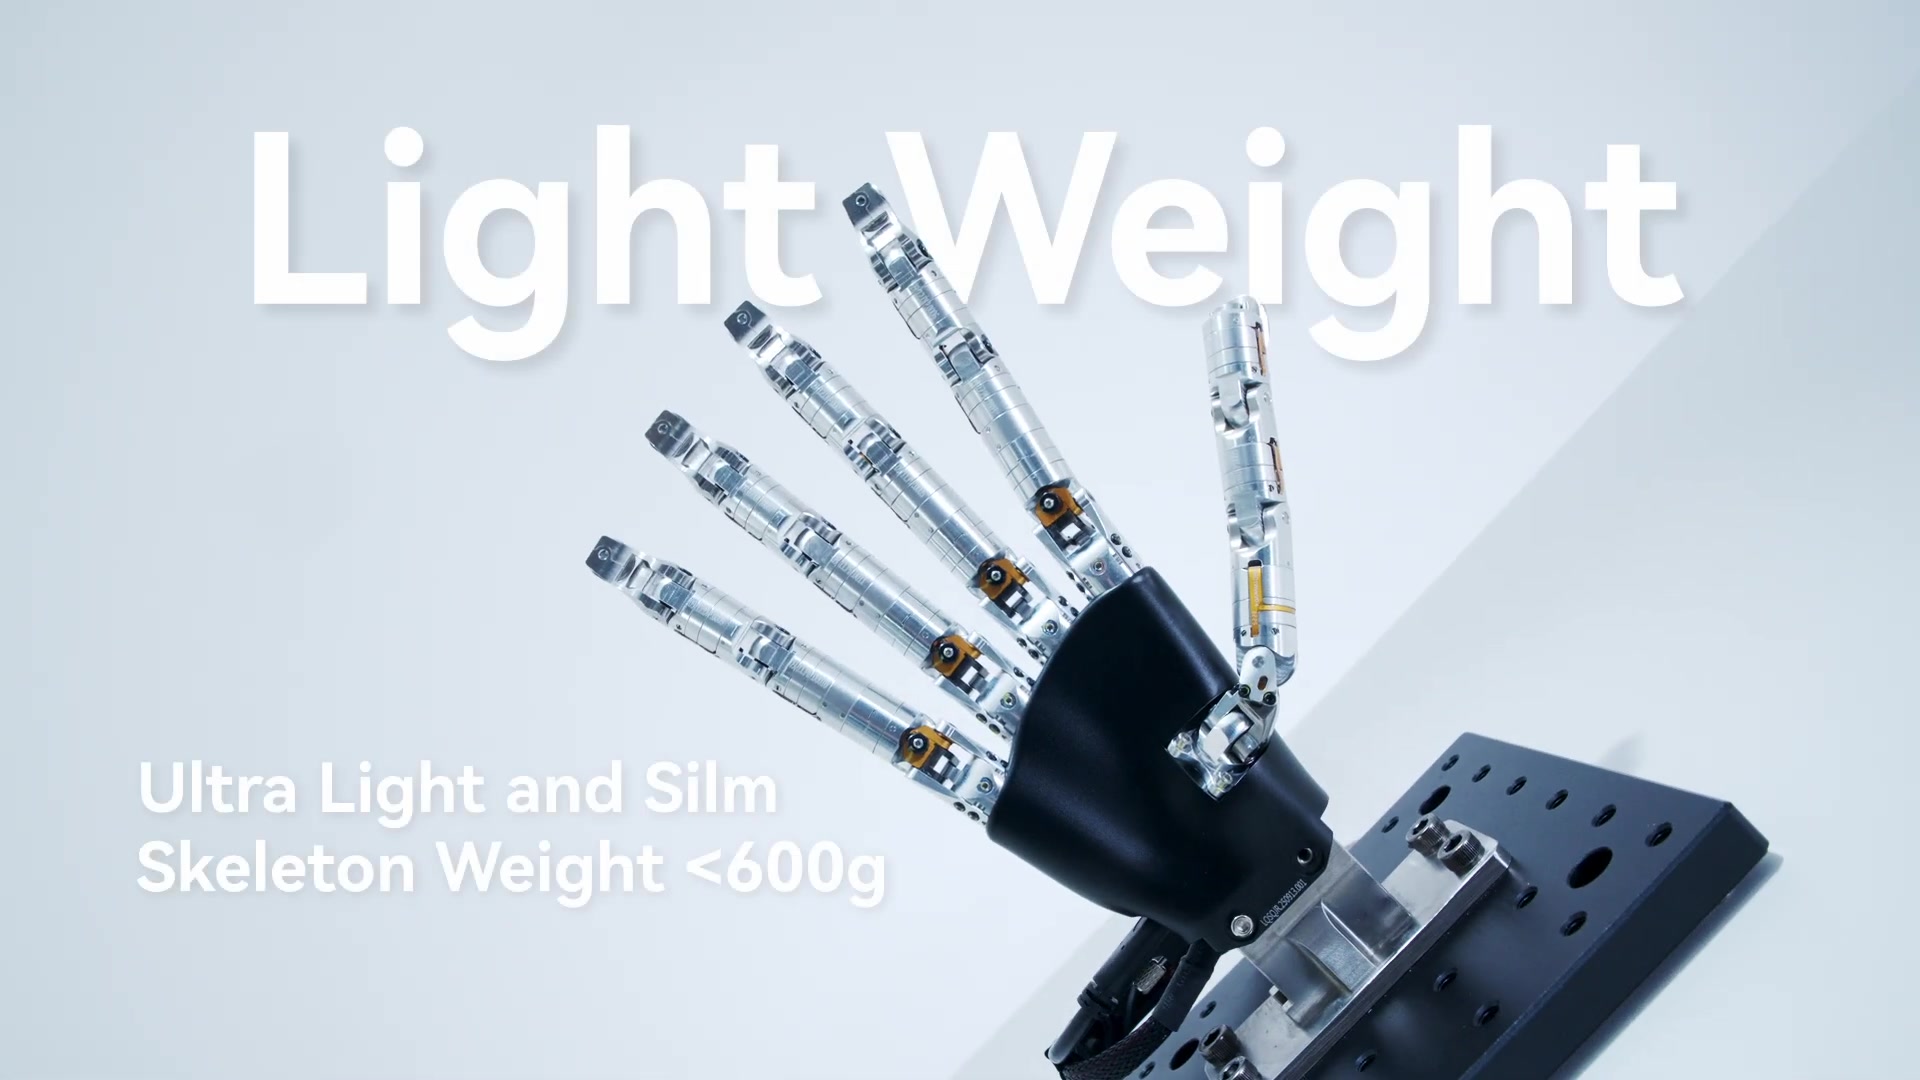
The Wuji Hand (sometimes written "WUJI hand" or "wuji dexterous hand") is a high-DOF direct-drive robotic hand made by Wuji Robotics. It launched in 2025 and has quickly become one of the most talked-about dexterous hands in the embodied AI and manipulation research community.
What makes the Wuji Hand notable:
- 20 degrees of freedom — micro-actuators in each phalanx, not cable-driven
- 768-point tactile pressure map (24×32 resolution) streaming at 30 Hz
- 6-axis IMU per finger for orientation and inertia sensing
- JSONL data stream — plug into any data pipeline including LeRobot, MCAP, or custom collectors
- 580g weight — light enough for most robot arm end-effectors
- Shock-resistant — 300,000+ grasp cycle rating
We have the Wuji Hand on display at Robotics Center of Silicon Valley. It generates more crowd interest at our monthly meetups than almost any other hardware we have on the floor.
Wuji Hand Specs
| Spec | Value |
|---|---|
| DOF | 20 |
| Actuation | Direct-drive (micro-actuators per phalanx) |
| Tactile map | 768 taxels (24×32), 30 Hz streaming |
| IMU | 6-axis per finger |
| Data protocol | JSONL stream (wujihandpy SDK) |
| Weight | ~580 g |
| Fingertip force | 15 N |
| Durability | 300,000+ grasp cycles |
| Compatible arms | OpenArm 1, UR5e, Kinova Gen3, and others |
| Current price | From $14,600.00 |
What is the Wuji Glove?
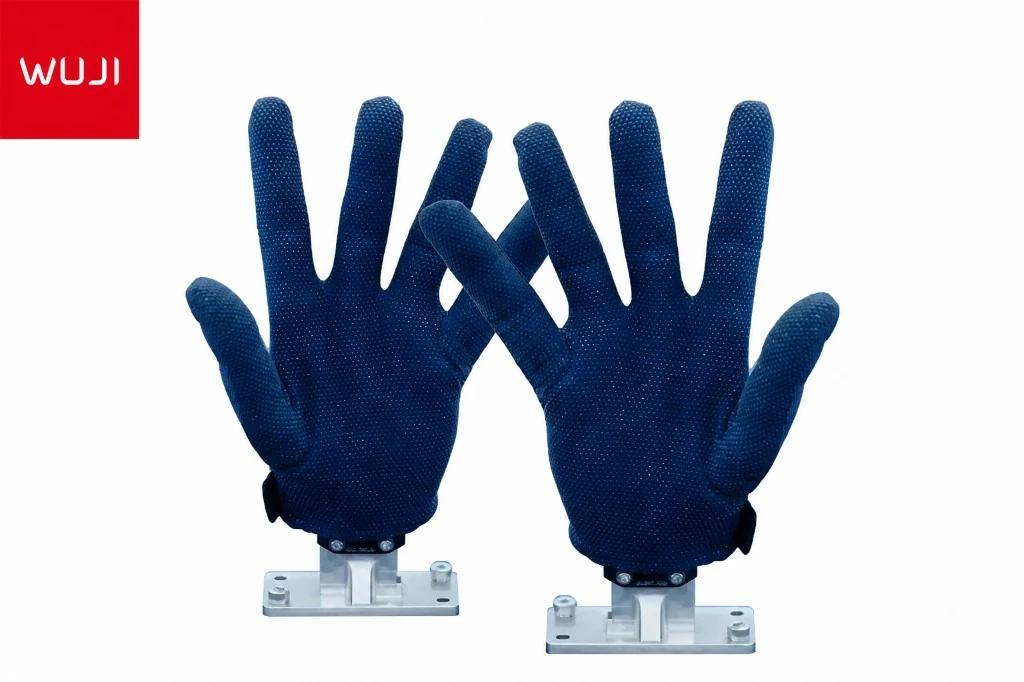
The Wuji Glove is a tactile and pose-tracking teleoperation glove—and the control interface for Wuji Hand 2. It tracks per-finger movement in real time, letting a human operator control the Wuji dexterous hand with natural hand motions.

The Wuji Glove matters because most teleoperation systems use joysticks or SpaceMouse controllers that can't capture the full dexterity of a human hand. For training data that covers in-hand manipulation, the glove is the right tool.
| Spec | Value |
|---|---|
| Tracking | Per-finger joint angles (5 fingers) |
| Latency | <10 ms end-to-end |
| Compatible with | Wuji Hand (primary), other dexterous platforms via SDK |
| Current price | $4,500.00 per pair (L + R) · $500 shipping from San Francisco |
How Wuji Teleoperation Works
Wuji teleoperation is a closed-loop system: the operator wears the Wuji Glove, which sends per-finger joint angles over a low-latency link to the Wuji Hand, which mirrors those motions in real time.
- Operator puts on the Wuji Glove — sensors calibrate to hand size in seconds.
- Glove streams joint angles at <10ms latency to the Wuji Hand controller.
- Wuji Hand mirrors motions in real time — grasp, pinch, rotate, all captured faithfully.
- Tactile feedback data streams back — 768-point pressure map shows what the hand is touching.
- Fearless Platform records the episode — joint positions, tactile data, camera streams, all timestamped and synced.
The result: a complete demonstration episode suitable for training ACT, Diffusion Policy, or VLA models on dexterous manipulation tasks.
Wuji for Imitation Learning Data Collection
The Wuji Hand + Glove combination is one of the best setups available for collecting imitation learning data on dexterous tasks. Here's why researchers choose it:
- 20 DOF captures full hand morphology — not just open/close, but independent finger control
- 768-point tactile map — models can learn contact-aware grasping from the pressure data
- JSONL streaming — drop into any data pipeline; compatible with LeRobot V2 format at RCSV
- <10ms glove latency — operator motions translate faithfully, no lag-induced artifacts in the training data
- On-site collection at RCSV — book time at our San Francisco lab with the full teleoperation rig already set up
Wuji Hand & Glove Pricing
See the product page for current configurations and availability.
View Wuji Hand 2$500 shipping from San Francisco; in-stock glove orders dispatch in approximately 48 hours.
View Wuji GloveBundle pricing is available. Contact us for Wuji Hand + Glove combinations, shipping estimates, and integration support.
Wuji Hand vs Shadow Hand, Allegro, and Inspire
How does the Wuji Hand compare to other dexterous hands used in research?
| Hand | DOF | Tactile | Teleop Glove | Price |
|---|---|---|---|---|
| Wuji Hand | 20 | 768-pt | ✓ $4,500.00 | From $14,600.00 |
| Shadow Hand | 24 | Optional | Separate | ~$80,000+ |
| Allegro Hand | 16 | No | No native | ~$15,000 |
| Inspire Hand | 12 | No | No native | ~$8,000 |
The Wuji Hand hits a unique spot: more affordable than the Shadow Hand, more DOF than Allegro, and the only option with a matching glove controller and 768-point tactile sensing in this price range.
Where to Demo & Buy the Wuji Hand and Wuji Glove
Both the Wuji Hand and Wuji Glove are on display at Robotics Center of Silicon Valley in San Francisco, CA. We're the authorized distributor for Wuji hardware in North America.
Options:
- Book a 30-min demo — try the full teleoperation system, collect a demo episode, talk through your use case
- Attend our monthly meetup — Wuji Hand is always on the demo floor at our Robots + Data events in SF
- Buy online — order the Wuji Hand or Wuji Glove from our store; in-stock Wuji Glove orders dispatch from San Francisco in approximately 48 hours
- Lease — we offer monthly leasing on Wuji hardware for short-term research projects
Book a Demo → Buy Wuji Hand 2 Buy Wuji Glove
More Wuji resources
- Wuji Hand hardware page — full specs, comparison, ROS2 setup →
- Wuji Glove hardware page — use cases, FAQ →
- Wuji Hand SDK guide — wujihandpy, JSONL stream, Fearless Platform →
- Explore Wuji Hand 2 and Wuji Glove at Robotics Center →
Continue the loop
Have the setup down? Close the loop on hardware, data, and scoring.
Browse hands & grippers → Done training? Score it → Need data at scale →