





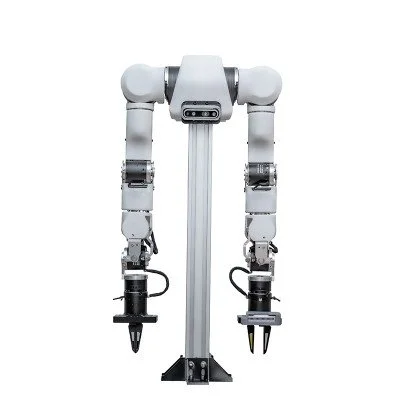
OpenArm 1
High-performance open-source arm for manipulation research, data collection, and imitation learning pipelines.
8 DOFSocketCANMIT controlROS2
View OpenArm 1 details
Browse arms, bimanual systems, dexterous hands, humanoids, sensors, and mobile bases — all with specs, setup guides, and AI compatibility details.
High-performance open-source arm for manipulation research, data collection, and imitation learning pipelines.
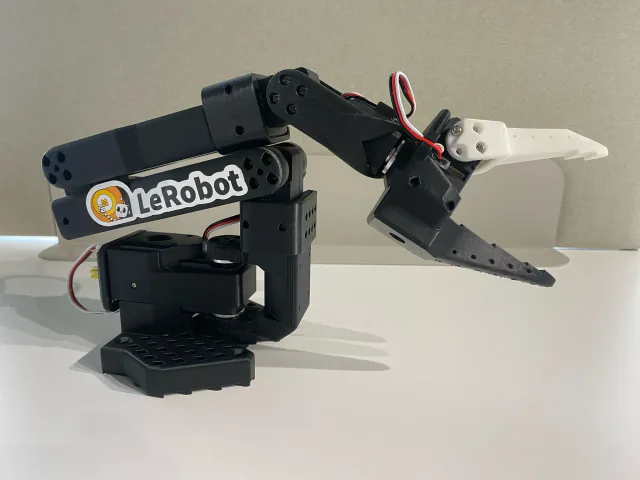
Low-cost open-source arm designed for rapid prototyping and LeRobot-native data collection workflows.
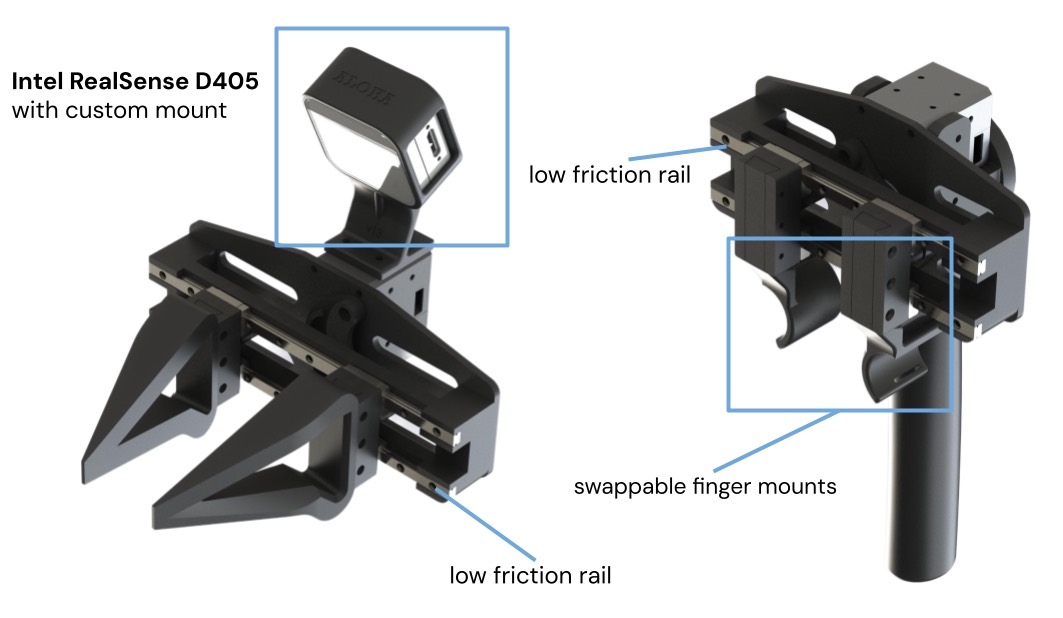
Dual-arm teleoperation kit built for ALOHA-style imitation learning with native LeRobot integration.
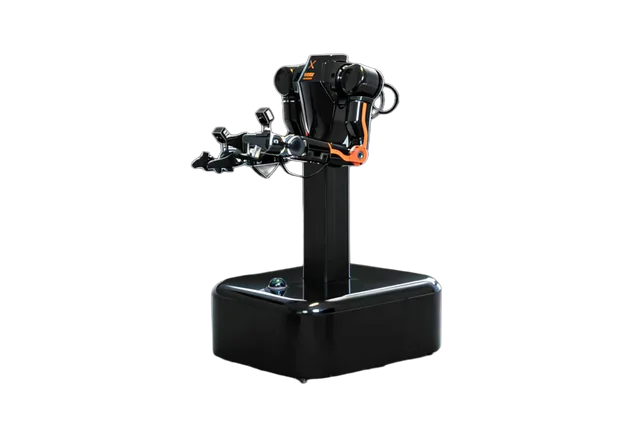
Dual-arm mobile manipulation platform with onboard compute for autonomous deployment and ROS2 nav.
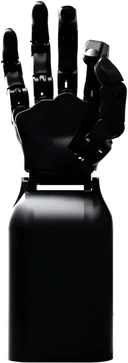
Open-source five-finger dexterous hand with full ROS2 support and a growing manipulation dataset.
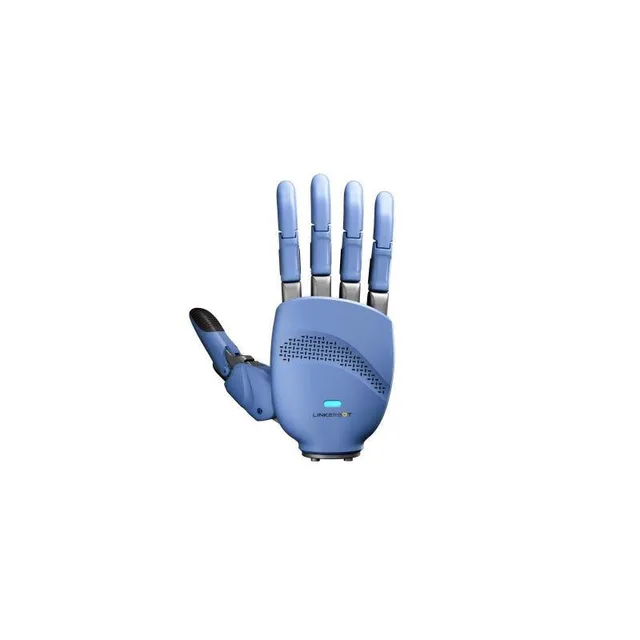
Five-finger hand with 16 distributed tactile sensing regions, optimized for contact-rich manipulation tasks.
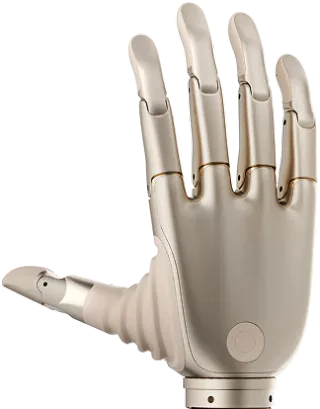
Bionic prosthetic-grade hand with EMG neural control interface, enabling natural teleoperation workflows.
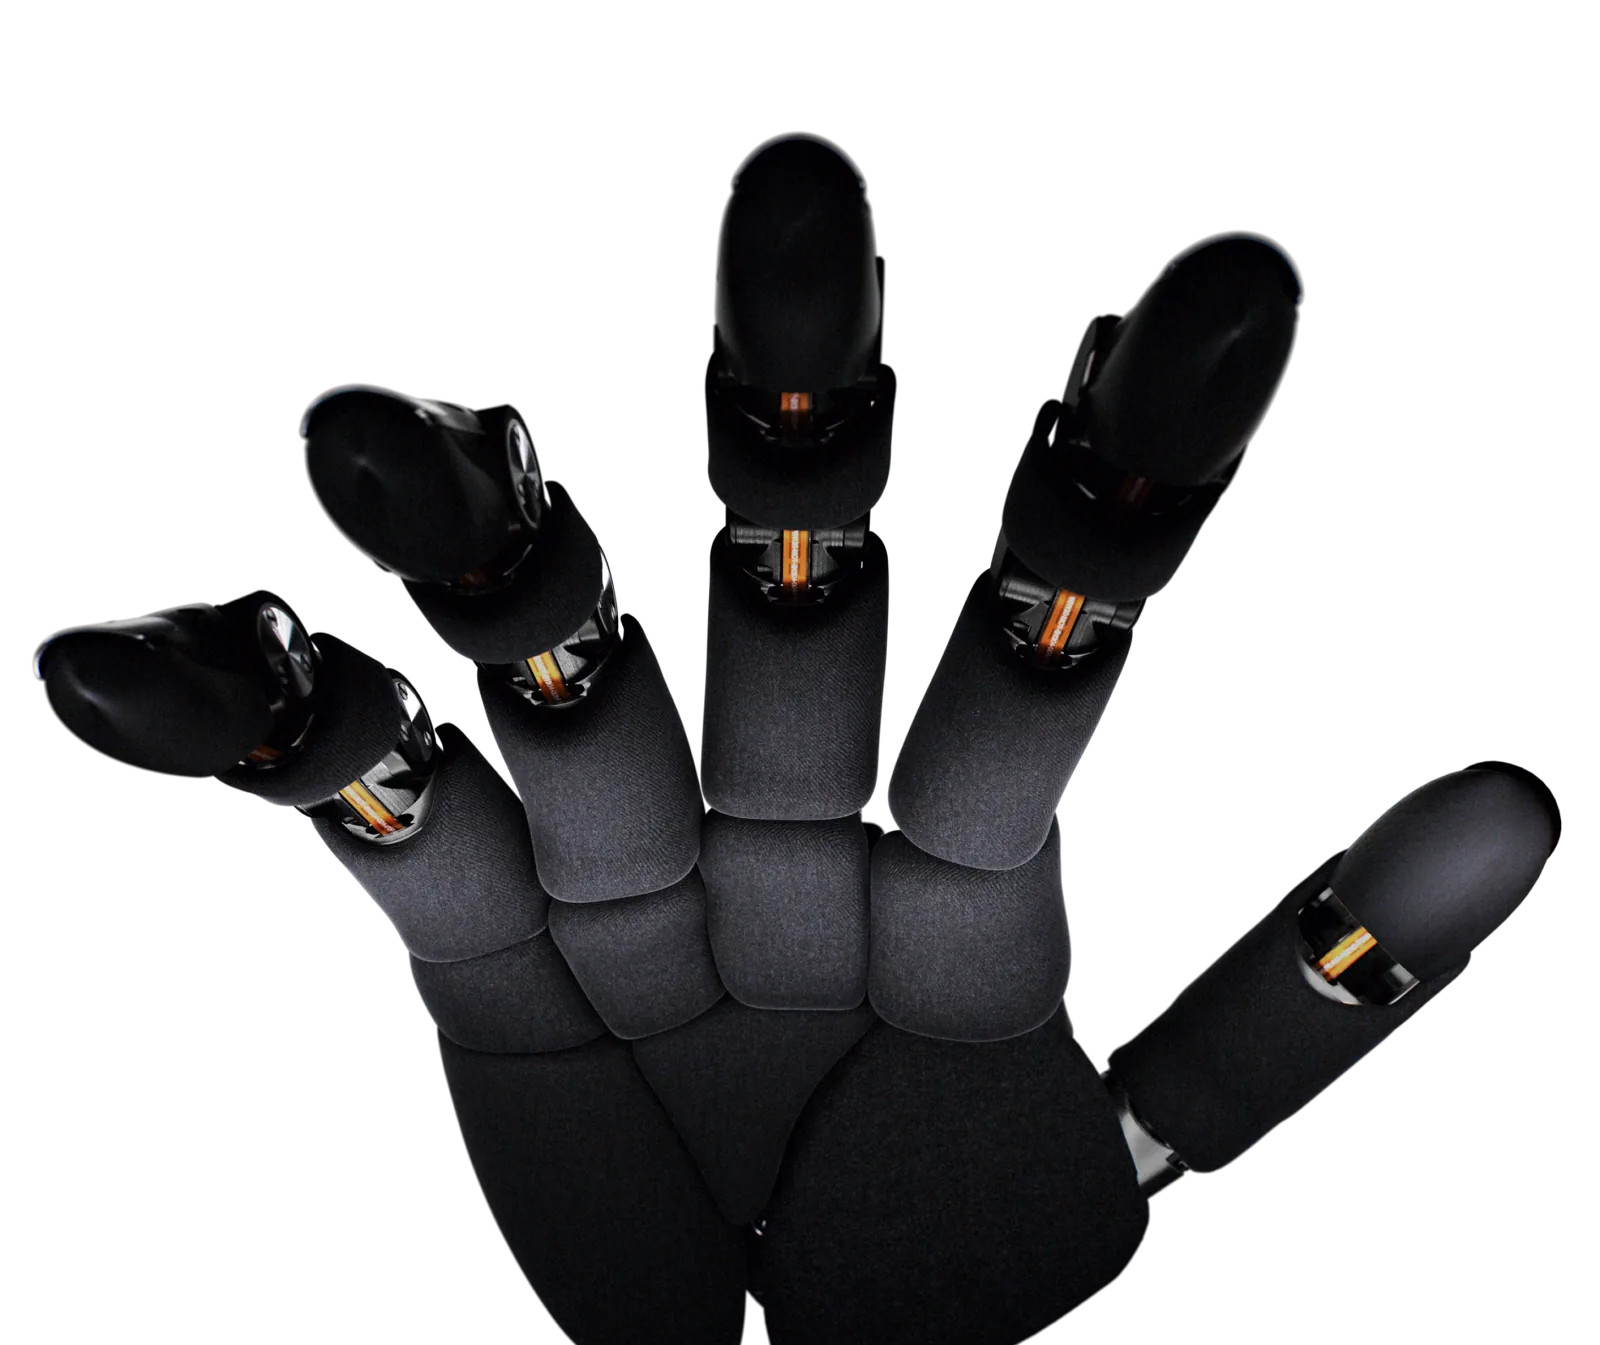
Teleoperation-first dexterous hand with per-joint streaming over JSONL for low-latency imitation learning.

Low-latency, per-finger tracking glove for Wuji Hand control, imitation-learning demonstrations, and dexterous teleoperation.
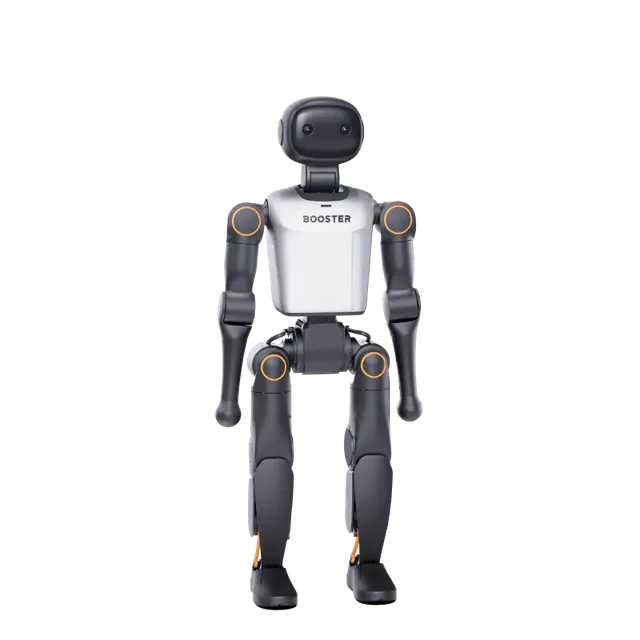
Full-size humanoid platform with 22 actuated joints and five onboard control modes for whole-body locomotion and manipulation research.
Six-axis tactile force-torque sensor available in 12 variants, purpose-built for contact-rich manipulation and assembly tasks.
Omnidirectional mobile base with mecanum wheel drive and ROS2 Nav2 integration for autonomous navigation in structured environments.
Compare specifications side by side, or talk to our team about the right platform for your research or deployment.