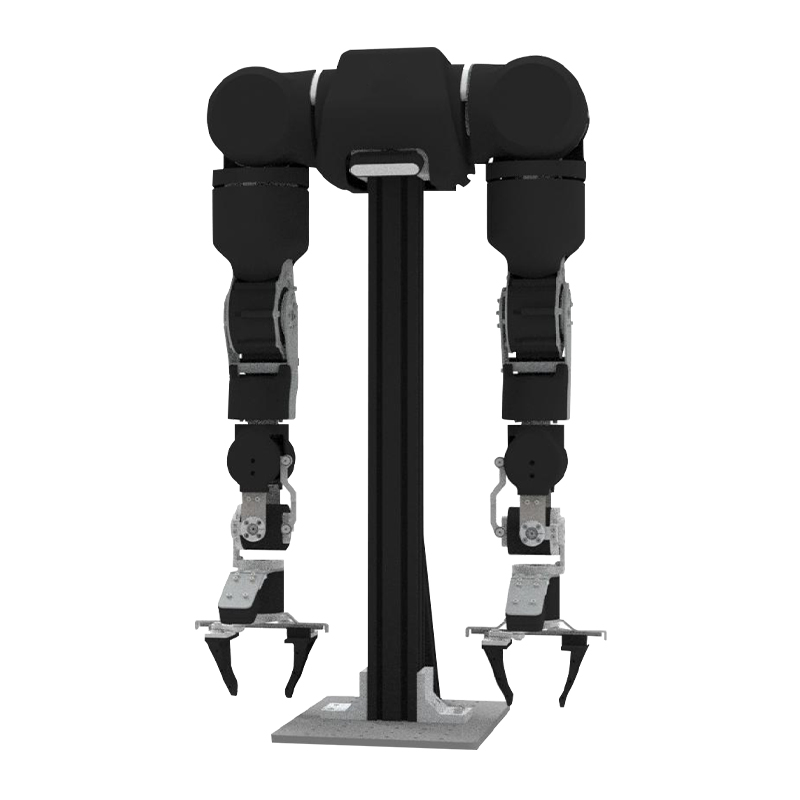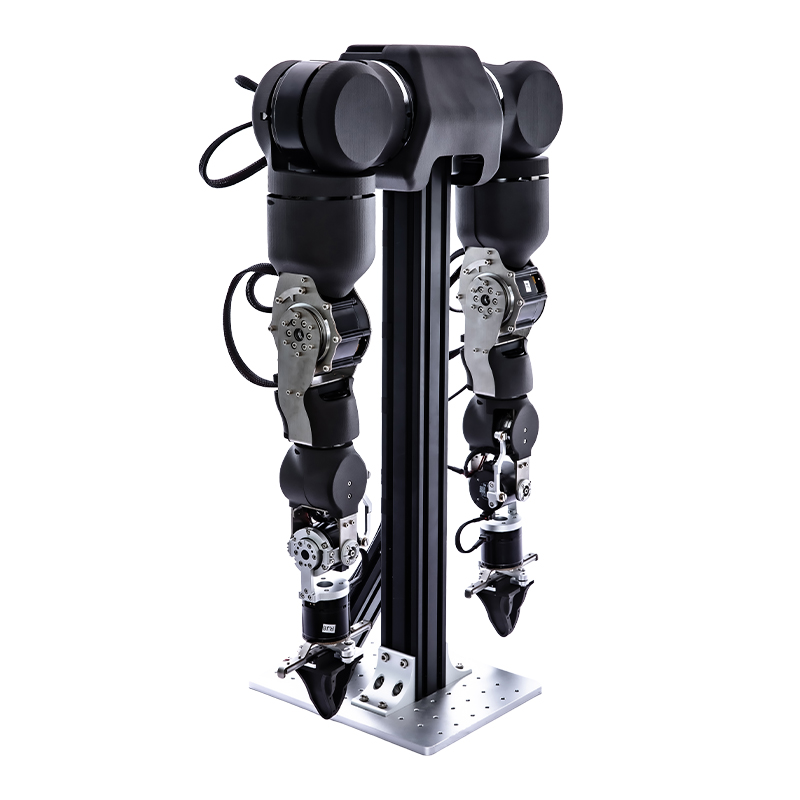
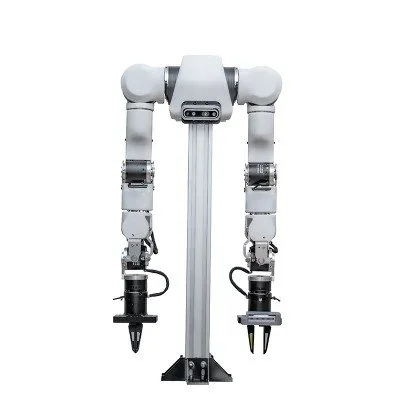
Foxtech Agility R7 7-DOF Force-Controlled Dual-Arm System
Contact for pricingBackorder
Configuration
- Shipping calculated at checkout
- In-house support
Key Specifications
approx. 15 kg
Weight (Per Arm)
901 × 128 × 128 mm
Single Arm Dimensions
standard on all joints
Joint Torque Sensors
7 kg
Rated Payload (Per Arm)
714 mm
Working Reach
7 rotational
DOF (Per Arm)
All Specifications
BrandFoxtech
CategoryRobotic Arm
AvailabilityBackorder
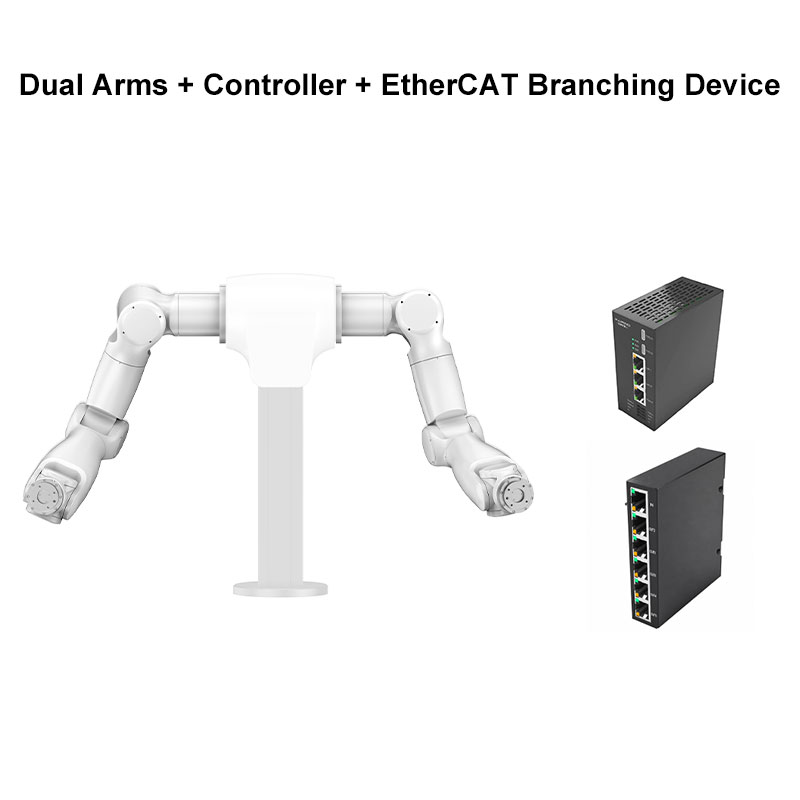
Configurationleft arm + right arm + controller + EtherCAT branching device
Joint RangeJ1 ±175°, J2 ±112°, J3 ±175°, J4 -87° to +112°, J5 ±175°, J6 ±72°, J7 ±90°
Brakeson all joints
Wrist Configurationcross-wrist
Noise Level< 65 dB
Mounting Orientationany
Operating Temperature0 °C to 45 °C
Operating Humidity90% RH, non-condensing
Storage Temperature-20 °C to 60 °C
Drag Teachingyes, with physical drag-teaching button
Weight (Per Arm)approx. 15 kg
Single Arm Dimensions901 × 128 × 128 mm
Hollow Cable PassageØ12 mm
End Mechanical InterfaceISO 9409-1-50-4-M6
Standard End Interfaces2 × RS485; 24 V, 6 A power output
Optional End Interfaces1 × EtherCAT, 1 × CAN
SoftwareUbuntu 22.04, ROS 2 Humble, ros2_control, MoveIt 2, C++ SDK
Controller ProcessorRockchip RK3588 (4 × Cortex-A76 + 4 × Cortex-A55, 2.4 GHz)
Controller Memory8 GB LPDDR4X, 32 GB eMMC
Controller Network2 × Gigabit Ethernet (incl. 1 × TSN) + 1 × EtherCAT; CAN and RS485 supported
Controller Dimensions40 × 80 × 100 mm
Controller Weight0.37 kg
Controller MountingDIN rail
Ether CAT Branching Device88 × 22 × 101 mm, DIN-rail mount, 6 × RJ45 (1 in, 5 out)
DOF (Per Arm)7 rotational
Rated Payload (Per Arm)7 kg
Working Reach714 mm
Repeatability±0.03 mm
Typical TCP Speed1.2 m/s
Joint Speed≥150°/s
Joint Torque Sensorsstandard on all joints
Power InputDC 48 V
Arm Power (Per Arm)1000 W
Base CommunicationEtherCAT via RJ45
Base User Power Output24 V, 6 A
Controller PowerDC 24 V, 2 A
Force Repeatability≤0.15 N, ≤0.05 N·m
Force Sensor Overload Capacity≥300% F.S.
Joint Force Control Accuracy≤1% F.S.
Force Sensor Sampling Rate≥5 kHz