







Back to People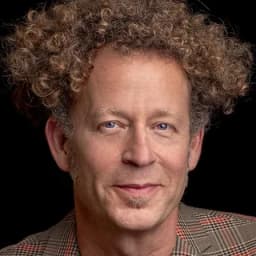
Ken Goldberg
UC Berkeley professor who leads the AUTOLAB, known for Dex-Net grasp planning and cloud robotics, and co-founder of Ambi Robotics.
UC Berkeley · United States
- Rank
- #69
- Score
- 47.7
- Citations
- 14,669
- h-index
- 61
- Robotics papers 2023–2025
- 13
Source: OpenAlex author record, as of 2026-10-19. How we rank
Photo: Notkengoldberg, CC BY-SA 4.0, via Wikimedia Commons (cropped)
About
Ken Goldberg's AUTOLAB at UC Berkeley developed Dex-Net, an approach to learning robot grasping from large sets of synthetic examples. He co-founded Ambi Robotics, which builds AI-powered parcel sorting systems.
Representative work
Selected highly cited papers, linked to their publisher or arXiv versions:
- Motion planning with sequential convex optimization and convex collision checking (2014)
- A Survey of Research on Cloud Robotics and Automation (2015)
- Orienting polygonal parts without sensors (1993)
Links
Who is Ken Goldberg?
Ken Goldberg is a UC Berkeley professor who leads the AUTOLAB, known for Dex-Net grasp planning and cloud robotics, and co-founder of Ambi Robotics.