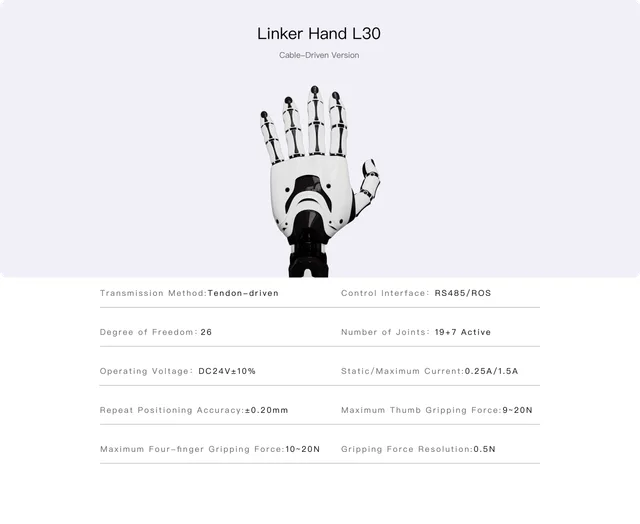
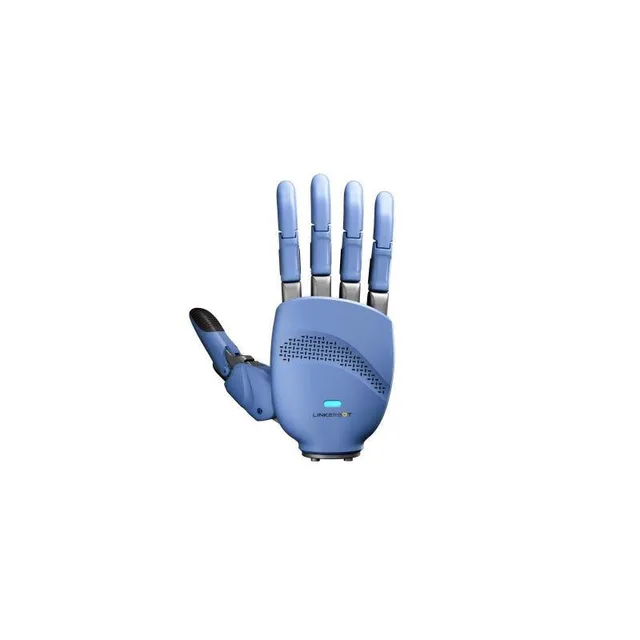
LinkerBot Linker Hand O6 Standard - Left Hand
$2,000.00Backorder
Key Specifications
24-48 V
Operating Voltage
70 N
Max Five Finger Grip Force
0.8 kg
Net weight
6
Degrees Of Freedom
XT30 (2+2): CAN L, CAN H, GND, 24-48 V
Power/Signal Connector
All Specifications
BrandLinkerBot
CategoryRobotic Hand
AvailabilityBackorder
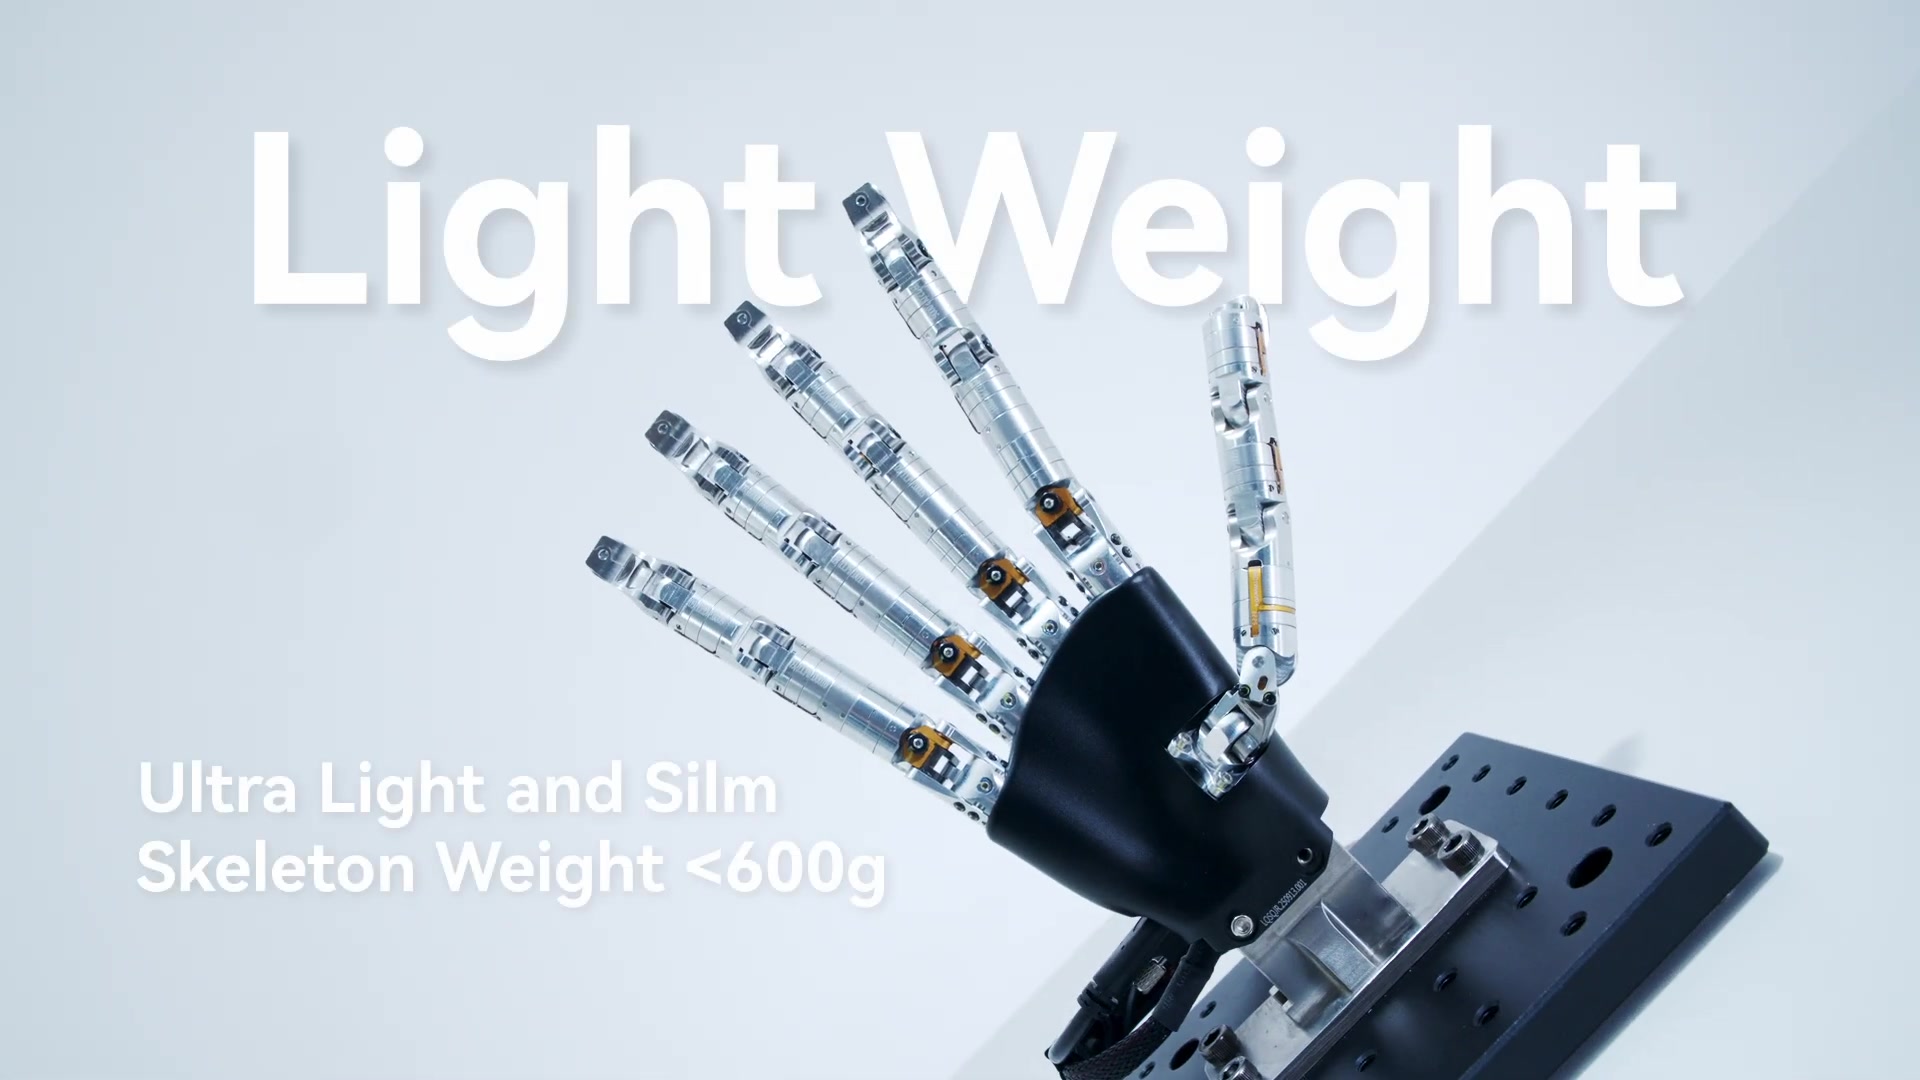
Net weight0.8 kg
ModelLinker Hand O6
Joints11 (6 active + 5 passive)
TransmissionRigid linkage with worm-gear drive
Control InterfaceCAN / RS485
Weight370 g
Maximum Load50 kg
Four Finger Joint Range90° (joint 2), 80° (joint 1)
Thumb Joint Range60° flex (joint 1), 30° flex (joint 2), 80° side swing
Control ModesPosition, speed (force control requires the tactile option)
MountingFlange, M3 screws
SoftwarePython, ROS and ROS 2 SDKs; Windows and Ubuntu host software
FirmwareOnline update via host software
Tactile SensingNone
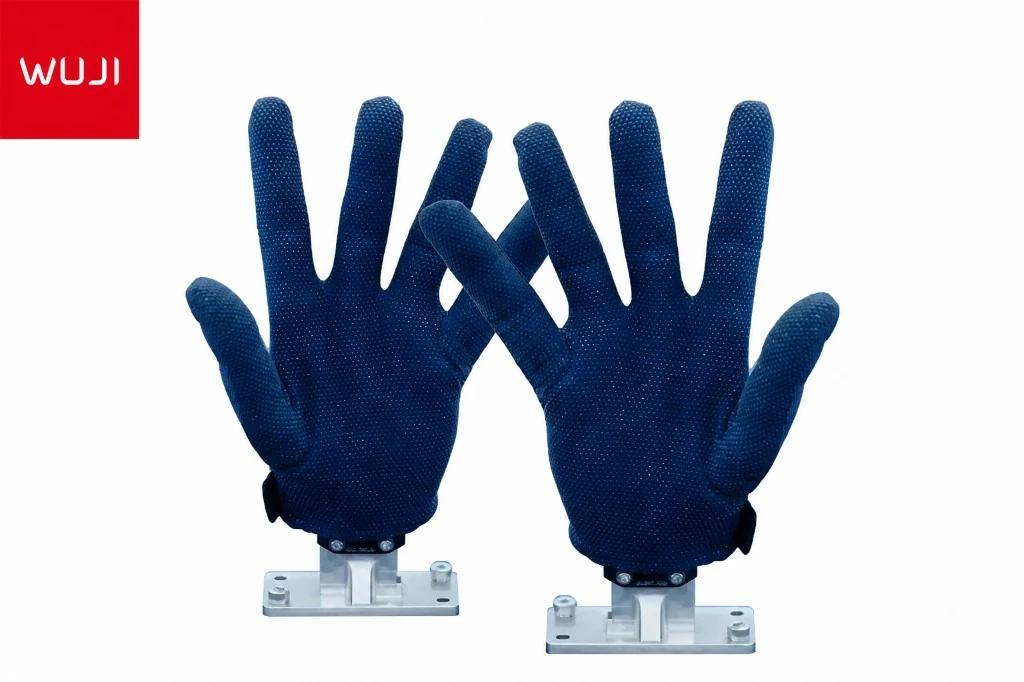
Hand SideLeft or Right; sold per hand or as a pair
IncludedUSB-to-CAN debug cable, XT30 (2+2) cable, power adapter, power cable
Degrees Of Freedom6
Repeatability< ±0.20 mm
Four Finger Bend Speed1.30 rad/s
Thumb Side Swing Speed1.36 rad/s
Thumb Bend Speed0.66 rad/s
Operating Voltage24-48 V
Power/Signal ConnectorXT30 (2+2): CAN L, CAN H, GND, 24-48 V
Max Thumb Fingertip Force20 N
Max Four Finger Fingertip Force25 N
Max Five Finger Grip Force70 N