Wuji Hand vs Shadow Hand vs Allegro Hand: 2026 Dexterous Robot Hand Comparison
How the Wuji Hand, Shadow Dexterous Hand and Allegro Hand compare on joints, sensing, control rate, weight and software, with sourced specs and a guide to which hand fits which kind of lab.
The Wuji Hand, the Shadow Dexterous Hand and the Allegro Hand are three of the dexterous hands research teams most often shortlist. Each was designed with a different kind of work in mind, so the right choice depends on what your lab is building. This page sets out the published specifications side by side, describes what each hand does well, and ends with a short guide to choosing.
Disclosure: Robotics Center sells the Wuji HandFrom $13,000.00 and the Wonik Allegro Hand V5 Sense$13,000.00. We do not sell the Shadow Dexterous Hand; for that hand, contact Shadow Robot directly. Every third-party specification below links to the maker's own documentation.
Specification comparison
The table uses each maker's published figures. "Active DOF" counts independently driven joints.
| Specification | Allegro Hand V5 Sense | Shadow Dexterous Hand | Wuji Hand (1st generation) |
|---|---|---|---|
| Fingers | 3 fingers + thumb1 | 4 fingers + thumb2 | 4 fingers + thumb3 |
| Active DOF | 16 (4 per finger)1 | 20 actuated, plus 4 under-actuated movements (24 joints)2 | 20 (4 per finger)3 |
| Wrist joints | None | 22 | None |
| Drive | Electric | 20 DC motors, tendon-driven2 | Electric, position control3 |
| Built-in sensing | 16 fingertip pressure channels1 | Tactile fingertips (2 standard, up to 5), 40 tendon load sensors, 1 IMU2 | Joint state; tactile sensing via an optional tactile glove for the hand3 |
| Control rate | 333 Hz over CAN1 | 1 kHz through the host over EtherCAT2 | 1000 Hz on each of 20 axes3 |
| Interface | CAN (Ethernet planned)1 | EtherCAT2 | USB 2.0 (USB-C)3 |
| Weight | 1,240 g1 | 4.3 kg2 | 580 ± 10 g without cables3 |
| Software | CAN and UDP protocols, ROS 2 project, simulation support4 | ROS integrated2 | Python (wujihandpy) and C++ (wujihandcpp) packages3 |
| Price | $13,000.00 at Robotics Center | Quote from Shadow Robot2 | From $13,000.00 at Robotics Center |
Wuji also makes the Wuji Hand 2From $14,600.00. Its current documentation describes a 2.2 beta prototype with 20 active DOF, back-drivable direct-drive joints, a 1000 Hz control rate and an Ethernet interface, and notes that those figures are not final.5
Allegro Hand: a long-standing research platform
The Allegro Hand from Wonik Robotics is a four-digit hand with 16 active joints. The V5 Sense version adds 16 pressure-sensing channels in the fingertips and finger adduction and abduction.14 Wonik publishes CAN and UDP protocols, a ROS 2 project and a firmware updater, which makes the hand straightforward to integrate into an existing control stack.4
Its biggest asset for many labs is how widely it is supported in simulation. NVIDIA's Isaac Gym reinforcement-learning examples include an Allegro Hand environment for in-hand cube manipulation, so a team can train in simulation on a model the community already knows well before moving to hardware.6
Suits: reinforcement-learning and sim-to-real research, teams that want a well-documented hand with fingertip pressure sensing, and labs that already run a CAN-based control stack.
Shadow Dexterous Hand: the most human-like range of motion
The Shadow Dexterous Hand from Shadow Robot in London has five digits, a two-joint wrist and 24 joints in total, 20 of them actuated by DC motors through tendons.2 That arrangement, with finger adduction and abduction, gives it the widest range of motion of the three hands here. It is also the most heavily instrumented: tactile fingertips, 40 tendon load sensors and an IMU, with Shadow citing more than 100 sensors running at up to 1 kHz.2
The hand has a long research record. OpenAI's 2018 work on vision-based in-hand object reorientation was carried out on a physical Shadow Dexterous Hand,7 and Isaac Gym's reinforcement-learning examples include a Shadow Hand cube-manipulation environment.6 Shadow sells the hand by quote and offers demos through its sales team.2
Suits: research that needs the full human-like set of joints including the wrist, labs studying contact through dense tendon-force and tactile data, and teams building on prior Shadow Hand work.
Wuji Hand: light, fast, and paired with a data glove
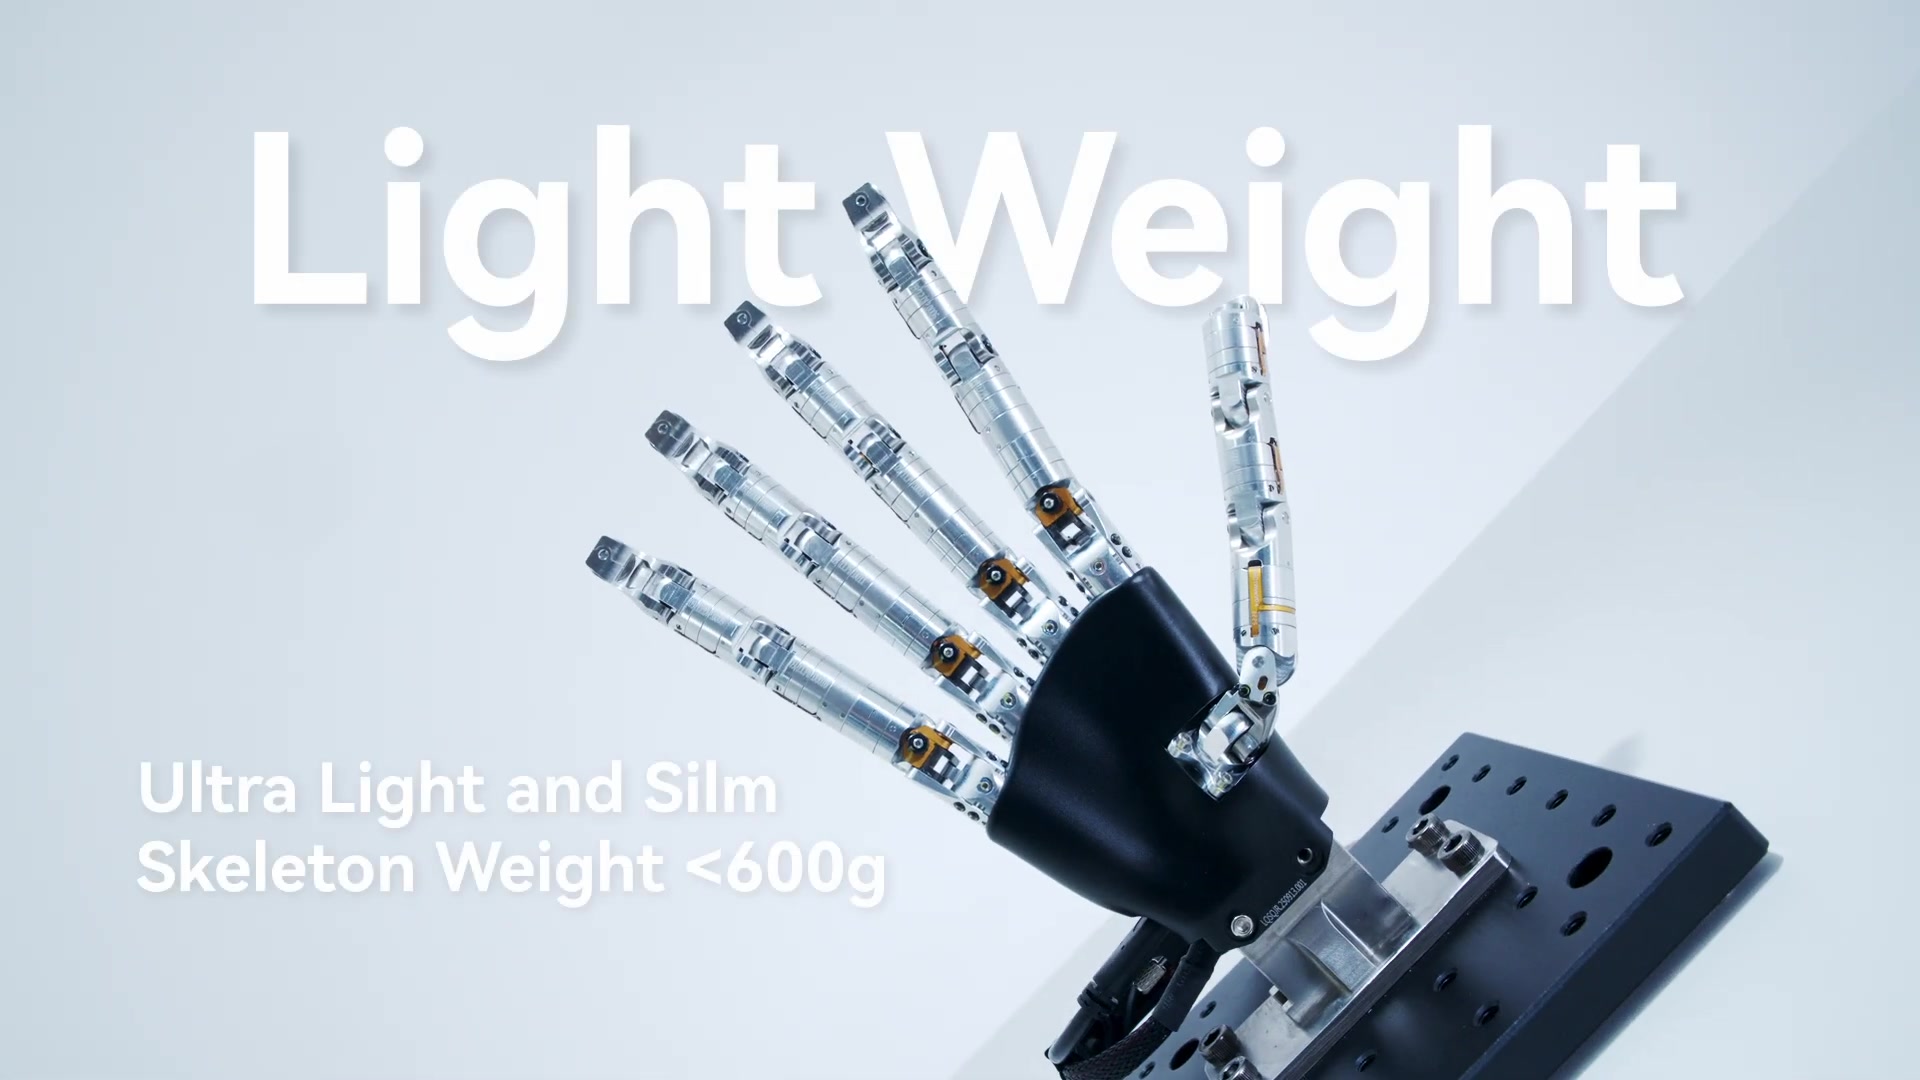
The first-generation Wuji Hand from Wuji Technology has 20 active joints, four per finger, in a 580 g package, and runs position control at 1000 Hz on every axis over a single USB-C connection.3 Its rated fingertip force is 15 N.3 The low weight makes it practical to mount on lighter collaborative arms.
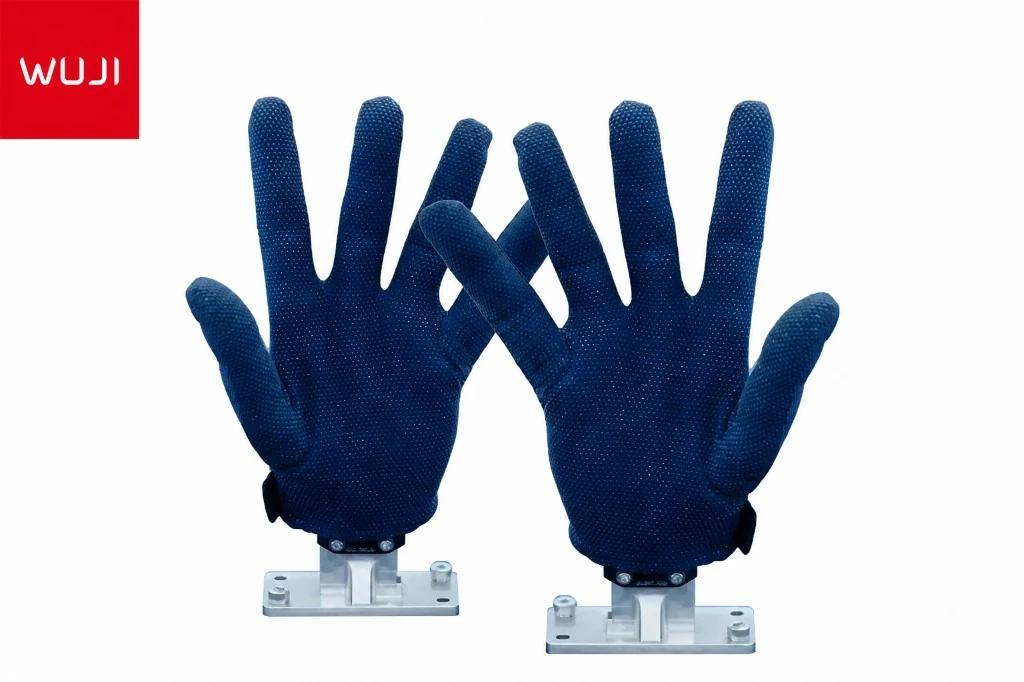
Wuji makes a matching data glove, the Wuji Glove$4,500.00. The glove tracks the hand with five electromagnetic modules of 6 DOF each at 120 Hz, with motion-to-data latency of 10 ms or less, and adds a 24 × 31 pressure matrix with 526 active points at 120 FPS.8 The Wuji SDK supports the Wuji Hand, the Wuji Hand 2 and the Wuji Glove from one Python and C API, and records multi-channel sensor data to MCAP files with episode switching, which suits demonstration collection for imitation learning.9
Suits: teleoperation and imitation-learning projects, teams that want one vendor's SDK across the hand and the glove, and setups where hand weight on the arm matters.
How to choose
- If you need the full human-like joint set, a wrist, and dense tendon-force sensing, choose the Shadow Dexterous Hand.
- If reinforcement learning in simulation is your main workflow, the Allegro Hand is a strong fit thanks to its established simulation environments and published protocols.
- If you are collecting human demonstrations for imitation learning, the Wuji Hand with the Wuji Glove keeps the hand, the glove and the recording tools in one SDK.
- If hand weight on your arm is the limiting factor, compare the published weights above: 580 g for the Wuji Hand,3 1,240 g for the Allegro V5 Sense,1 and 4.3 kg for the Shadow Hand.2
Not sure which fits your task? Talk to an engineer, or ask us about short-term leasing so you can evaluate a hand before buying.
Frequently asked questions
What is the Wuji Hand?
The Wuji Hand is a dexterous robot hand from Wuji Technology with 20 active joints, four per finger. The first generation weighs 580 g and runs at 1000 Hz on each axis.3 Robotics Center sells it in our store.
How does the Wuji Hand compare to the Shadow Hand?
The Shadow Dexterous Hand has 24 joints including a two-joint wrist, 20 of them actuated, and extensive built-in sensing.2 The Wuji Hand has 20 active finger joints without a wrist, weighs much less, and has a matching data glove from the same maker.38 The Shadow Hand fits research that needs the widest range of motion; the Wuji Hand fits lighter teleoperation and data-collection setups.
What is the Allegro Hand?
The Allegro Hand is a 16-DOF research hand from Wonik Robotics. The V5 Sense version Robotics Center sells has 16 fingertip pressure channels and a 333 Hz CAN interface.1 It is well supported in simulation, including an Isaac Gym environment.6
Does Robotics Center sell the Shadow Hand?
No. We sell the Wuji Hand and the Allegro Hand. For the Shadow Dexterous Hand, contact Shadow Robot.
Related comparisons
- Best Dexterous Robot Hands: market survey
- Diffusion Policy Guide: a common policy class for demonstration data
- Wuji Hand Teleoperation Guide: setup and collection walkthrough
- Robot Leasing: evaluate hardware before buying
Sources
- Wonik Robotics, "Allegro Hand V5 Sense" product page, https://www.allegrohand.com/sub/product/p.php?idx=22 (accessed 2026-11). ↩
- Shadow Robot, "Dexterous Hand Series", https://www.shadowrobot.com/dexterous-hand-series/ (accessed 2026-11). ↩
- Wuji Technology, "Wuji Hand: Product Introduction" (first generation), https://docs.wuji.tech/docs/en/wuji-hand/v1/overview (accessed 2026-11). ↩
- Wonik Robotics, "Allegro Hand V5 Sense" technical information, https://www.allegrohand.com/sub/tech/t.php?idx=23 (accessed 2026-11). ↩
- Wuji Technology, "Wuji Hand 2: Overview", https://docs.wuji.tech/docs/en/wuji-hand/latest/overview (accessed 2026-11). ↩
- NVIDIA, "IsaacGymEnvs: Reinforcement Learning Examples" (Shadow Hand and Allegro Hand environments), https://github.com/isaac-sim/IsaacGymEnvs/blob/main/docs/rl_examples.md (accessed 2026-11). ↩
- OpenAI et al., "Learning Dexterous In-Hand Manipulation", arXiv:1808.00177, https://arxiv.org/abs/1808.00177 (accessed 2026-11). ↩
- Wuji Technology, "Wuji Glove: Product Introduction", https://docs.wuji.tech/docs/en/wuji-glove/latest/introduction (accessed 2026-11). ↩
- Wuji Technology, "Wuji SDK: SDK Overview", https://docs.wuji.tech/docs/en/wuji-sdk/latest/introduction (accessed 2026-11). ↩